
Count the number of vision and compute channels per the packing list, not per the cover slogan. The main controller is an Nvidia Jetson AGX Orin 64G, with an additional 1T solid-state drive. Standard vision configuration is D435 ×1, wide-angle camera ×2, voice module ×1. If the cover states 3 depth channels plus 2 wide-angle channels, that conflicts with the packing list; the specification follows the packing list. D435 row: ideal ranging 0.3–3 m; depth ≤1280×720, ≤90 fps; RGB 1920×1080, 30 fps; field of view 69°×42°; rolling shutter. Navigation separately lists depth camera ×1, IMU + encoder ×1, LiDAR ×1, safety edge ×1, ultrasonic ×2. The three terms standard, included, and optional must be retained. If an optional item is not checked, it is not considered already included.
Perception & Compute
Head-mounted E6 and E2 are a separate image stream on the person, not in the sensor list of the wheeled lift dual-arm teleoperation body. The person's first-person view and the body's cameras must be stored in separate files. E2 has no on-board SLAM; pose is reconstructed offline. E6 training reads the raw frame rate, not the preview. These constraints belong to the head-mounted page; here they only prevent being counted into the body's channel count.
The depth, lidar, and ultrasonic used for navigation are not the same set as the head or hand cameras. When writing them into a dataset, use different topic names. Identical names will cause the training script to treat the obstacle-avoidance image as an in-hand image.
The compute platform section only copies rows that exist. Having Orin 64G does not mean having a 1T solid-state drive, and having 1T does not mean every neighboring page has it either. For products that do not list a processor, do not draw a default compute board in the system diagram. See the original page text at /product-body-lift.html.
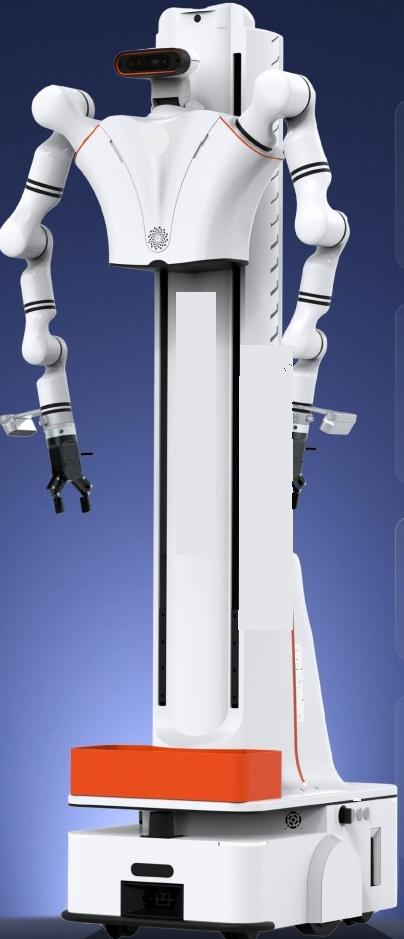
How to Use This Page in This Version
The sensor list is archived under four categories: "standard / standard-equipped / optional / cover." Main controller Nvidia Jetson AGX Orin 64G, plus a 1T solid-state drive. Standard vision: D435 ×1, wide-angle camera ×2, voice module ×1. If the cover states 3 depth channels plus 2 wide-angle channels, which conflicts with the list, the specification follows the list. D435 row: ideal ranging 0.3–3 m; depth ≤1280×720, ≤90 fps; RGB 1920×1080, 30 fps; field of view 69°×42°; rolling shutter. Navigation separately lists depth camera ×1, IMU + encoder ×1, LiDAR ×1, safety edge ×1, ultrasonic ×2. When archiving, move optional and cover items out of the standard category. Where the cover conflicts with the list, cite the list externally while retaining the sentence "the cover states otherwise; not part of delivery." Do not pretend the conflict does not exist, and do not let the cover win.
The computation row is archived separately. If "Orin 64G" is written, one must ask whether there is a solid-state drive capacity. Only if "1T" is written can "1T" be stated. For products where neither row is present, no computation board is drawn in the system block diagram. The processor in the head-mounted unit is not the processor of the embodiment itself.
Camera topic names are decided before acquisition: head, hand, wide-angle, depth, and LiDAR must not share a single name. Navigation depth and hand RGBD are two separate channels even though both are called depth. When the wheeled lift dual-arm teleoperation body page does not provide topic strings, label the topic names as "project-defined, but must match the channel count in the list"; do not change the channel count to a number that is convenient for topic naming.
Head-mounted devices and gloves do not enter this list. They may exist in the same experiment, but the list should say "parallel person-side equipment" to prevent training scripts from treating the person's images as body cameras. Synchronization is not resolved at this level; this level only prevents miscounting channels. Source: /product-body-lift.html.
Line-by-Line Verification
Degrees of freedom. In the robotic-arm parameter table, the model RM75-B-V has 7 degrees of freedom per arm. The product page does not publish the total degrees of freedom for the whole machine; do not fill in 17 or 20. This row only states the number of joints and body parts that have been made public. It does not evaluate intelligence, and it does not automatically include the waist, legs, neck, or a whole-machine total that is not named on the page. When writing the action vector, create channels only for the body parts named in this row; leave unnamed body parts blank. Do not write blanks as 0, because 0 would be treated by the training script as a real angle. Do not append the degrees-of-freedom integer from another device to this row to make up a total. If the master–slave joint order is not given on the page, mark it as pending written configuration confirmation; do not number it yourself. The number of joints is not the number of camera channels. The action vector creates channels only for the body parts named in this row; unnamed body parts are left blank and are not filled with 0.
Payload and mass. Rated payload per arm: 5 kg. The 8 kg in the parameter table is the weight of a single arm. The dual-arm rated payload of 8 kg previously written on the cover conflicts with the parameter table; the parameter table takes precedence. Approximately 80 kg for the whole machine is the total machine mass. The numbers in this row must be read together with their subject: rated, self-weight, total machine mass, envelope, friction, or gripping force. If the subjects differ, they cannot be merged into a single number, nor can any conversion not given on the page be performed. If objects in the field are heavier, this does not allow the specification to be changed retroactively; a larger specification also does not prove that every grasping method reaches that limit. The tool mass is undetermined; do not write the arm's rated payload as the mass of the object that can be grasped. The acceptance table retains the original units. Payload does not determine the vision configuration. During acceptance, read the subject first and then the number; if the subjects differ, split them into two rows.
Dimensions and scale. Model RMC-AIDAL. Stowed dimensions: 640 × 450 × 1780 mm. Chassis: 640 × 450 × 250 mm. This row is an outline or structural scale, used to check doorways, elevators, tabletops, or transport; it is not the operating height, nor is it the arm reach. Do not add it to the vertical range. If a figure shows protrusions, antennas, or a person's standing position that are not in this row, note separately that they are not part of the specification. If weight appears in an adjacent row, do not write it into the dimension sentence. The outline does not include the number of sensor installations. Doorways, elevators, and transport are checked only against the outline; do not treat this row as the operating height.
Operating range. Lifting stroke 900 mm; vertical working range 0–2.4 m (also written as 0–2400 mm in the table). Single-arm reach 633 mm. Overhang beyond the chassis on one side: 790 mm; the original text does not mark a unit at that point, and it appears alongside millimeters in the same sentence, so externally write 790 mm and retain this note. This row describes the range that the hand or the lift can reach; the definition must follow the original sentence: vertical working range, arm reach, motion radius, or stroke. These cannot be added together or renamed. If "excluding end effector" is written, it must remain in the figure caption. When the original text does not mark a unit, retain the note "unit not specified"; do not delete it for the sake of tidiness. Field of view is not robotic arm reach. The figure caption retains the range definitions from the original sentence, as well as the words "excluding end" or "unit not specified".
Motion. Two-wheel differential drive, speed 1.5 m/s, climbing 5°. Positioning accuracy ±10 mm / ±3°. This row describes how the ground platform or the main arm moves. Four-wheel steering, four-wheel drive, differential drive, in-place rotation radius, and rotational speed are terms for different mechanisms and cannot be substituted for one another. The published speed is a capability, not a recommended teaching speed; teaching may be slower, but a slower speed is recorded under experimental conditions and is not written back as a specification. If a page does not state climbing or positioning, do not borrow them from another page. Chassis speed is not the sampling rate. The teaching speed may be lower, but a lower speed is recorded under operating conditions and does not change the published capability in this row.
Power. The battery is lithium iron phosphate, DC 48V 20Ah. This document dated 2026-08-03 does not state runtime in hours. Do not fill in approximately 6 hours, and do not rewrite it as 48V 31Ah or approximately 4 hours. This row retains only the electrical terms that appear on the page: voltage, capacity, runtime, charging, current, or power. If "hours" is not present, state that runtime is not given; do not fill in hour values from adjacent pages. Do not rename charging time as runtime. Rated and maximum values must be listed separately. Preserve "approximately" where it appears. Do not sum the amp-hour values of multiple devices and present the total as the battery of a single device. The computing platform's power consumption does not belong in the battery row unless that row states it. Any hours, charging, or current that do not appear remain as not given; do not copy them in from adjacent pages.
Perception and computing. Main controller: Nvidia Jetson AGX Orin 64G, with an additional 1T solid-state drive. Standard vision configuration: D435 ×1, wide-angle cameras ×2, voice module ×1. If the cover states 3 depth channels plus 2 wide-angle channels, this conflicts with the list; the specification follows the list. D435 row: ideal ranging 0.3–3 m; depth ≤1280×720, ≤90 fps; RGB 1920×1080, 30 fps; field of view 69°×42°; rolling shutter. Navigation lists separately: depth camera ×1, IMU + encoder ×1, LiDAR ×1, safety edge ×1, ultrasonic ×2. This row inventories the items already stated in sensing, computing, or communications, and retains the words standard, included, optional, and configurable. An optional item that is not selected does not count. When the cover and the list conflict, cite the list, while not pretending that the cover statement does not exist. Head-mounted devices and gloves do not enter this row. Processors, drive capacities, or camera channel counts that are not written out must not be drawn into the system diagram. This is the main row for channel counts and computing; standard and optional items must be built as separate topics. Optional sensors that have not been purchased do not enter this data dictionary.
End effector. The recommended configuration lists gripper CTAG2F90-D ×2. The standard configuration quantity table does not include a gripper. RMG22-65 is a separate product page. This row states where contact or gripping takes place. Quick-change, compatible, and recommended are not models already included in the box. The finger-ring fixture on the main arm is not an end-of-arm gripper. Force, stroke, and payload are still retained as-is in their respective rows; they are not merged into a single system metric merely because they are mounted on a particular body. Flange and protocol mappings that are not given are written as pending confirmation, not as plug-and-play. If a hand camera is standard or optional, do not write it as an attribute of the end-effector gripper. "Supports" or "compatible" without a model number cannot be treated as delivered.
Boundaries. The standard configuration lists robotic arms RM65-B-V ×2, while the robotic-arm parameter table lists model RM75-B-V. Both model sets are retained; lock them before placing the order, and do not collapse them into one. This row is a boundary deliberately kept separate on the page: another model, another column, another product page, or an interface that still requires project confirmation after modularization. A boundary is not a defect note; it prevents verbally buying two pages as one. When writing a proposal, copy the boundary into "not included in this scope". If a device that is not included is added later, open a new configuration sheet; do not go back and change the body name in old samples. Extra channel counts from the cover go in the remarks, not into the standard topics. Devices within the boundary must be ordered separately; do not rename old samples to say they already include it.
Configuration column. The recommended configuration is RM75-B-V ×2, two-wheel differential chassis ×1, gripper CTAG2F90-D ×2. Teleoperation options are servo teleoperation, backpack teleoperation, and mobile teleoperation, which are not included in the standard configuration quantity table. This row distinguishes standard, recommended, and optional. Unchecked recommended and optional items will not be delivered. If the standard row conflicts with the parameter table row, keep both rows and use "locked for this order" to specify which one is actually delivered, rather than striking out one row in the order without signing off. Prices and lead times are not written into this row's paraphrase. Optional depth camera versions or microphones will not have topics created if unchecked. Unchecked recommended and optional items must be written as "not delivered" on the order.
Excerptable. The following may be copied into an appendix: RMC-AIDAL; 640×450×1780 mm; approximately 80 kg; lift 900 mm; vertical 0–2.4 m; reach 633 mm; rated 5 kg; self-weight 8 kg; repeatability ±0.05 mm; differential drive 1.5 m/s; climbing 5°; positioning ±10 mm / ±3°; Orin 64G + 1T SSD; lithium iron phosphate DC 48V 20Ah, hours not given. This row is the type that can be pasted into an appendix: it carries a subject, carries units, and can be traced back to the original sentence on the product page. When pasting, retain "approximately", "excluding", "not given", "optional", and "recommended". Do not convert and keep only the result. If the same number has different meanings on two pages, write it as two rows in the appendix. Do not mix test protocols into the specification excerpt. The appendix writes the original sentences from the list, not "several cameras". When pasting into the appendix, paste the words "approximately", "excluding", "optional", and similar terms along with the numbers.
Do not write. Do not write the full machine's 17 degrees of freedom, do not write 650×512×1700 mm, approximately 120 kg, lifting 0.3 m, vertical 0–2.1 m, speed 0.1–1.0 m/s. Do not write 8 kg as rated load. Do not write battery life in hours. This line is a negative statement for review purposes. It does not describe what the equipment can do; it only prevents hours, degrees of freedom, load subjects, or cover slogans from adjacent pages from being written in. If a negative statement is hit, revert to the original sentence on the product page, and do not interpret it as approximately correct. Do not write in external papers' success rates or total hours not publicly disclosed on this site. Do not write 3-channel depth as delivered unless the checklist's original sentence states so. If manuscript retrieval hits a negative statement, revert to the original sentence on the product page.
| Projects | Public-Facing Positioning of This Page |
|---|---|
| Degrees of Freedom | In the robotic arm parameter table, model RM75-B-V has 7 degrees of freedom per arm. The product page does not publish the total degrees of freedom for the whole unit; do not fill in 17 or 20. |
| Load and Mass | Single-arm rated payload 5 kg. The 8 kg in the parameter table is the single-arm self-weight. The cover previously stated a dual-arm rated payload of 8 kg, which conflicted with the parameter table; the parameter table takes precedence. The total unit weight of approximately 80 kg is the overall mass. |
| Form Factor and Scale | Model RMC-AIDAL. Folded dimensions 640 × 450 × 1780 mm. Chassis 640 × 450 × 250 mm. |
| Operating Range | Lifting stroke 900 mm, vertical working range 0–2.4 m (also written as 0–2400 mm in the table). Single-arm reach 633 mm. Single-side overhang beyond the chassis is 790 mm; the original text did not specify a unit at that point, but since it appears alongside millimeters in the same sentence, it is written externally as 790 mm with this note retained. |
| Motion | Two-wheel differential drive, speed 1.5 m/s, climbing slope 5°. Positioning accuracy ±10 mm / ±3°. |
| Power | The battery is lithium iron phosphate DC 48V 20Ah. This document dated 2026-08-03 does not state battery life in hours. Do not add approximately 6 hours, and do not rewrite it as 48V 31Ah or approximately 4 hours. |
| Perception & Compute | Main controller Nvidia Jetson AGX Orin 64G, with an additional 1T solid-state drive. Standard vision configuration is D435 ×1, wide-angle cameras ×2, voice module ×1. If the cover states 3 depth channels plus 2 wide-angle channels, this conflicts with the list; the specifications follow the list. D435 row: ideal ranging 0.3–3 m; depth ≤1280×720, ≤90 fps; RGB 1920×1080, 30 fps; field of view 69°×42°; rolling shutter. Navigation separately lists depth camera ×1, IMU + encoder ×1, LiDAR ×1, safety edge ×1, ultrasonic ×2. |
| End Effector | The recommended configuration lists gripper CTAG2F90-D ×2. The standard configuration quantity table does not include a gripper. RMG22-65 is a separate product page. |
| Boundary | The standard configuration lists the robotic arm as RM65-B-V ×2, while the robotic arm parameter table lists the model as RM75-B-V. Both model numbers are retained; lock one before placing the order — do not collapse them into a single number. |
| Configuration Panel | Recommended configuration is RM75-B-V ×2, two-wheel differential chassis ×1, gripper CTAG2F90-D ×2. Teleoperation options are servo teleoperation, backpack teleoperation, and mobile teleoperation; these are not included in the standard configuration quantity table. |
| Excerptable | Attachment copy: RMC-AIDAL; 640×450×1780 mm; approximately 80 kg; lifting 900 mm; vertical 0–2.4 m; reach 633 mm; rated 5 kg; self-weight 8 kg; repeatability ±0.05 mm; differential drive 1.5 m/s; slope climbing 5°; positioning ±10 mm / ±3°; Orin 64G + 1T SSD; lithium iron phosphate DC 48V 20Ah, hours not specified. |
| Do not write | Do not write 17 degrees of freedom for the whole unit, and do not write 650×512×1700 mm, approximately 120 kg, lifting 0.3 m, vertical 0–2.1 m, speed 0.1–1.0 m/s. Do not write 8 kg as the rated payload. Do not write battery life in hours. |
Relationship to Public Methods and Adjacent Pages
The perception configuration determines what the visuomotor policy can see, and also determines what the article cannot claim. The standard configuration, recommended configuration, and cover schematic are often not the same sentence. The lift model's cover once showed "3 depth + 2 wide-angle," while the standard configuration lists one D435 depth camera and two wide-angle cameras. In case of conflict, the standard configuration list prevails, and the conflict note is retained, to prevent sales from verbally presenting the cover number as delivered.
Chassis navigation sensing is a separate group: depth cameras, inertial measurement with encoders, LiDAR, safety bumpers, ultrasonic. They serve chassis obstacle avoidance and localization, not the in-hand camera at the wrist. If a wrist camera is included in the accessories, it must be listed on a separate line and must not be counted into the standard vision path. The compute platform likewise only lists what appears on the page. The folding model lists the core processor as Nvidia Jetson AGX Orin 64G, with no mention of a 1T solid-state drive. The lift model lists Nvidia Jetson AGX Orin 64G and explicitly states an additional 1T solid-state drive. The spec tables for the wheeled humanoid, kit, and gripper do not have this processor line; you cannot write "Orin across the entire series," nor copy the 1T solid-state drive to the folding model.
Head-mounted E6 and E2 are a separate visual pathway, worn on the human body, and are not part of the rig's standard checklist. The human-eye viewpoint and the rig camera viewpoint must be recorded in separate files. The nominal SLAM accuracy in the E6 spec sheet is not ground truth proven by public samples.
This article only inventories the sensing and compute listed on that product page, and points out which line is standard and which line is only a cover claim.
Before handing off to a colleague
Post the sensor list next to the capture computer. One topic name per channel, with "standard," "included," or "optional" copied next to each topic name. Optional topics that have not arrived should be removed from the capture configuration rather than left as empty topics. The extra channel count on the cover is written on a sticky note titled "not delivered." Next to the compute board, note whether the words "SSD capacity" exist; if not, do not attach a 1T label. If the head-mounted camera is recording at the same time, use a separate list to prevent the operator from inserting human images into the base unit topics. Run a diff between the topic configuration file and the product page list. Extra topics in the configuration file must be deleted or marked as project additions; they cannot remain under the standard list's name. Missing standard topics in the configuration file must either be added back or documented in the data notes as not captured, with the reason. Optional topics may only appear if they are checked off on the packing list. When the compute platform's disk capacity is not written on the page, the configuration file must not contain a capacity field, so it is not mistaken for a specification.
First, perform a gap check between the topic and the checklist.
Second, mark extra topics as additional or delete them.
Third, missing standard topics must be noted as not captured.
Fourth, do not create a topic for an unchecked optional item.
Fifth, do not write unavailable disk capacity into the configuration.
Sixth, use a separate checklist for head-mounted.
Continue Reading
- 01 Task Boundaries
- 02 Specification Standards
- 03 Degrees of Freedom
- 04 Payload & Self-Weight
- 05 Workspace
- 06 Locomotion Method
- 07 Perception and Computing
- 08 Power Specifications
- 09 Data Recording
- 10 Time Alignment
- 11 End-Effector Boundaries
- 12 Site Constraints
- 13 Configuration Sheet
- 14 Three-Way Comparison
- 15 Literature References
- 16 Master-Slave Workstation
- 17 Acceptable Deliverable Statements
- 18 Prohibited Conflations
- 19 On-Site Deployment
- 20 Evaluation Path
Back to Product Center View this product page
This article was written on October 3, 2026, for selection and specification verification purposes. Device parameters are subject to the product page tables and do not constitute a supply commitment. External papers only illustrate how problems are framed in the industry; their success rates and data scales belong to the original authors' experiments and are not TOBI's measured results. Phone: +86 137 5502 0164.