
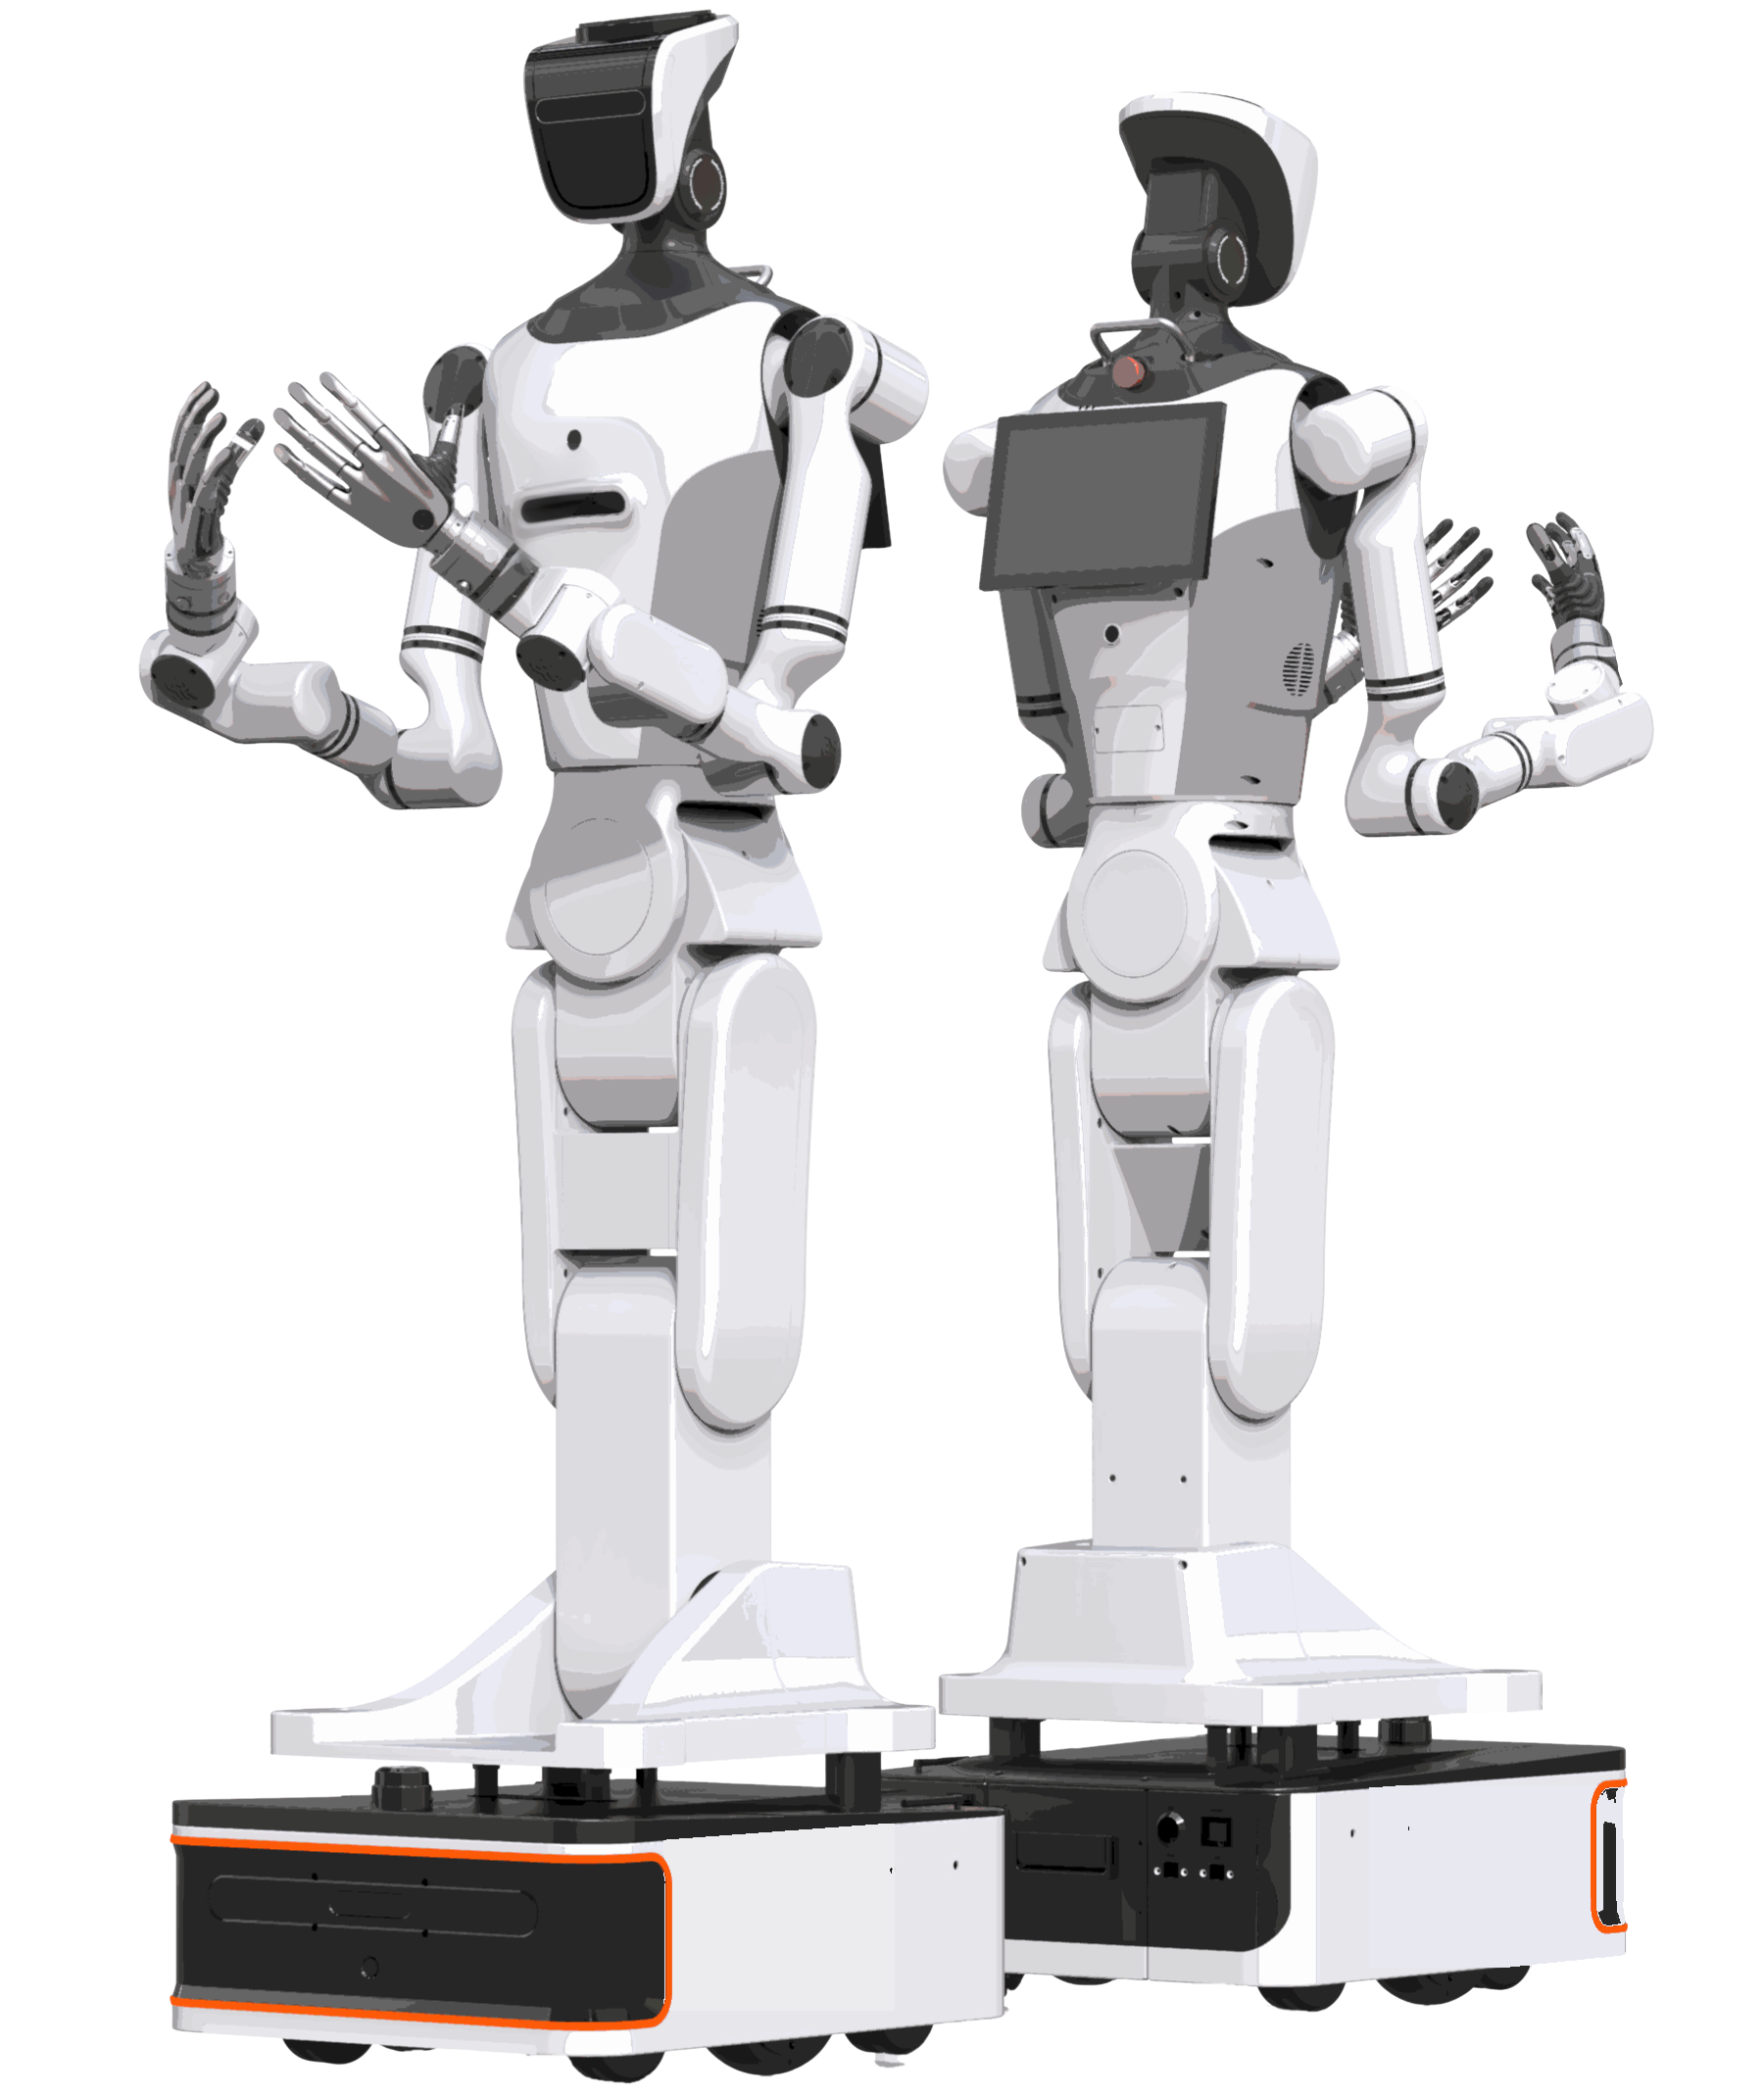
On site, measure the doors, elevator, floor, and slope first, then discuss the model. Whole-machine dimensions: 570 × 465 × 1680 mm. The chassis width and shoulder width are kept within 465 mm. Motion speed: 0.1–1.5 m/s. Turning radius: 690 mm, specified as in-place rotation. Vertical arm reach: 2100 mm. Horizontal arm reach: 1818 mm, excluding the end effector. These three sentences are the site-related language that has been publicly disclosed for the wheeled humanoid teleoperation body. If the load-bearing capacity is not stated, do not invent a floor load rating.
Site Constraints
Speed capability is not the speed allowed on site. The space occupied by people, cables, and the emergency stop is not included in the external dimensions. The desktop occupied by the primary arm workstation is within the motion radius on the kit page, not in the robot's external dimensions.
Positioning accuracy, slope climbing, ultrasonic sensing, and safety edges become checklist items only on pages where they are written. If written, they must go into the checklist; if not written, do not borrow them from adjacent pages. Do not write a charging time of approximately 2 hours as a battery life of 2 hours. Do not write the foldable model's 20 DoF or approximately 6 hours onto this unit. Do not write the lift model's 900 mm as this unit's lift travel. Dimensions and hour counts from adjacent pages likewise cannot be borrowed to fill blanks on this page.
The first on-site visit performs action verification: direction, emergency stop, open/close, chassis forward/backward. Capture proceeds only after verification passes. The verification record is not a training sample.
How to Use This Page in This Version
The site confirmation sheet is filled out before data acquisition, not after. Copy into the dimensions column: whole-machine dimensions 570 × 465 × 1680 mm; chassis width and shoulder width kept within 465 mm. Copy into the height or arm reach column: vertical arm reach 2100 mm; horizontal arm reach 1818 mm, excluding the end effector. Copy into the mobility column: motion speed 0.1–1.5 m/s; turning radius 690 mm, specified as in-place rotation. Copy into the power column: battery 40 Ah (BMS); charging time approximately 2 hours. Approximately 2 hours is charging, not battery life; the page does not state battery life in hours. Leave "measured on site" and "pass/fail" next to each column. If the measured value is stricter than the published value, it can pass; if the measured value does not meet the premise of the published value—for example, the door width is smaller than the external dimensions—it does not pass.
Personnel space is listed separately. The operator, the master-arm desk, cables, and the emergency stop are not included in the external dimensions. The kit's motion radius appears only when the kit is purchased. Drawing the master-arm footprint on the site plan without buying the kit will reserve desk space while the equipment never arrives.
Safety-related rows are copied only if they exist. Slope climbing, positioning, edge detection, ultrasonic, and speed limit: check if present; if absent, write "not given on this page"; do not fill in from another machine. Do not write "charging approximately 2 hours" as "battery life 2 hours." Do not write the folding model's 20 DoF or approximately 6 hours onto this machine. Do not write the lift model's 900 mm as this machine's lift stroke. This negative statement is the anti-mix-up column of the site sheet.
The first pass authorizes only motion verification, not a training set. The verification covers direction, emergency stop, opening/closing, and chassis forward/backward. The file name of the verification record must not be written as "demo" or "episode," so that it is not swept in by the training script. The site sheet source for the wheeled humanoid teleoperation body is /product-body-humanoid.html.
Line-by-Line Verification
Degrees of freedom. Total active degrees of freedom: 21, split as 14 for the two arms, 3 for the waist, 2 for the legs, and 2 for the neck. This row only states the number of joints and body parts that have been publicly disclosed. It does not evaluate intelligence, and it does not automatically include the waist, legs, neck, or whole-machine total that are not named on the page. When writing the action vector, create channels only for the body parts listed in this row; body parts not listed remain blank. Do not write blanks as 0, because 0 would be treated by the training script as a real angle. Do not fill in the degrees-of-freedom integer from another device to make this row add up. If the master–slave joint order is not given on the page, mark it as pending written configuration confirmation; do not number it yourself. The joint count does not determine whether the machine can fit into an elevator. The action vector creates channels only for the body parts named in this row; body parts not named remain blank and are not filled with 0.
Payload and mass. Single-arm payload: 5 kg. Whole-machine weight: approximately 125 kg, which is not the single-arm payload. The numbers in this row must be read with their subject: rated, self-weight, whole-machine mass, envelope, friction, or gripping force. If the subjects differ, they cannot be merged into a single number, nor can any conversion not given on the page be performed. If an object on site is heavier, the specification cannot be changed retroactively; a larger specification also does not prove that every grasping method reaches that limit. The tool mass is undetermined; do not write the arm's rated value as the graspable object mass. The acceptance sheet retains the original units. Only the whole-machine mass is relevant to transport; the rating is not the whole-machine mass. During acceptance, read the subject first and then the number; if the subjects do not match, split them into two rows.
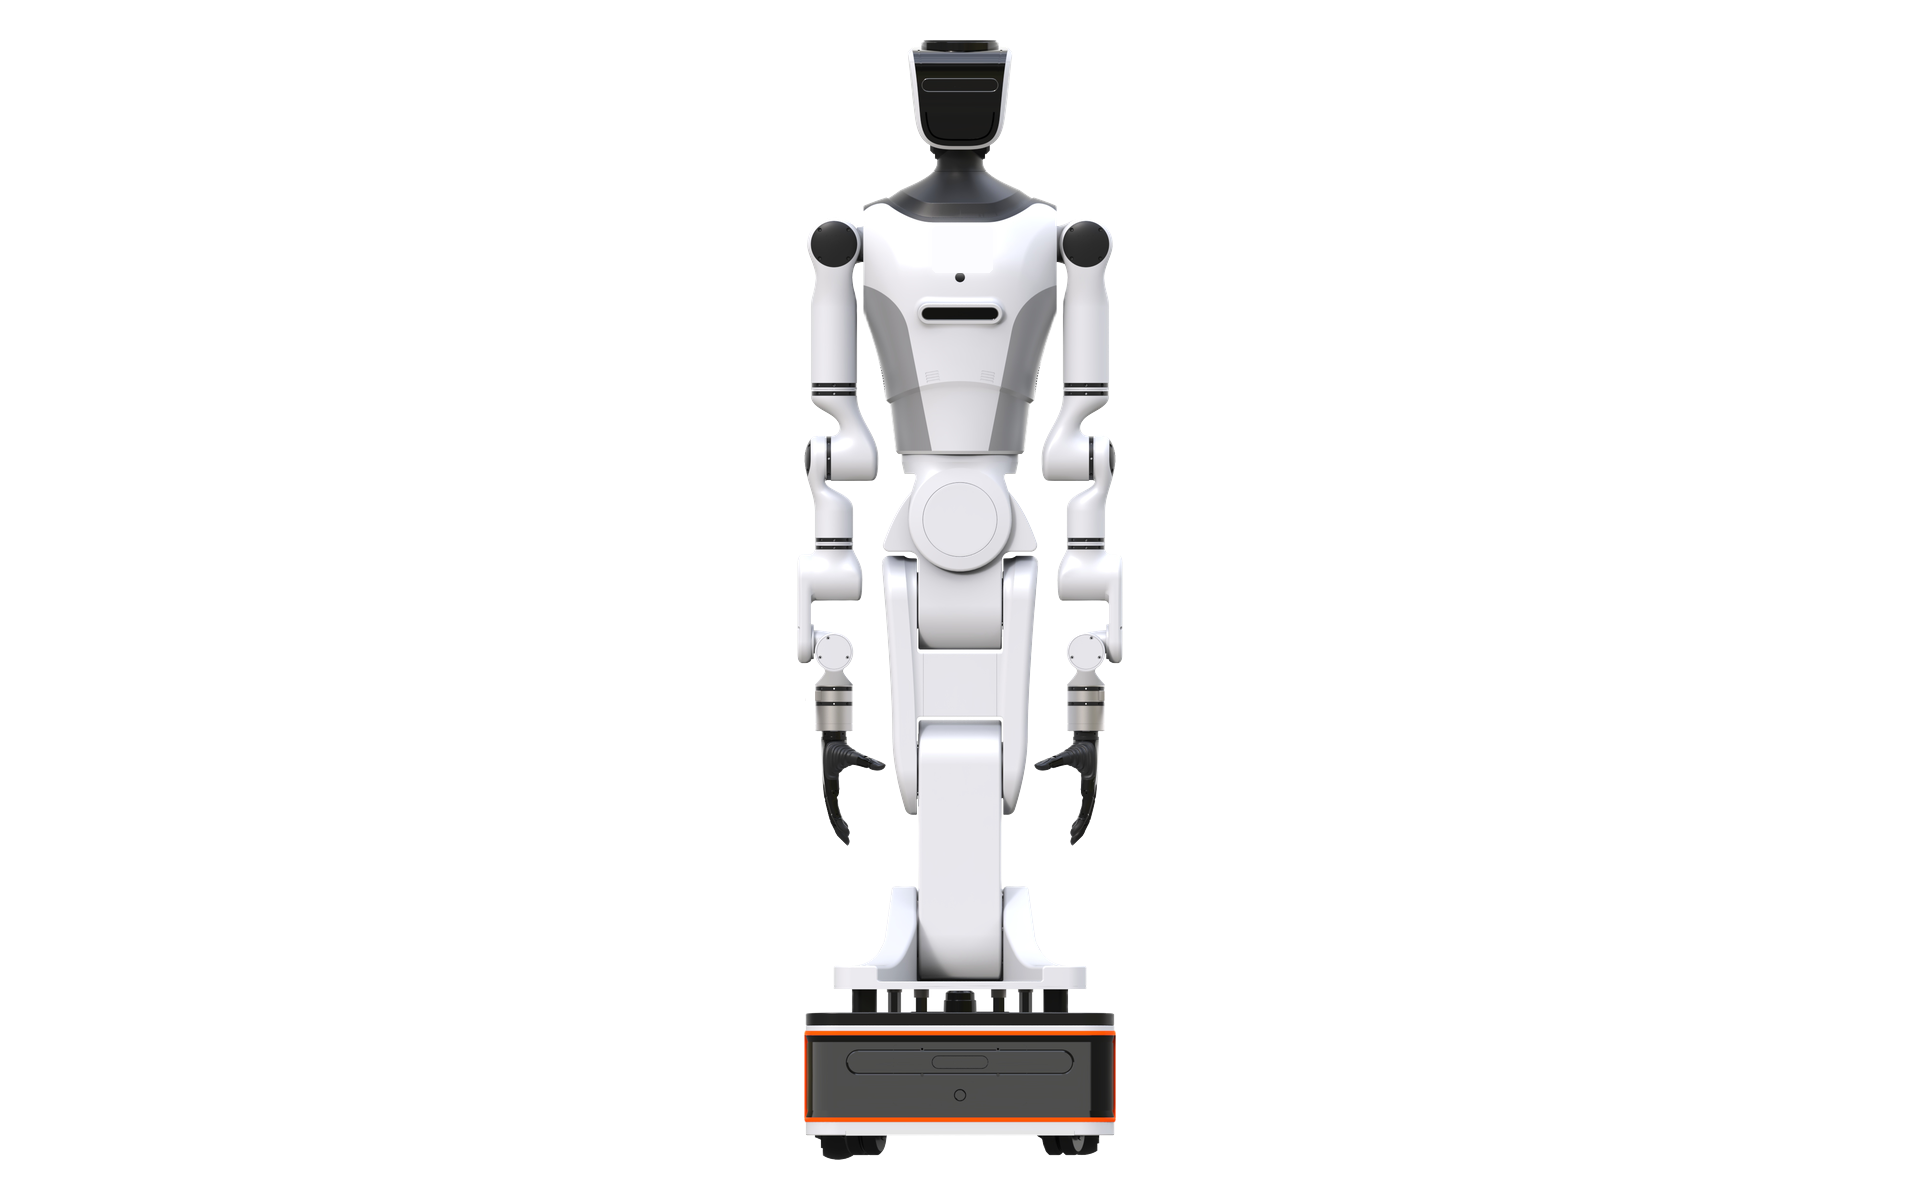
Form and scale. Overall dimensions 570 × 465 × 1680 mm. Chassis width and shoulder width are kept within 465 mm. This row is a form or structural scale, used to check doors, elevators, tabletops, or transport; it is not operating height, nor is it arm reach. Do not add it to the vertical range. If the diagram shows protrusions, antennas, or human standing positions not present in this row, note separately that they are not part of the specification. If weight appears in an adjacent row, do not write it into the dimension sentence. Door entry is based on this row. Doors, elevators, and transport are checked only against form; do not treat this row as operating height.
Operating range. Vertical arm reach: 2100 mm. Horizontal arm reach: 1818 mm, excluding the end effector. This row describes the range that the hand or lift can reach; the definition must follow the original wording: vertical working range, arm reach, motion radius, or stroke. These cannot be added together or renamed. If "excluding the end effector" is written, it must remain in the figure caption. If the original text does not specify units, retain the note "units not specified"; do not delete it for tidiness. Indoor clear height is checked against the operating range, not against the packaging box, unless the box is what is being measured. The figure caption retains the range definition from the original wording, as well as the terms "excluding the end" or "units not specified."
Motion. Motion speed: 0.1–1.5 m/s. Turning radius: 690 mm, specified as in-place rotation. This row describes how the ground platform or main arm moves. Four-wheel steering, four-wheel drive, differential drive, in-place turning radius, and rotational speed are terms for different mechanisms and cannot be substituted for one another. The published speed is a capability, not a recommended teaching speed; teaching can be slower, but a slower speed is recorded under experimental conditions and is not written back into the specification. If the page does not state slope climbing or positioning, do not borrow from another page. Only the values written in this row are used for ground slope and speed limits. The teaching speed can be lower, but a lower speed is recorded under operating conditions and does not change the published capability in this row.
Power. Battery 40 Ah (BMS). Charging time approximately 2 hours. Approximately 2 hours refers to charging, not runtime; no runtime hours are given on the page. This row retains only the electrical terms that appear on the page: voltage, capacity, runtime, charging, current, or power. If there is no "hours" value, state that runtime is not given; do not fill in hours from an adjacent page. Do not rename charging time as runtime. Rated and maximum values must be listed in separate columns. Preserve "approximately" for approximate values. Do not sum the amp-hour figures across multiple devices and present the total as the battery of a single unit. On-site outlet or DC power must match this row; if it cannot be matched, do not power on for data capture. Hours, charging, or current values that do not appear must remain as not given and must not be copied in from an adjacent page.
Perception and computing. The vision system is written as binocular depth / RGB optional. Wide-angle cameras: 130° FOV × 3, located on the chest / back / chassis. LiDAR: single-line laser, detection range greater than 40 m (reflectivity 90%). Voice interaction module: ring of 6 microphones, optional. Depth camera versions: data acquisition version Orbbec 335LG; standard version Intel RealSense D405; optional Intel RealSense D435. This row inventories the items explicitly stated in sensing, computing, or communication, and retains the terms standard, included as standard, optional, and optional configuration. Optional items that are not checked do not count. If the cover conflicts with the list, cite the list while not pretending the cover sentence does not exist. Headsets and gloves do not enter this row. Processors, hard drive capacity, or camera channel counts that are not stated are not drawn into the system diagram. Sensor mounts do not change the door width requirement. Optional sensors that were not purchased do not enter this data dictionary.
End effector. A multi-degree-of-freedom dexterous hand or gripper can be added to the end according to the task. The page states compatibility with grippers and dexterous hands from Aorui, Qiangnao, Zhixing, and others, as well as the RX75, RM75, and RM65 robotic arm platforms. Compatibility is not a standard configuration list. This row states where contact or gripping takes place. Quick-change, compatible, and recommended are not models already in the box. The finger-ring fixture on the main arm is not an end-effector gripper. Force, stroke, and payload are each retained as written in their own rows; they are not merged into a single system metric because they are mounted on a particular body. Flange and protocol mappings that are not given are written as pending confirmation, not as plug-and-play. If the end effector has not arrived, a no-load check can be performed, but the site sheet must note this. "Supports" or "compatible" without a model number cannot be treated as delivered.
Boundary. The upper body and wheeled chassis have a modular structure. How to connect to other chassis after separation is confirmed per project interface, and is not written in the public table as already connected. This line is a deliberately separated boundary on the page: another model, another column, another product page, or an interface that still requires project confirmation after modularization. The boundary is not a defect statement; it is to prevent verbally buying two pages as one. When writing a proposal, copy the boundary into "Not included in this order." If equipment not included is later added, open a new configuration sheet; do not go back and change the body name in the old sample. The main-arm desktop only occupies the site after the kit is purchased. Equipment within the boundary must be ordered separately; do not rename the old sample to say it already includes it.
Configuration column. The voice module and depth camera version both have optional rows. Optional items are not included in the delivery if unchecked. The end-effector brand must be named in the configuration sheet; do not write "compatible, therefore included." This row distinguishes standard, recommended, and optional. Recommended and optional items are not delivered unless checked. If a standard row conflicts with a parameter table row, keep both rows and use "locked for this order" to indicate which one is actually delivered, rather than striking out one row in the order without sign-off. Price and lead time are not written into the paraphrase of this row. Unselected 5G is not a prerequisite for the on-site network. Unchecked recommended and optional items are written as not delivered on the order.
Excerptable. Values that may be copied into the appendix: 21 (14+3+2+2); 570×465×1680 mm; approximately 125 kg; 465 mm width limit; vertical reach 2100 mm; horizontal reach 1818 mm (excluding end effector); in-place rotation radius 690 mm; 0.1–1.5 m/s; single-arm payload 5 kg; 40 Ah; charging approximately 2 hours. This is the type of row that can be pasted into the appendix: it has a subject, has units, and can be traced back to the original sentence on the product page. When pasting, preserve "approximately," "excluding," "not specified," "optional," and "recommended." Do not convert and keep only the result. If the same number has different meanings on two pages, write it as two rows in the appendix. Do not mix test protocols into specification excerpts. Every limit on the site sheet can be traced back to the product page. When pasting into the appendix, paste the words "approximately," "excluding," and "optional" along with the values.
Do not write. Do not describe a charging time of approximately 2 hours as a battery life of 2 hours. Do not attribute the 20 DoF or approximately 6 hours of the folding model to this unit. Do not write the 900 mm of the lifting model as the lifting stroke of this unit. This line is a negative statement for review purposes. It does not describe what the device can do; it only prevents hours, degrees of freedom, load subjects, or cover slogans from neighboring pages from being written in. If a negative statement is matched, revert to the original sentence from the product page; do not interpret it as "approximately." Do not write in success rates from external papers or total hours not published on this site. Do not write the appearance or climbing ability of another unit into this entry. If manuscript retrieval matches a negative statement, revert to the original sentence from the product page.
| Projects | Public-Facing Positioning of This Page |
|---|---|
| Degrees of Freedom | Total active degrees of freedom: 21, broken down as dual arms 14, waist 3, legs 2, neck 2. |
| Load and Mass | Single-arm payload 5 kg. Total unit weight is approximately 125 kg, which is not the single-arm payload. |
| Form Factor and Scale | Overall dimensions 570 × 465 × 1680 mm. The chassis width and shoulder width are kept within 465 mm. |
| Operating Range | Vertical reach 2100 mm. Horizontal reach 1818 mm, excluding the end effector. |
| Motion | Motion speed 0.1–1.5 m/s. Turning radius 690 mm; the specification refers to in-place rotation. |
| Power | Battery 40 Ah (BMS). Charging time approximately 2 hours. The approximately 2 hours refers to charging, not runtime; the page does not state runtime in hours. |
| Perception & Compute | The vision system is listed as binocular depth / RGB optional. Wide-angle camera 130° FOV ×3, located on the chest / back / chassis. The LiDAR is a single-line laser with detection range greater than 40 m (90% reflectivity). The voice interaction module is a ring-shaped 6-microphone array, optional. Depth camera versions: data collection version Orbbec 335LG; standard version Intel RealSense D405; optional Intel RealSense D435. |
| End Effector | A multi-degree-of-freedom dexterous hand or gripper can be added to the end effector depending on the task. The page explicitly states compatibility with grippers and dexterous hands from Aoyi, Qiangnao, Zhixing, and others, as well as the RX75, RM75, and RM65 robotic arm platforms. Compatibility is not a standard configuration list. |
| Boundary | The upper body and wheeled chassis are modular. How to connect to other chassis after separation must be confirmed per the project interface; do not state in the public table that it is already connected. |
| Configuration Panel | Both the voice module and depth camera versions have optional rows. Optional items are not included in unchecked deliveries. The end-effector brand must be specified by name in the configuration sheet; do not write "compatible means already included." |
| Excerptable | Attachment copy: 21 (14+3+2+2); 570×465×1680 mm; approximately 125 kg; 465 mm maximum width; vertical reach 2100 mm; horizontal reach 1818 mm (excluding end-effector); in-place rotation radius 690 mm; 0.1–1.5 m/s; single arm 5 kg; 40 Ah; approximately 2 hours of charging. |
| Do not write | Do not write "approximately 2 hours of charging" as "2 hours of battery life." Do not attribute the folding model's 20 DoF or approximately 6 hours of battery life to this unit. Do not write the lifting model's 900 mm as this unit's lifting stroke. |
Relationship to Public Methods and Adjacent Pages
Site constraints come before algorithms. Door widths, elevators, floor slopes, aisles, and personnel safety distances determine whether this unit can enter the site; the model architecture does not. Speed is a safety parameter, not a "faster is better" marketing claim. Gradeability, positioning error, ultrasonic sensors, and bump strips are the conditions for whether the chassis can operate on that floor.
The lift model's publicly disclosed differential-drive speed is 1.5 m/s, slope climbing is 5°, positioning accuracy is ±10 mm / ±3°, and it lists one safety edge-sensor channel and two ultrasonic channels. The left and right single-side overhang beyond the chassis is written as 790 in the source material; the sentence is in a millimeter context but the original does not state the unit. Externally, write it as 790 mm and retain this note. The folding model's overall width is approximately 552 mm; the wheeled humanoid's shoulder and chassis are within 465 mm, with a turning radius of 690 mm. Using the wrong width to measure a door will only reveal the problem on installation day when the device cannot fit through.
The demonstration site must also leave room for people. The primary arm workstation, operator, cables, and emergency stop are not included in the robot's external dimensions. The primary arm's self-weight and length on the kit page determine the desktop, not whether the slave end can pass through a door.
This article turns the product's publicly disclosed ground clearance and dimensional constraints into site-entry checklist items. Safety ratings and protection ratings that are not disclosed are not supplemented.
Before handing off to a colleague
The site form is filled out before the equipment enters the door, not after. The measurement column and the specification column are placed side by side. If the measurement does not meet the door width or power supply requirements, unboxing for capture does not proceed. Personnel positions are marked on the floor with tape; the tape dimensions are not written into the specifications.
The title of the first release form is "Action Verification"; the file name does not use "episode". Items that fail verification are marked as "failed", not as "to be handled later in the data". The product page path is written in the header of the site form for easy comparison with the day's table. Pre-entry measurements are taken with a tape measure and a voltmeter, not by eye. Visual estimates of "close enough" are not entered in the measurement column. If the measurement column is left blank, unboxing is not permitted. If an end-effector is found to be missing after unboxing, the action verification may continue, but the release form is changed to "No End-Effector Verification", and this title is printed in the header of every record for that day. Records without the header are not archived into the formal experiment.
First, use a tape measure and a voltmeter before entering the site.
Second, visual estimates are not written in as measured values.
Third, test empty without unboxing.
Fourth, when the end effector is missing, write "no end effector" in the header.
Fifth, personnel tape is not written into the spec.
Sixth, records missing a header do not enter formal experiments.
Continue Reading
- 01 Task Boundaries
- 02 Specification Standards
- 03 Degrees of Freedom
- 04 Payload & Self-Weight
- 05 Workspace
- 06 Locomotion Method
- 07 Perception and Computing
- 08 Power Specifications
- 09 Data Recording
- 10 Time Alignment
- 11 End-Effector Boundaries
- 12 Site Constraints
- 13 Configuration Sheet
- 14 Three-Way Comparison
- 15 Literature References
- 16 Master-Slave Workstation
- 17 Acceptable Deliverable Statements
- 18 Prohibited Conflations
- 19 On-Site Deployment
- 20 Evaluation Path
Back to Product Center View this product page
This article was written on October 3, 2026, for selection and specification verification purposes. Device parameters are subject to the product page tables and do not constitute a supply commitment. External papers only illustrate how problems are framed in the industry; their success rates and data scales belong to the original authors' experiments and are not TOBI's measured results. Phone: +86 137 5502 0164.