
Literature is used to enumerate questions, not to borrow success rates. Questions related to the isomorphic teleoperation kit are: does the action space equal the publicly stated degrees of freedom of the slave or master side, does the observation equal the cameras on the list, does the chassis move, is the end-effector opening/closing included in the vector, and is the timestamp agreed separately.
Document Location
ALOHA discusses dual-arm master-slave control and action chunking, Mobile ALOHA discusses mobile dual-arm, Diffusion Policy discusses imitation-learned visuomotor policies, UMI discusses a handheld gripper rather than a full platform, and Open X-Embodiment discusses pooling across robots, where the embodiment must be labeled. These sentences can be written into the "source of questions" section of a proposal. Do not copy the authors' success rates, sample counts, or costs.
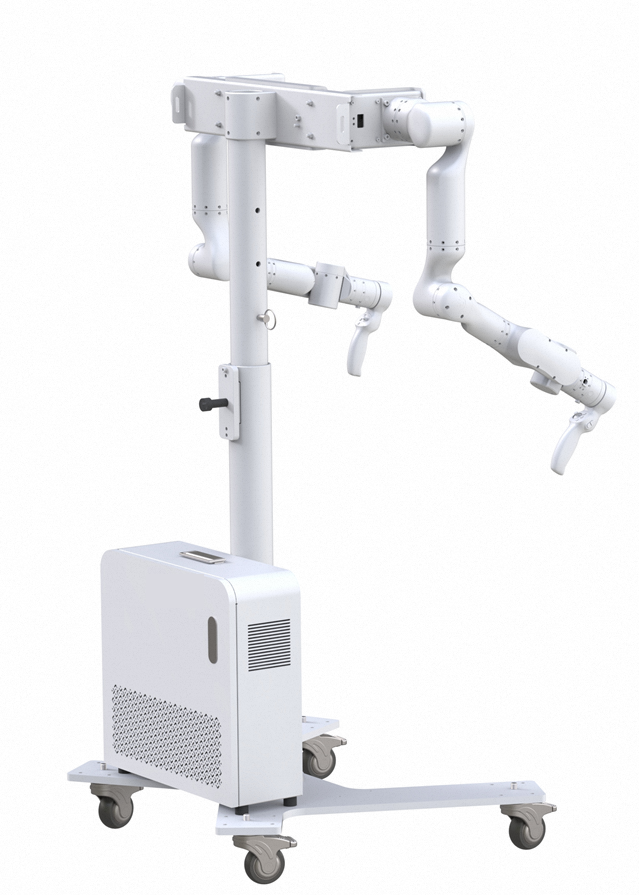
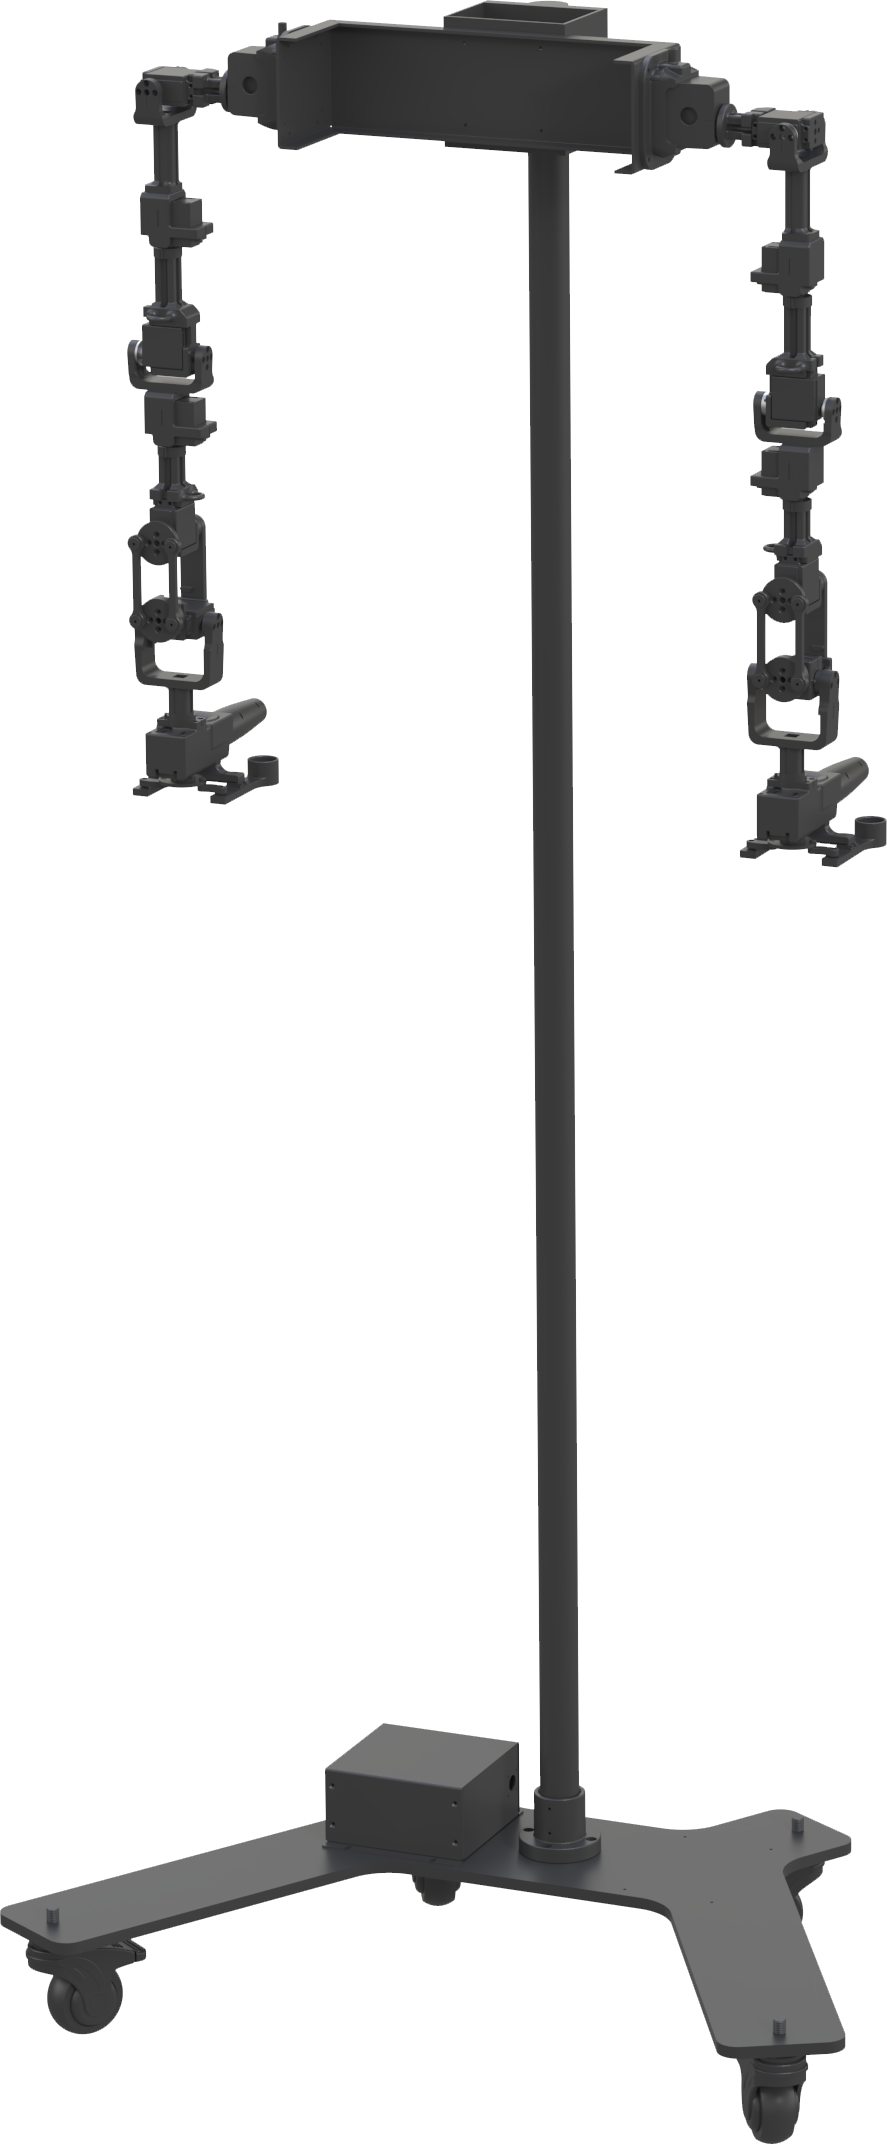
The isomorphic teleoperation kit can only answer the parts already written on the product page: all three columns have 7 degrees of freedom, which cannot be merged into a single unit. The column names are GLN-RX75, GLN-RX71, and local isomorphic kit. Angular resolution: the first two columns are ±0.003°, the local column is 0.088°. Motor: the first two columns are integrated joints, the local column is a bus servo. Communication: the first two columns are RJ45, the local column is RJ45 / 10-core aviation connector. The fixture in the local column is a rail-type ring fixture used to grip the main arm; it is not the RMG22-65 at the slave end. The slave-end gripper is ordered separately. All other questions remain unanswered until the written configuration is provided.
Do not write "using the system from the above paper." TOBI does not have the equipment list for these experiments, and the isomorphic teleoperation kit is not the robot in those papers.
How to Use This Page in This Version
The literature section of the proposal uses a question checklist, not a scorecard. The checklist has five questions: Is the action space equal to the degrees of freedom or master-slave columns published by the isomorphic teleoperation kit? Is the observation equal to the cameras in the checklist? Is the chassis included in the action? Is the end-effector opening/closing listed separately? Is the timestamp handled separately? For any of the five questions that can be answered from the product page, the answer must be the original sentence. All three columns have 7 degrees of freedom, but they cannot be merged into a single unit on that basis. The column names are GLN-RX75, GLN-RX71, and local isomorphic kit. Angular resolution: the first two columns are ±0.003°, the local column is 0.088°. Motors: the first two columns use integrated joints, the local column uses bus servos. Communication: the first two columns use RJ45, the local column uses RJ45 / 10-pin aviation connector. The fixture on the local column is a rail-type ring fixture used to grip the master arm, not the slave-side RMG22-65. The slave-side gripper is ordered separately. Maximum operating speed: the first two columns are 30 RPM, the local column is 110 RPM. All three columns list zero-force drag. Zero-force drag is not force feedback.
For anything that cannot be answered, write "not published." Do not fill in the blanks with the experimental setups of ALOHA, Mobile ALOHA, Diffusion Policy, UMI, or Open X-Embodiment. Those works use their own robots and their own definitions of success. TOBI is not the author of those experiments, and the isomorphic teleoperation kit is not the platform in those papers.
The only connections that can be written are methodological: leader-follower teleoperation requires the leader and follower to share the same action space; mobile manipulation requires recording the chassis; the handheld gripper route is deliberately not a whole-machine; cross-robot aggregation requires annotating embodiment differences. These are research questions derived from reading the literature, not performance guarantees.
The final sentence of the literature section is fixed as: success rate, data duration, and cost are subject to the original paper and are not transcribed into this product. Then send the reader back to /product-teleop-kit.html, rather than to an external PDF treated as a specification sheet.
Line-by-Line Verification
Degrees of freedom. All three columns show 7 degrees of freedom, but this does not mean they can be merged into a single unit. The column names are GLN-RX75, GLN-RX71, and local isomorphic kit. This row only states the number of joints and body parts that have been publicly disclosed. It does not evaluate intelligence, and it does not automatically include waist, legs, neck, or whole-machine totals not named on the page. When writing action vectors, only build channels for body parts present in this row; body parts not present remain blank. Do not write blanks as 0, because 0 would be treated by training scripts as a real angle. Do not fill in degrees-of-freedom integers from another device to complete this row. If the master-slave joint order is not given on the page, mark it as pending written configuration confirmation rather than numbering it yourself. For the action space in literature questions, answer using this row, not using the joint counts of paper robots. Action vectors only build channels for body parts named in this row; unnamed body parts remain blank, not filled with 0.
Load and mass. Main arm self-weight: GLN-RX75 is 7.8 kg, GLN-RX71 is 3.8 kg, local isomorphic kit is approximately 1.5 kg (including fixture). Self-weight is not the rated load of the slave end. The numbers in this row must be read with their subject: rated, self-weight, whole-machine mass, envelope, friction, or gripping force. If the subjects differ, they cannot be merged into a single number, nor can conversions not given on the page be performed. If objects in the field are heavier, this does not retroactively change the specification; a larger specification does not prove that every grasping method reaches that limit. If the tool mass is undetermined, do not write the arm's rated value as the graspable object mass. The acceptance table retains the original units. Object weights from papers cannot be written as already verified in this row. During acceptance, read the subject first and then the number; if the subjects do not match, split into two rows.
Outline and dimensions. Motion radius: 709 mm, 474 mm, 599 mm. This is the scale of the main arm, not the outline of the slave body. This row is an outline or structural dimension, used to check doors, elevators, tabletops, or transport; it is not operating height, nor is it arm span. Do not add it to the vertical range. If the figure shows protrusions, antennas, or a person's standing position not present in this row, note separately that these are not part of the specification. If weight appears in an adjacent row, do not write it into the dimension sentence. Dimensions of paper platforms cannot replace this row. Doors, elevators, and transport are checked only against the outline; do not treat this row as operating height.
Operating range. Configuration: the first two columns are humanoid configurations, and the local column is a dual-arm setup. Gripping: the first two columns are handles, and the local column is a rail-type ring gripper. This row describes the range that the hand or lift can reach; the definition must follow the original sentence: vertical working range, reach, motion radius, or stroke — these cannot be added together or renamed. If "excluding end effector" is written, it must remain in the caption. When the original does not specify units, retain the "units not specified" note and do not delete it for the sake of tidiness. The workspace definition in the paper cannot replace the definition in this row. The caption retains the range definition from the original sentence, as well as the phrases "excluding end effector" or "units not specified."
Motion. Maximum operating speed: the first two columns are 30 RPM, the local column is 110 RPM. All three columns list zero-force dragging for drag force. Zero-force dragging is not force feedback. This row describes how the ground or main arm moves. Four-wheel steering, differential drive, in-place rotation radius, and rotational speed are terms for different mechanisms and cannot substitute for one another. Published speed is a capability, not a recommended teaching speed; teaching can be slower, but slower speeds are recorded in experimental conditions and are not written back as specifications. Do not borrow slope-climbing or positioning data from other pages for pages that do not mention them. Whether mobile operation is viable is determined first by whether this row includes ground motion, not by whether the paper used a mobile base. Teaching speed can be lower, but lower speeds are recorded in the conditions and do not change the published capability in this row.
Power. Operating voltage: the first two columns are DC24V, the local column is DC12V. Power: ≤200 W, ≤100 W, rated 84 W. The specification table has no battery row, so do not write endurance. This row retains only the electrical terms that appear on the page: voltage, capacity, endurance, charging, current, or power. If there are no "hours," write that endurance is not given; do not fill in the blank with hours from an adjacent page. Do not rename charging time as endurance. Rated and maximum values must be in separate columns. Retain "approximately" for approximate values. Do not sum the ampere-hours of multiple devices and claim them as the battery of a single device. Papers do not provide endurance for this row. Hours, charging, or current that do not appear remain as not given and are not copied in from adjacent pages.
Perception and computing. Angular resolution: ±0.003° for the first two columns, 0.088° for the local column. Motors: integrated joints for the first two columns, bus servos for the local column. Communication: RJ45 for the first two columns, RJ45 / 10-pin aviation connector for the local column. This row inventories items already specified under perception, computing, or communication, and preserves the terms standard, included by default, optional, and optional add-on. Unchecked optional items do not count. When the cover conflicts with the checklist, cite the checklist while not pretending the cover statement does not exist. Headsets and gloves do not belong in this row. Do not draw processors, hard-drive capacity, or camera channel counts into the system diagram if they are not written. The number of cameras in a paper is not the channel count for this row. Optional sensors that have not been purchased do not enter this data dictionary.
End effector. The fixture in the local column is a rail-type finger-ring fixture, used to grip the main arm; it is not the RMG22-65 of the remote end. The remote-end gripper is ordered separately. This row states at which end contact or gripping occurs. Quick-change, compatible, and recommended are not models already included in the box. The finger-ring fixture on the main arm is not the remote-end gripper. Force, stroke, and payload remain as-is in their respective rows and are not merged into a single system metric because they are mounted on one body. Flange and protocol mappings that are not provided are marked as pending confirmation, not plug-and-play. The paper's gripper is not the end effector already delivered in this row. "Support" or "compatible" without a model number cannot be treated as delivered.
Boundary. Force feedback is written as supported only for GLN-RX75 and GLN-RX71. The local homogeneous kit is written as not supported. The master arm models are RX75, RX71, and YDS-DAP-75/65/RX75S respectively. This row is a boundary deliberately separated on the page: another model, another column, another product page, or an interface that still requires project confirmation after modularization. The boundary is not a defect statement; it prevents verbally merging two pages into one purchase. When writing a proposal, copy the boundary into "Not included in this order." If an excluded device is added later, open a new configuration sheet; do not go back and change the body name in the old sample. Embodiment differences are exactly the boundary to preserve; do not delete them for the sake of "uniformity." Devices within the boundary must be ordered separately; do not rename an old sample to imply it already includes them.
Configuration column. The contract must state the column name. Purchasing the body does not include the kit by default. For remote operation, refer to the first two columns; for local data acquisition, refer to the third column; in either case, order by cell. This row distinguishes standard, recommended, and optional. Unchecked recommended and optional items will not be delivered. When a standard row conflicts with a parameter-table row, keep both rows and use "Locked for this order" to indicate which one is actually delivered, rather than striking out one row in the order without signing off. Prices and lead times are not written into this row's paraphrase. An unchecked configuration cannot be described as "the same system as in the paper." Unchecked recommended and optional items must be written as "not delivered" on the order.
Excerptable. Copy the attachment column by column; do not merge. Example: GLN-RX75, force feedback supported, 709 mm, 7.8 kg, handle, ±0.003°, 30 RPM, integrated joint, RJ45, DC24V, ≤200 W. This row is the type that can be pasted into an attachment: it has a subject, has units, and can be traced back to the original sentence on the product page. When pasting, preserve "approximately," "not included," "not specified," "optional add-on," and "recommended." Do not convert and keep only the result. If the same number has different meanings on two pages, write it as two rows in the attachment. Do not mix test protocols into specification excerpts. A proposal may state the source of a question, but must not state a paper's success rate. When pasting into an attachment, paste the words "approximately," "not included," and "optional add-on" along with the sentence.
Do not write. Do not write "one teleoperation kit, approximately 5 kg, with force feedback." Do not merge 30 RPM and 110 RPM into a single speed, and do not merge DC24V and DC12V into a single voltage. This row is a negative statement for review purposes. It does not describe what the equipment can do; it only prevents hours, degrees of freedom, load subjects, or cover slogans from the adjacent page from being written in. If a negative statement is hit, revert to the original sentence on the product page; do not interpret it as "close enough." External papers' success rates and total hours not published on this site must likewise not be written in. The sentence "adopting the system from that paper" is prohibited. If manuscript retrieval hits a negative statement, revert to the original sentence on the product page.
| Projects | Public-Facing Positioning of This Page |
|---|---|
| Degrees of Freedom | All three columns have 7 degrees of freedom, but this does not mean they can be merged into a single unit. The column names are GLN-RX75, GLN-RX71, and local isomorphic kit. |
| Load and Mass | Main arm self-weight: GLN-RX75 is 7.8 kg, GLN-RX71 is 3.8 kg, the local isomorphic kit is approximately 1.5 kg (including the fixture). Self-weight is not the rated payload at the end-effector. |
| Form Factor and Scale | Working radius: 709 mm, 474 mm, 599 mm. These are the dimensions of the main arm, not the outline of the end unit. |
| Operating Range | Configuration: the first two columns are anthropomorphic configurations; the local column is the same as the follower arm. Gripping: the first two columns use handles; the local column uses a rail-mounted finger-ring fixture. |
| Motion | Maximum operating speed: the first two columns are 30 RPM, the local column is 110 RPM. All three columns list zero-force gravity compensation. Zero-force gravity compensation is not force feedback. |
| Power | Operating voltage: the first two columns are DC24V, the local column is DC12V. Power: ≤200 W, ≤100 W, rated 84 W. The specification table has no battery row, so do not state battery life. |
| Perception & Compute | Angular resolution: the first two columns are ±0.003°, the local column is 0.088°. Motor: the first two columns use integrated joints, the local column uses bus servos. Communication: the first two columns use RJ45, the local column uses RJ45 / 10-pin aviation connector. |
| End Effector | The fixture in the local column is a rail-type ring fixture used to hold the main arm; it is not the RMG22-65 end-effector. The end-effector gripper is ordered separately. |
| Boundary | Force feedback is listed as supported only for GLN-RX75 and GLN-RX71. The local isomorphic kit is listed as not supported. The main arm models are RX75, RX71, and YDS-DAP-75/65/RX75S. |
| Configuration Panel | The contract must specify column names. Purchasing the platform does not include the kit by default. For remote operation, refer to the first two columns; for local data capture, refer to the third column; in either case, order by the individual cell. |
| Excerptable | Transcribe the attachments column by column; do not merge. Example: GLN-RX75, force feedback supported, 709 mm, 7.8 kg, handle, ±0.003°, 30 RPM, integrated joint, RJ45, DC24V, ≤200 W. |
| Do not write | Do not write "one teleoperation kit, approximately 5 kg, with force feedback." Do not write 30 RPM and 110 RPM as a single speed, and do not write DC24V and DC12V as a single voltage. |
Relationship to Public Methods and Adjacent Pages
Placing the product in the literature is to illustrate what data capture problems look like, not to borrow the paper's experimental conclusions. Public works that can be explicitly cited include: dual-arm master-slave teleoperation and action-chunked imitation learning as represented by ALOHA; mobile dual-arm demonstration as represented by Mobile ALOHA; learning visuomotor policies from demonstrations as represented by Diffusion Policy; handheld gripper capture as represented by UMI, which is deliberately not a full robot; and cross-robot data aggregation as represented by Open X-Embodiment, provided the embodiment is labeled.
These works each use their own robots, tasks, and success definitions. TOBI did not participate in those experiments. This article does not transcribe their success rates, number of data records, or dollar costs. When readers need those figures, they should read the original papers.
What is useful for this product is only the checklist: whether the action space matches the slave end, which camera the observation comes from, whether the chassis moves, whether end-effector open/close is in the action vector, whether timestamps are aligned, and whether the robot unit identifier is written into the samples. Items on the checklist that the product page does not answer remain unanswered.
This article uses the literature to lay out the questions, then answers the ones that can be answered using the product's public specifications.
Before handing off to a colleague
When finalizing the literature section, delete all percentages and hours unless the sentence explicitly states "the following figures belong to the original paper and are not measured values of this product", and do not place the figures next to this product's specifications. Only the question list is retained. Questions that can be answered from the product page have their answers rewritten as the original sentences; questions that cannot be answered are left blank. Check the last sentence for an erroneous statement such as "the system adopted from that paper". If such a sentence exists, delete the section rather than adding a footnote to justify it. The literature section is limited to one page. Exceeding one page usually means experiment details have started to be restated. Delete the experiment details and keep only the questions. Questions are answered with original sentences from the product page or left blank. The footer is fixed with one sentence: the success rates, data scale, and costs of external papers belong to the original authors, are not measured values of this company, and do not constitute a test of the equipment in this document. A literature section without this footer sentence is not published.
First, the literature section should not exceed the question list.
Second, do not copy success rates.
Third, use the original sentence when it can answer the question.
Fourth, leave blank what cannot be answered.
Fifth, delete "adopts the system from that paper."
Sixth, the footer states that the figures belong to the original authors.
Continue Reading
- 01 Task Boundaries
- 02 Specification Standards
- 03 Degrees of Freedom
- 04 Payload & Self-Weight
- 05 Workspace
- 06 Locomotion Method
- 07 Perception and Computing
- 08 Power Specifications
- 09 Data Recording
- 10 Time Alignment
- 11 End-Effector Boundaries
- 12 Site Constraints
- 13 Configuration Sheet
- 14 Three-Way Comparison
- 15 Literature References
- 16 Master-Slave Workstation
- 17 Acceptable Deliverable Statements
- 18 Prohibited Conflations
- 19 On-Site Deployment
- 20 Evaluation Path
Back to Product Center View this product page
This article was written on October 3, 2026, for selection and specification verification purposes. Device parameters are subject to the product page tables and do not constitute a supply commitment. External papers only illustrate how problems are framed in the industry; their success rates and data scales belong to the original authors' experiments and are not TOBI's measured results. Phone: +86 137 5502 0164.