
To build a system that can work on-site without the operator having to stand next to the robot, the order needs at least three lines: the robot body at the worksite, the teleoperation kit in the operator's hands, and the software platform responsible for tasks and data. TOBI selects, combines, and delivers according to these three lines. The numbers for each line are copied only from the corresponding product page, not collapsing three machines into a single advertising sentence.
What the three things each answer
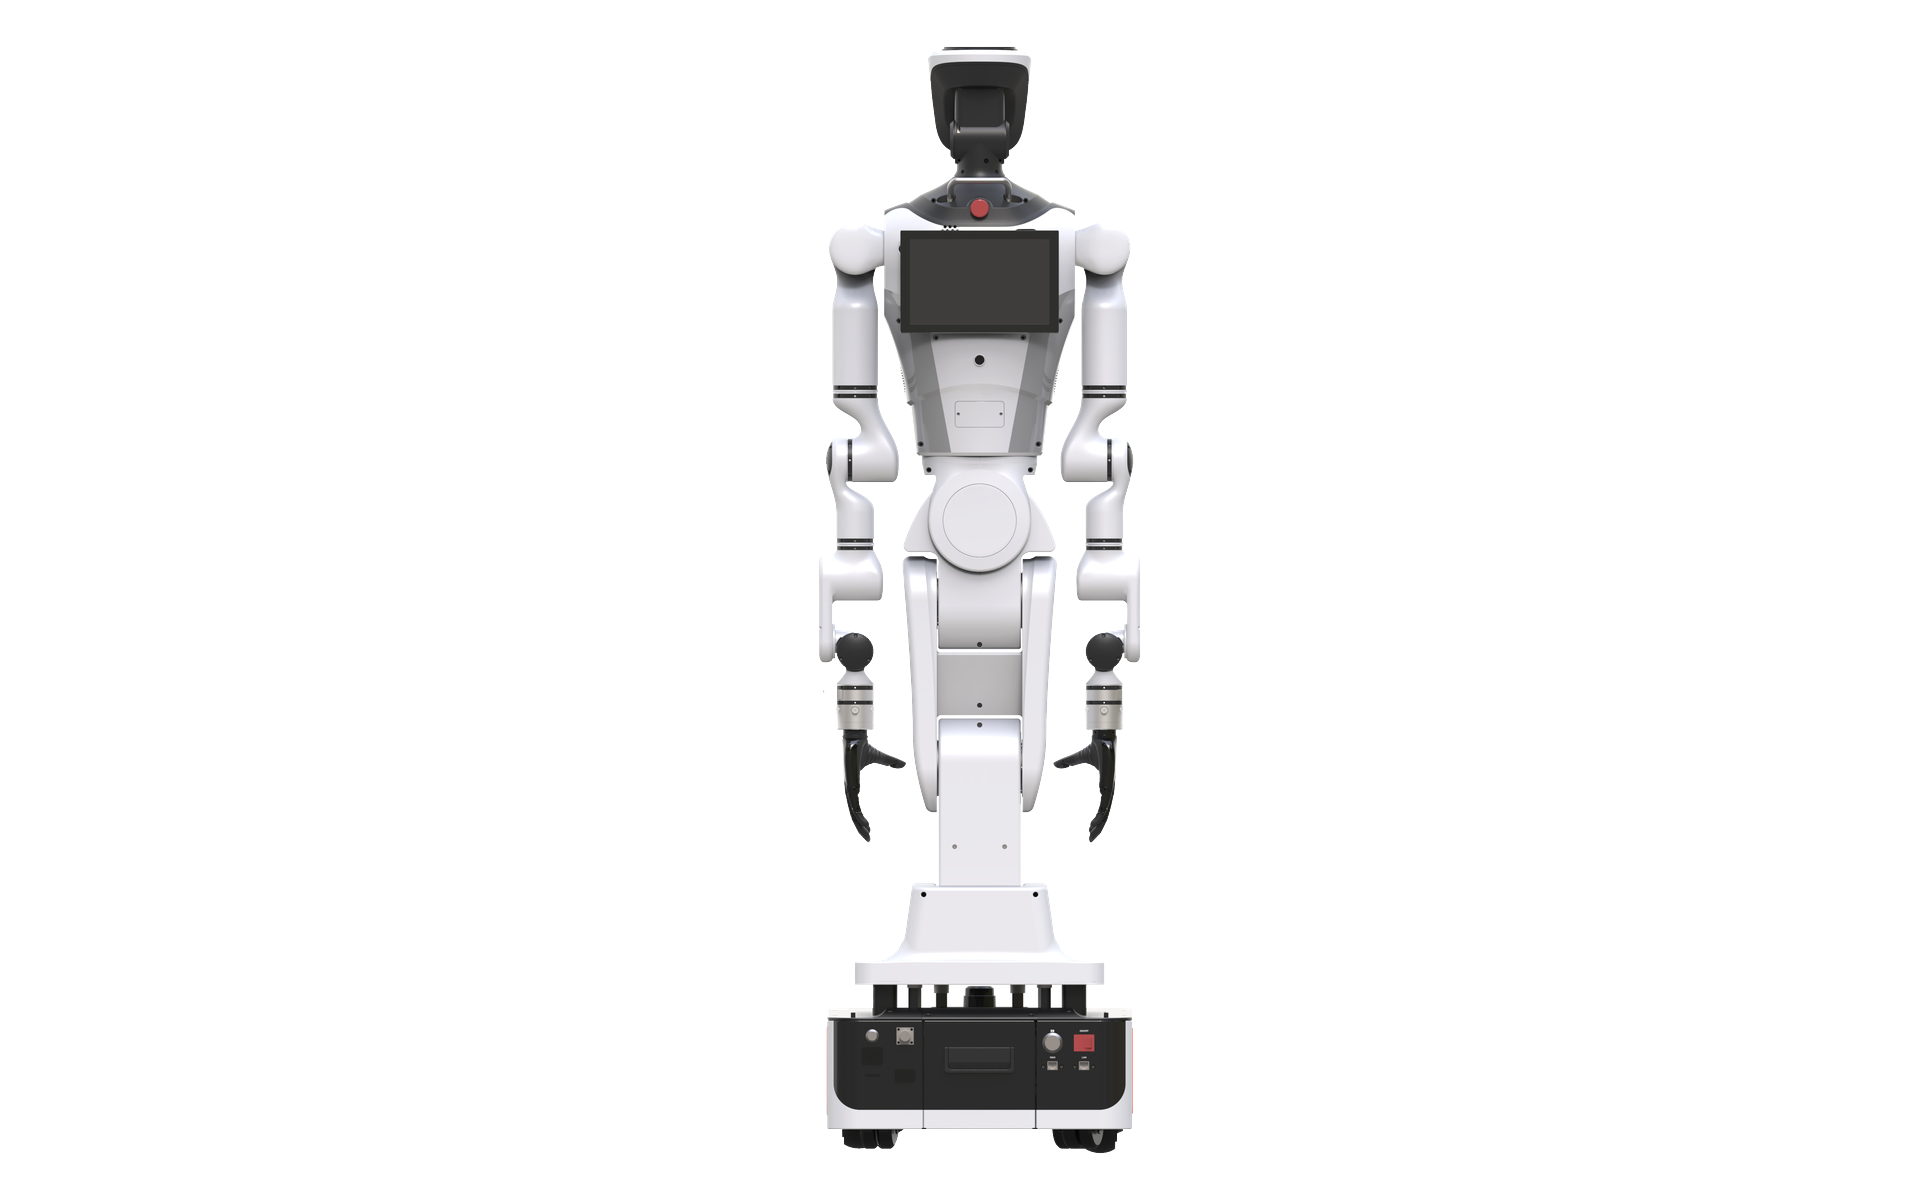
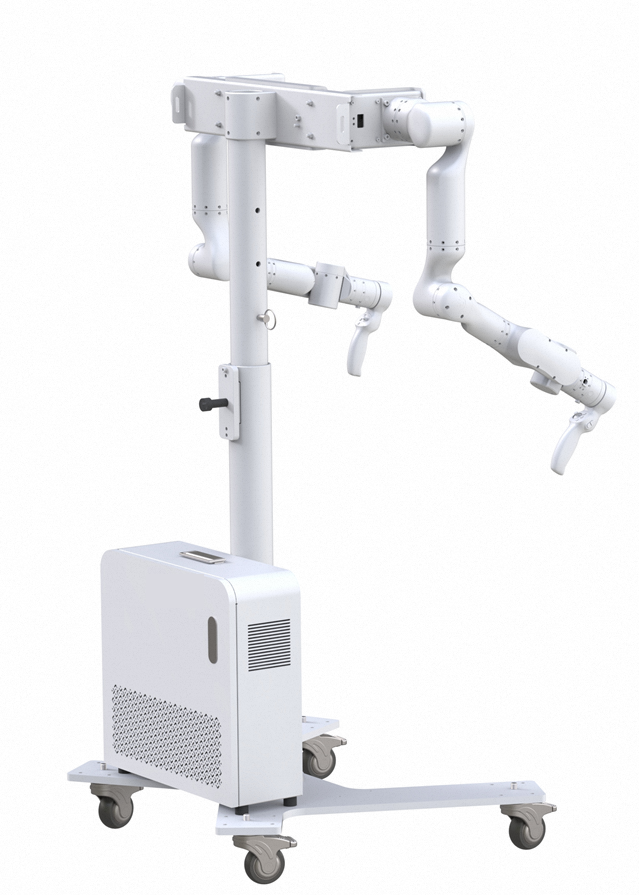
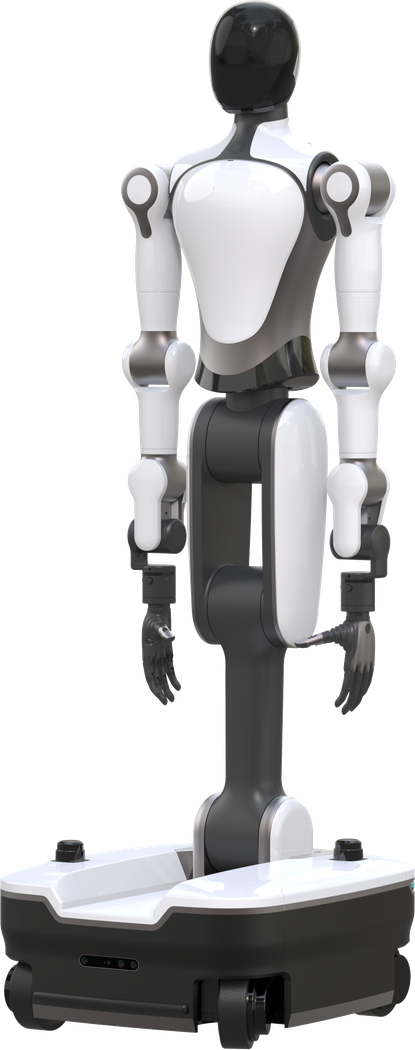
The embodiment is the operating terminal. It executes actions on site and sends back video and status. Three units have already been published on the site, and only one can be chosen:Wheeled folding dual-arm, Wheeled lifting dual-arm RMC-AIDAL, Wheeled Humanoid. The degrees of freedom, payload, power supply, and camera lists of the three machines are all different. The selection document is written separately; for now, just remember that they cannot be merged into one table.
The kit is the master control end. The operator pushes the master arm, and the motion is mapped to the robot's slave arm. The on-site kits are listed in three columns: GLN-RX75, GLN-RX71, and the local isomorphic kit. The first two columns support force feedback; the local column does not. Purchasing the body does not mean the kit is already in the box; the kit must be written as a separate line item.
The software platform is the third item in the October 2026 solution plan. The plan divides it into four parts: the teleoperation client used by front-line operators, the devices and tasks in the management backend, data acquisition scheduling, and the data dashboard for management. TOBI organizes delivery according to this scope. This article does not describe these four parts as software brands manufactured by TOBI, nor does it rewrite the source of the plan into another name that can be attached to the page.
How the three layers work together
The plan divides operation into three layers. The teleoperation workstation is on the operator's side, including the person, the display system, and the master arm. The cloud is responsible for device access, tasks, storage, and scheduling. The robot worksite includes the body, end effector, sensors, and network. Control commands go from the workstation through the cloud to the worksite; video and status from the worksite return to the workstation. The plan summarizes this closed loop in one sentence: see it, control it, retrieve it.
The view names mentioned in the plan include dual-arm view, forward view, and 360° overhead view. These are terms from the architecture description, not a unified camera list for the three bodies. The folding model's head has binocular RGB ×1 plus fisheye ×2; hand RGBD is standard, monocular RGB is optional. The lifting model's standard vision is D435 ×1 and wide-angle camera ×2. The wheeled humanoid lists optional binocular depth or RGB, plus 130° wide-angle ×3. The number of channels in the contract follows the list on the purchased product page, not this architecture slogan.
What does TOBI do in this order
TOBI combines the publicly available bodies, kits, and end effectors into executable configuration lists, and schedules workstation, network, and platform activation into the delivery steps according to the plan. The configuration list must be traceable line by line in the product pages. Sentences that cannot be found—including unpublished whole-machine degrees of freedom, unwritten battery life in hours, and payloads that conflict with the parameter table—do not enter the quotation appendix.
There are three sentences that commonly appear in plan drafts but cannot be copied verbatim on the site. First, do not write "factory-calibrated, no secondary calibration required." Time alignment and calibration are confirmed per project. Second, do not write "the kit achieves whole-body control of dual arms, grippers, chassis, lifting, waist, and head for all bodies." Whether the chassis, lifting, waist, and head exist depends on that body's product page. The lifting model has not published whole-machine degrees of freedom, so it cannot be filled in as waist or neck. Third, do not write "master-slave isomorphic so the data has zero domain shift." Isomorphism is a configuration description; zero domain shift is not a measured result in the parameter table.
Continue Reading
- Order the three robot bodies separately: folding, lift, and wheeled humanoid
- Kits Sold by Column: Force Feedback in the First Two Columns, None in the Local Column
- Seven Steps to Deploy a Workstation: Display, Power, Network, and Integration Testing
- A Day in the Loop: Task Dispatch, Teleoperation, Storage, and Acceptance
- Full Teleoperation Delivery Now, Autonomy Written into Later Phases
Device page:Folded Arms, Lifting Dual-Arm RMC-AIDAL, Wheeled Humanoid, Isomorphic teleoperation kit, Two-finger gripper RMG22-65. The main entry point isProducts.
This article was written on October 4, 2026, based on that month's teleoperation system build plan, and published after being rewritten according to the parameter tables on the in-site product pages. Figures that conflict with the product pages do not enter external messaging. The software platform is described according to the delivery scope of the plan, not written as a TOBI manufacturing claim, nor rewritten as another company's brand. Phase 2 and Phase 3 are evolutionary directions and do not constitute a commitment to already-delivered autonomous operation. Phone: +86 137 5502 0164.