
The deployment plan allows selecting one wheeled platform on site, but what can be ordered on the site are three machines that have already been published, and the three spec sheets must be copied separately. It is fine to state "use lift for high positions, folding for narrow spaces, and wheeled humanoid for general tasks" as a single procurement recommendation, but their payloads and dimensions must not be written as a single row.
Separate Purchase Tables
| Projects | Folded Arms | Lifting Dual-Arm RMC-AIDAL | Wheeled Humanoid |
|---|---|---|---|
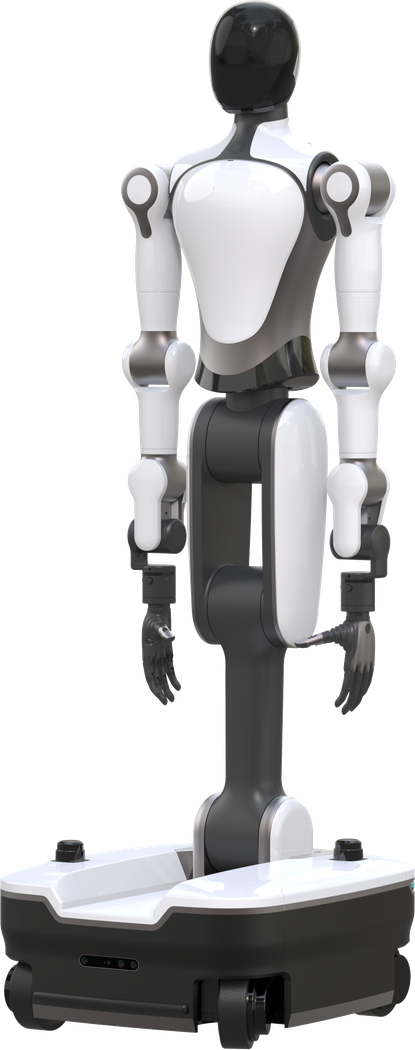
| Degrees of Freedom | Whole machine 20 DoF, single arm 7 | Only single arm 7 published (RM75-B-V table). No whole-machine degrees of freedom | 21: dual-arm 14, waist 3, legs 2, neck 2 |
| Payload | Single-arm rated 5 kg | Single-arm rated 5 kg. The 8 kg in the table is the single-arm self-weight | single-arm 5 kg |
| Overall machine mass | Approx. 125 kg | Approx. 80 kg | Approx. 125 kg |
| Dimensions | 614 × 552 × 1700 mm | Retract 640 × 450 × 1780 mm | 570 × 465 × 1680 mm |
| Vertical range | 0–2.1 m | 0–2.4 m, lifting stroke 900 mm | Vertical Arm Span 2100 mm |
| Mobile | Four-wheel steering, 0.1–1.5 m/s | Two-wheel differential drive, 1.5 m/s, 5° slope climbing | 0.1–1.5 m/s, in-place rotation radius 690 mm |
| Power | 48V 20Ah / approx. 6 h | Lithium iron phosphate DC 48V 20Ah, hours not specified | 40 Ah. Approximately 2 hours is charging time, not battery life |
| Compute | Jetson AGX Orin 64G, SSD capacity not specified | Orin 64G, plus a 1T solid-state drive | Vision and LiDAR see product page; do not copy the 1T over |
The folding model is suitable for projects that write "20 active degrees of freedom for the whole machine, four-wheel steering and four-wheel drive, approximately 6 hours" into the same appendix. The approximately 6 hours belongs only toFold-out page. The lift model's battery row has no hours; do not fill in 6 just to make the table look tidy.
For the lift model, the parameter table is authoritative.
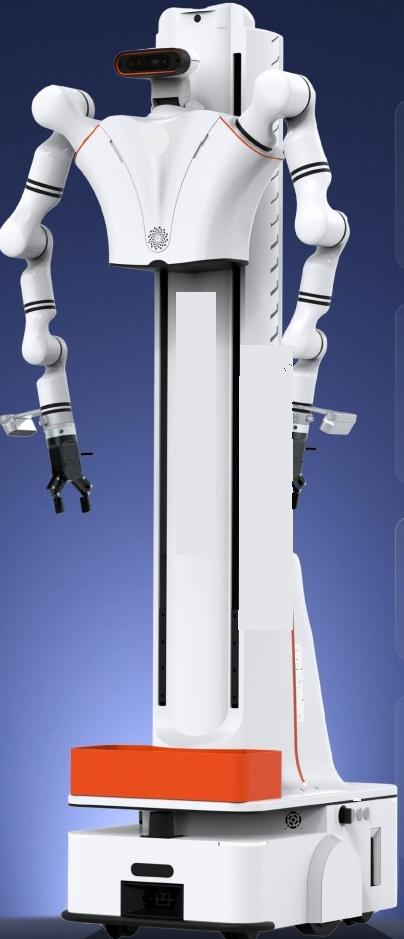
Lift Model PageThe model is RMC-AIDAL. The rated payload of a single arm is 5 kg. The 8 kg in the parameter table is the self-weight of a single arm. The dual-arm rated 8 kg once written on the cover conflicts with the parameter table; externally, the parameter table is authoritative. The vertical working range is 0–2.4 m, the lift stroke is 900 mm, and the reach of a single arm is 633 mm. The standard configuration lists the robotic arm as RM65-B-V ×2, while the robotic arm parameter table lists the model as RM75-B-V. Both sets are retained; lock the choice before ordering and do not collapse them into one.
Do not write the specifications of the other high-position model into this one: vertical 2.1 m, single arm 9 kg, dual arm 15 kg, lift load capacity 60 kg, as well as 650×512×1700 mm, approximately 120 kg, and lift 0.3 m. Those numbers do not describe the RMC-AIDAL. If the proposal draft contains this set of numbers, delete them from the quotation attachment and replace them with this paragraph.
Do not borrow the folding model's battery life for the wheeled humanoid
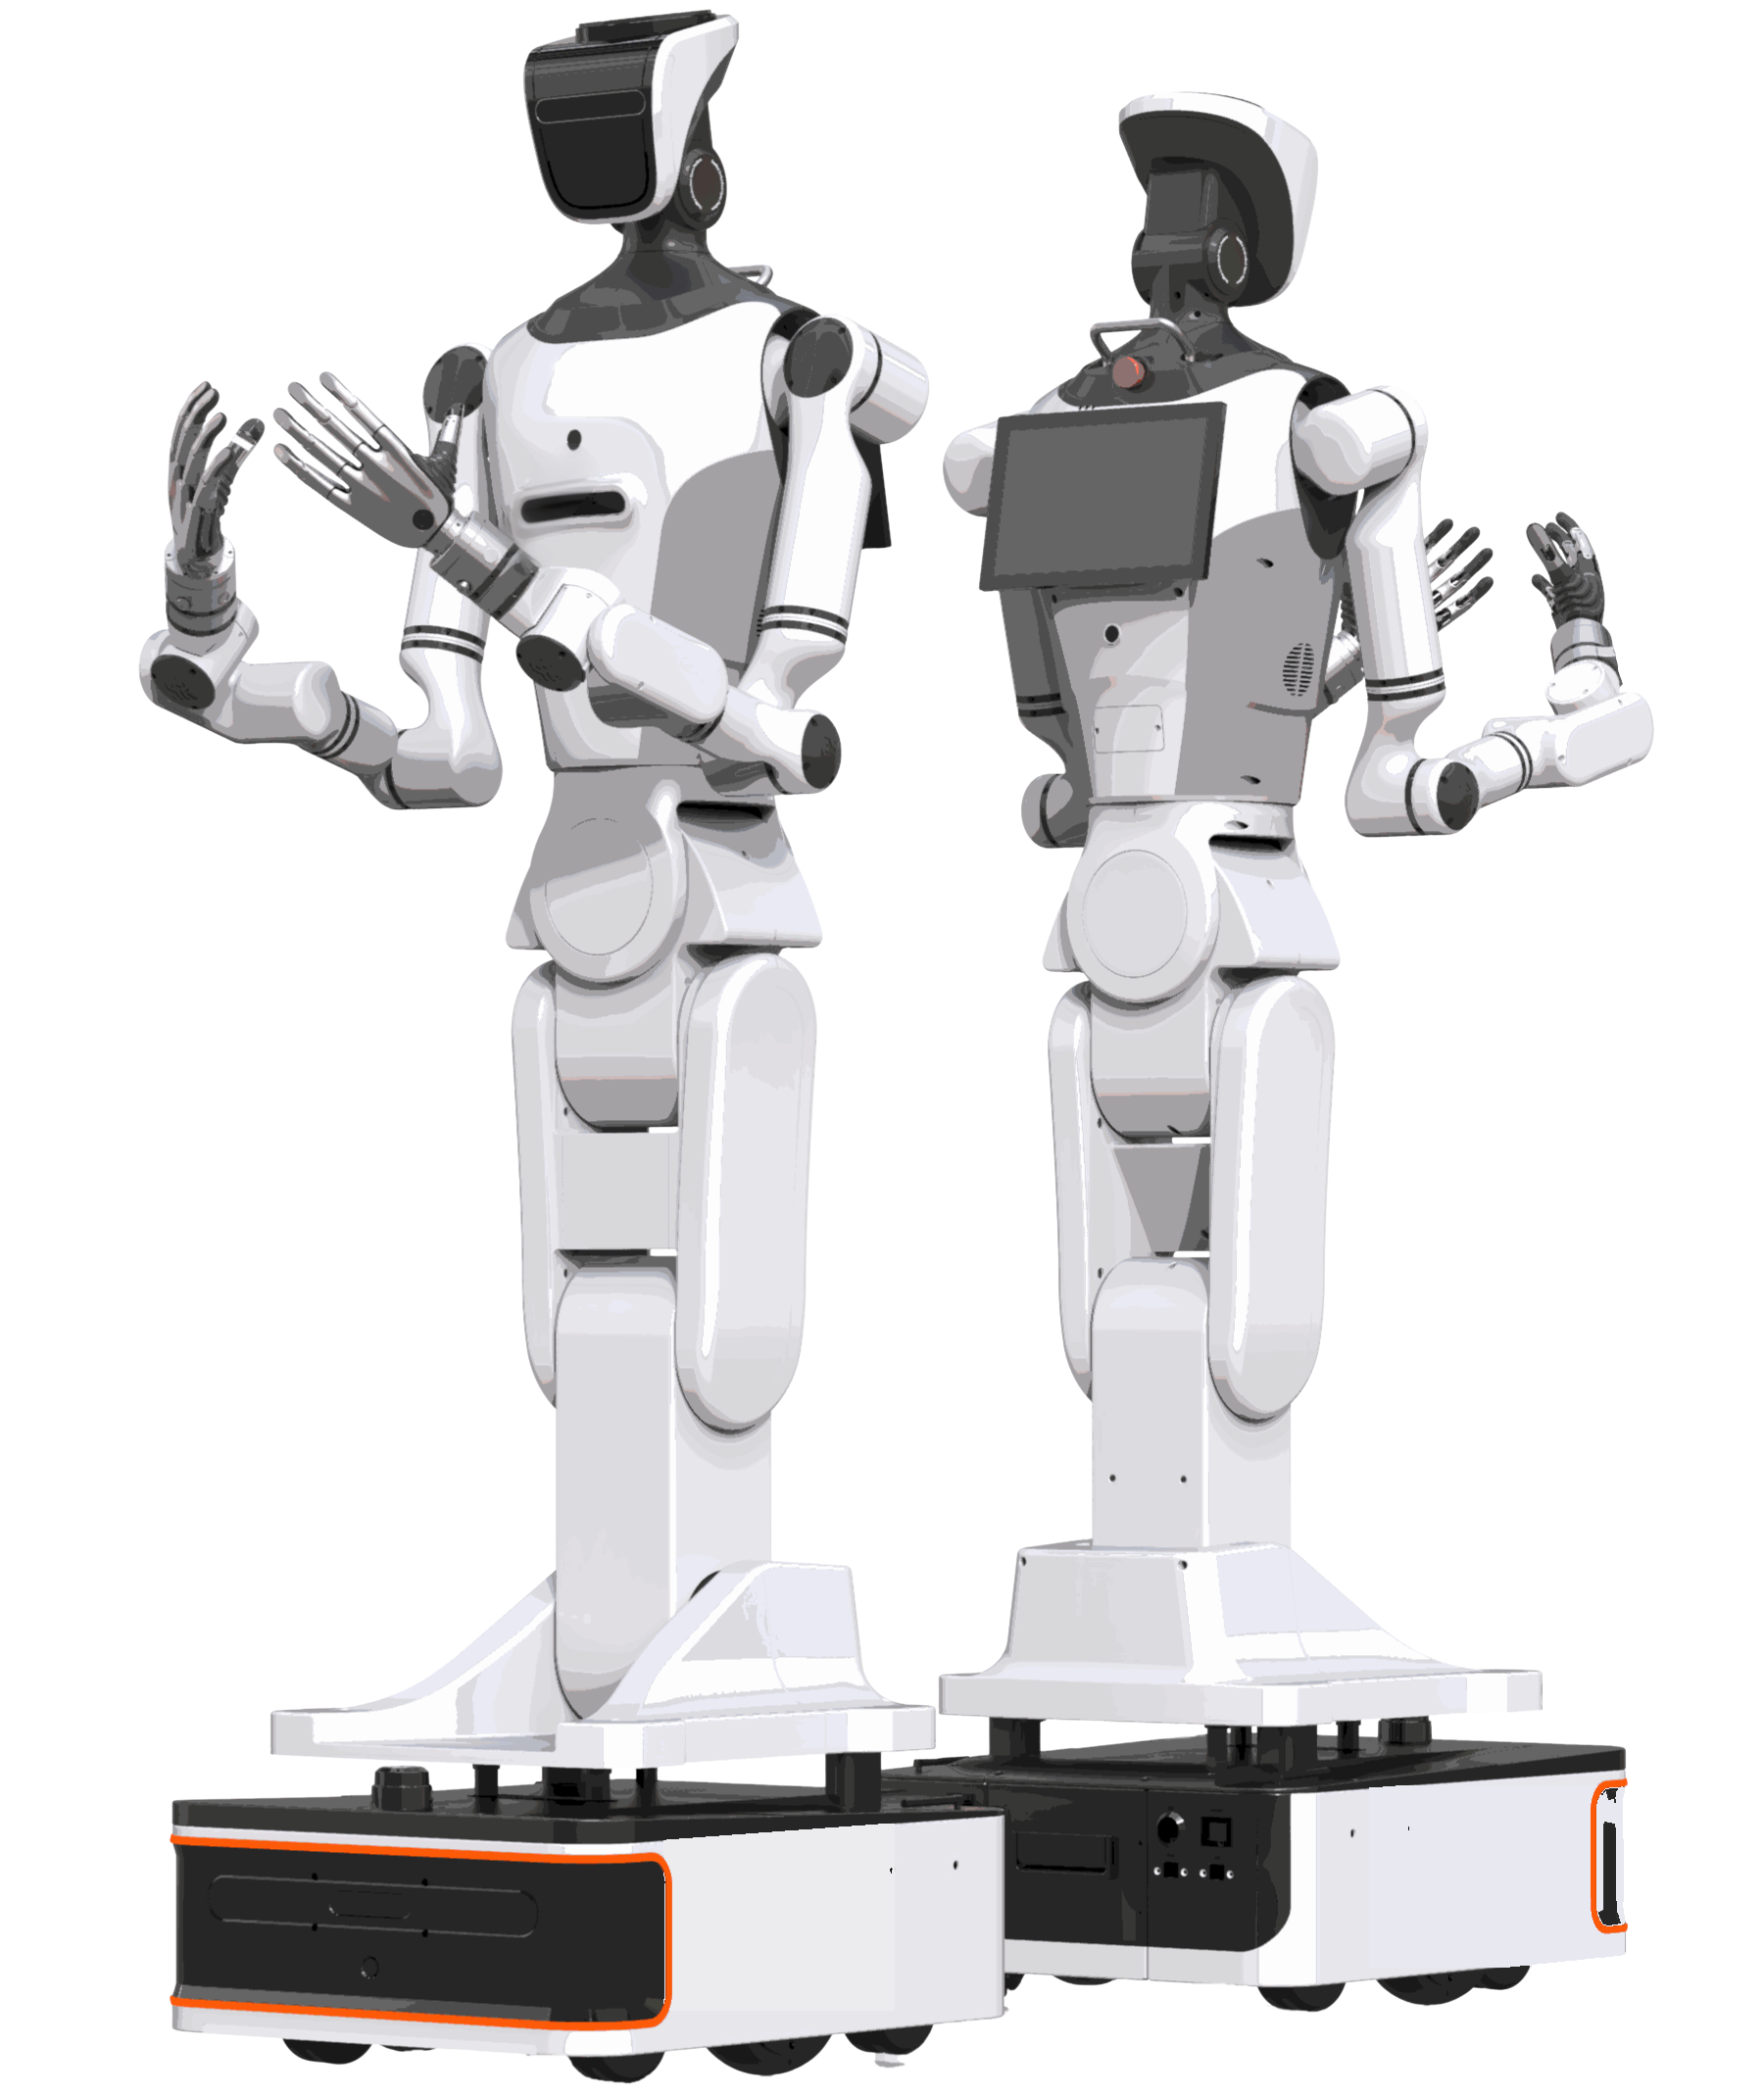
Wheeled Humanoid21 active degrees of freedom in total. Dimensions 570×465×1680 mm; shoulder width and chassis width are both to be understood as within 465 mm. Horizontal arm span 1818 mm, excluding the end effector. The rotation radius 690 mm refers to in-place rotation. Movement speed 0.1–1.5 m/s. Battery 40 Ah, charging takes approximately 2 hours. The page does not state battery life in hours; do not write it as capable of 2 hours of continuous operation, nor as approximately 6 hours for the folding model.
The folding model page does not publish a 413 mm turning radius, nor does it publish 90° lateral movement. The turning specification for the wheeled humanoid is 690 mm in-place rotation. Do not rewrite either sentence as "extremely small turning radius 413 mm." A dexterous hand or gripper can be added to the end effector depending on the task; the compatibility list on the page is not a standard configuration list.RMG22-65 Both this and the CTAG2F90-D in the lift model's recommended configuration column must be specified by model number.
Lock Three Rows When Ordering
The first row locks the main body page; copy only the table on that page. The second row locks the end effector: included in the box, recommended configuration, or purchased separately. The third row locks the teleoperation kit column name; the main body order does not include the kit by default. If any of the three rows is missing, mismatches in lift stroke, force feedback, or gripper protocol will only be discovered during integration testing.
Continue Reading
- Break Teleoperation into Three Parts: Robot Body, Kit, and Software Platform
- Kits Sold by Column: Force Feedback in the First Two Columns, None in the Local Column
- Seven Steps to Deploy a Workstation: Display, Power, Network, and Integration Testing
- A Day in the Loop: Task Dispatch, Teleoperation, Storage, and Acceptance
- Full Teleoperation Delivery Now, Autonomy Written into Later Phases
Device page:Folded Arms, Lifting Dual-Arm RMC-AIDAL, Wheeled Humanoid, Isomorphic teleoperation kit, Two-finger gripper RMG22-65. The main entry point isProducts.
This article was written on October 4, 2026, based on that month's teleoperation system build plan, and published after being rewritten according to the parameter tables on the in-site product pages. Figures that conflict with the product pages do not enter external messaging. The software platform is described according to the delivery scope of the plan, not written as a TOBI manufacturing claim, nor rewritten as another company's brand. Phase 2 and Phase 3 are evolutionary directions and do not constitute a commitment to already-delivered autonomous operation. Phone: +86 137 5502 0164.