Capture / end effector
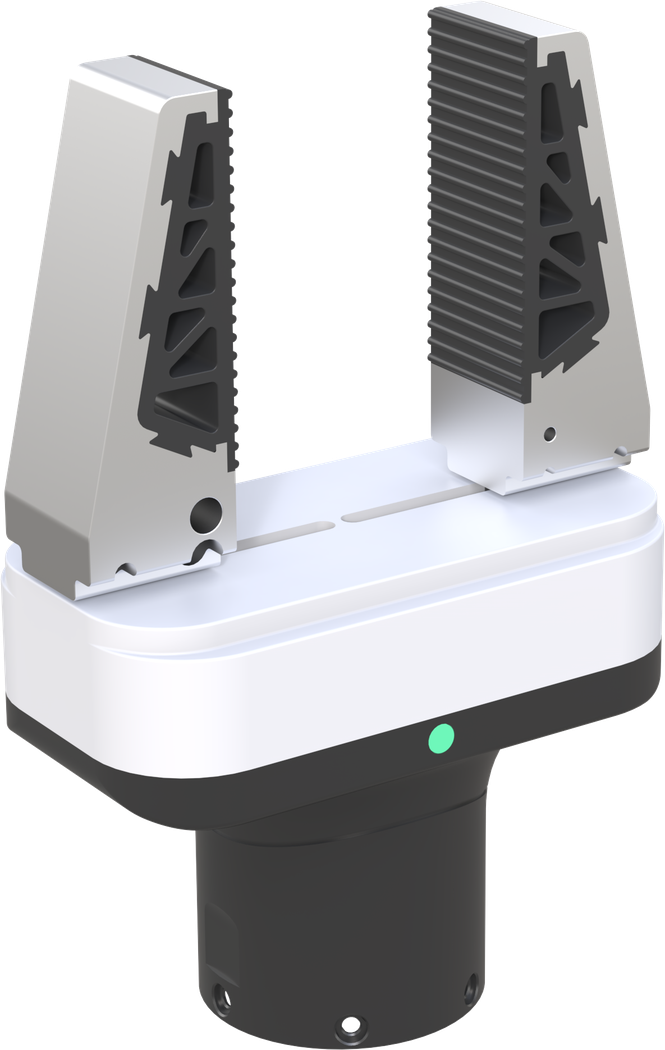
Parallel two-finger gripper
Model RMG22-65. Stroke, force and load are three different numbers.
Mass 745 g. Max enveloping grasp load 5 kg. Recommended max friction load 2 kg. Max grip force 130 N. Stroke 65 mm. Open or close time 2 s. Position repeatability ±0.05 mm. Protocol RS485 / Modbus-RTU.
Source: current published technical data · 2026-10-03
IMAGES
Product images
SPECIFICATIONS
Specifications and limits, together.
Checked 2026-10-03. Table figures match the current published technical data and are not rewritten here. If an older scheme note disagrees on battery or runtime, this table wins.
| Model | RMG22-65 |
|---|---|
| Size | 112 × 60 × 167 mm |
| Stroke | 65 mm |
| Finger height | 80 mm |
| Mass | 745 g |
| Max enveloping grasp load | 5 kg |
| Recommended max friction load | 2 kg |
| Grip force | 130 N max |
| Open / close time | 2 s |
| Repeatability | ±0.05 mm |
| Voltage | 24 V |
| Rated / max current | 1.9 / 5.7 A |
| Rated / max power | 45.6 / 136.8 W |
| Connector | 6-pin |
| Protocol | RS485 / Modbus-RTU |
| Environment | 0–50 °C · ≤85% RH |
FAQ
Write this down before ordering.
Which load is the acceptance figure, 5 kg or 2 kg?
The max enveloping grasp load is 5 kg. The recommended max friction load is 2 kg. An object held by friction is judged at 2 kg. 5 kg is not a guarantee for every grasp.
How does it connect to a teleop base?
The bases publish a 2-finger quick-change interface. Whether the flange, harness and protocol match RMG22-65 directly is confirmed on the configuration sheet. It is not plug-and-play by default.
PROJECT ASSESSMENT
Tell us the task. We will confirm the configuration.
Reply within about one business day. The specification table is on this page. Price, lead time, and whether an end effector or teleop station is included are confirmed in writing before the order.
+86 137 5502 0164