TOBI

PRODUCTS · CAPTURE HARDWARE

Select data capture hardware by task requirements

Filter E2, E6, E8, hand mocap gloves and peripheral modules by form factor and capability. Review specifications, recording samples and integration requirements; development targets require separate validation.

7 matching devices
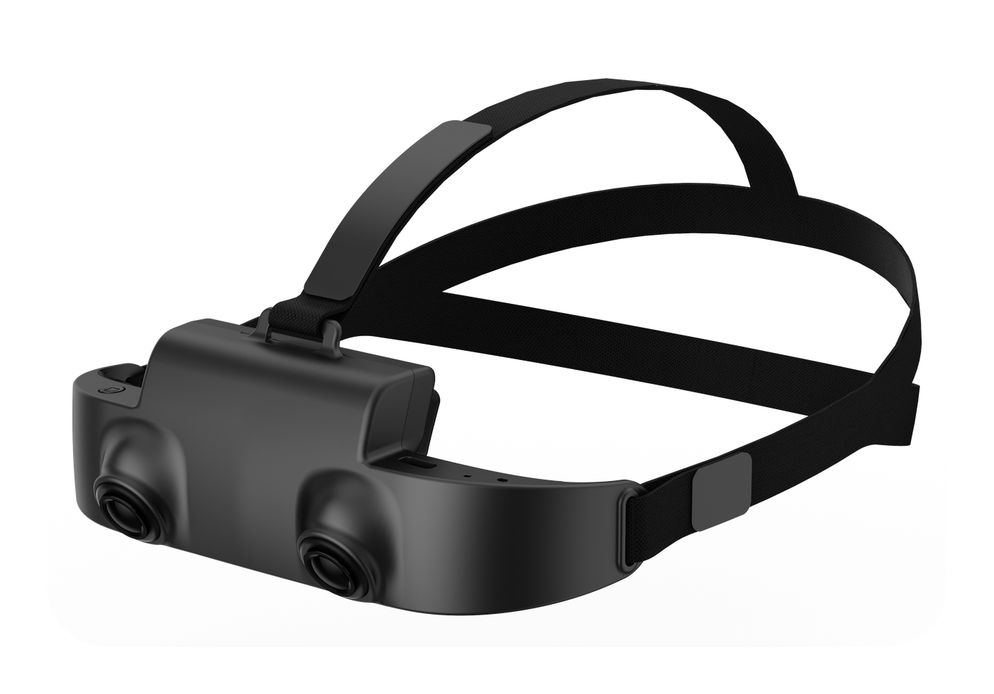
In productionE6 · Six-Camera Ego Capture Device

E6 · Six-Camera Ego Capture Device

4 global-shutter grayscale cameras plus 2 RGB cameras with on-device SLAM output. Choose between the two RGB sensor versions when ordering.

6 cameras4 grayscale + 2 RGB
370grear-battery balance
<1μscamera hardware sync
~2kHzIMU + 6DoF output
On-device trajectoryGlobal shutterPeripheral sync
View details →
In productionE2 · Lightweight Binocular Ego Headband

E2 · Lightweight Binocular Ego Headband

Two RGB global-shutter cameras (1600×1200@30fps), per-camera HFOV 139° / VFOV 111°, IMU 800 Hz, 65 mm baseline, for multi-site long-cycle capture. E2 has no on-device SLAM; pose is reconstructed offline on a computer.

2× RGB GS1600×1200@30fps
H139° / V111°per-camera FOV
800 HzIMU rate
<150g / >5hweight / runtime (1600mAh)
Global shutterPeripheral sync
View details →
Development stage / supply to confirmE8 · Multimodal Ego Capture Platform

E8 · Multimodal Ego Capture Platform

The matrix lists ten cameras plus TOF and mocap expansion; the former detail page lists a different configuration. Tracking figures are development targets; confirm camera configuration, current supply and motion-capture options.

10 + TOFconfiguration to confirm
280g120g main unit
48 TOPSXR2 Gen2 NPU
1.5mmSLAM target
On-device trajectoryGlobal shutterDepth dataPeripheral syncFull-body mocap
View details →
Development stage / supply to confirmWrist Camera

Wrist Camera

Adds a close-up first-person view for fine hand operations and synchronizes to E6/E2 using PPS + UART.

1280×102430 / 60fps
100gwrist-worn
200°diagonal FOV
<1mshost sync
Peripheral sync
View details →
In productionG7 · Magneto-Inertial Hand Mocap Glove

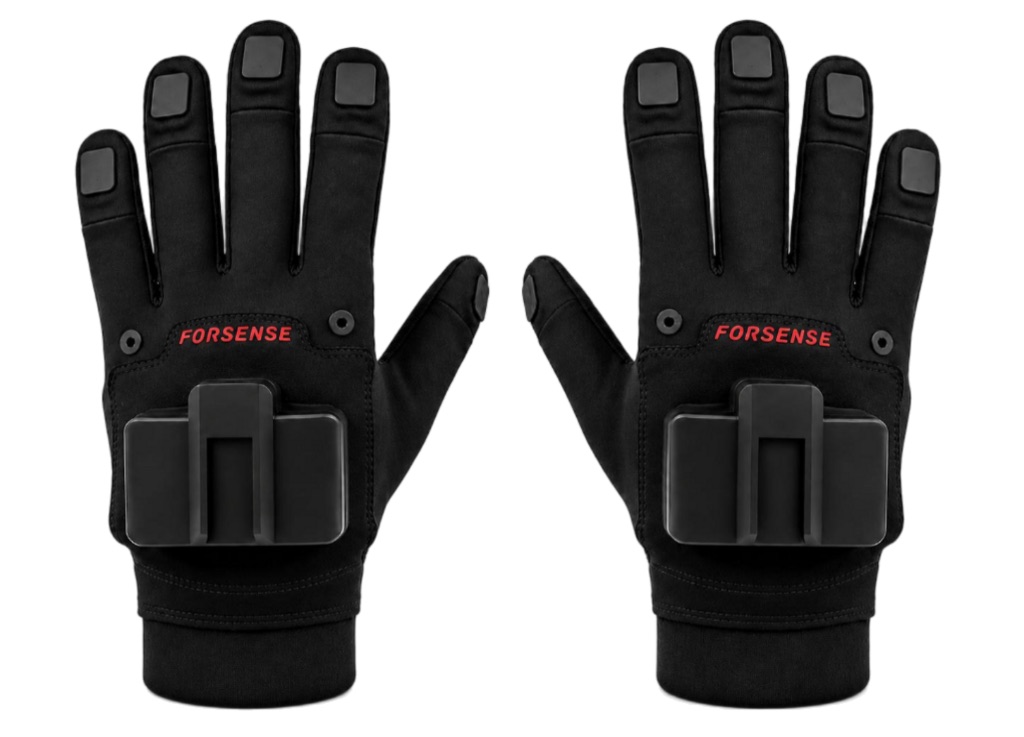
G7 · Magneto-Inertial Hand Mocap Glove

Forsense production · TOBI integration. Choose G7 for fingertip spatial pose: 5× EMF+IMU, 120 Hz, <20 ms wired / <30 ms wireless, 2 mm / 3° (datasheet). Prefer G2-L in metal-heavy or close bimanual scenes.

120 Hzsensor rate
<20 / <30 mswired / wireless E2E
2 mm / 3°position / orientation
115 g±5 gper glove
Hand mocapPeripheral sync
View details →
In productionG2-L · Wireless Inertial Hand Mocap Glove

G2-L · Wireless Inertial Hand Mocap Glove

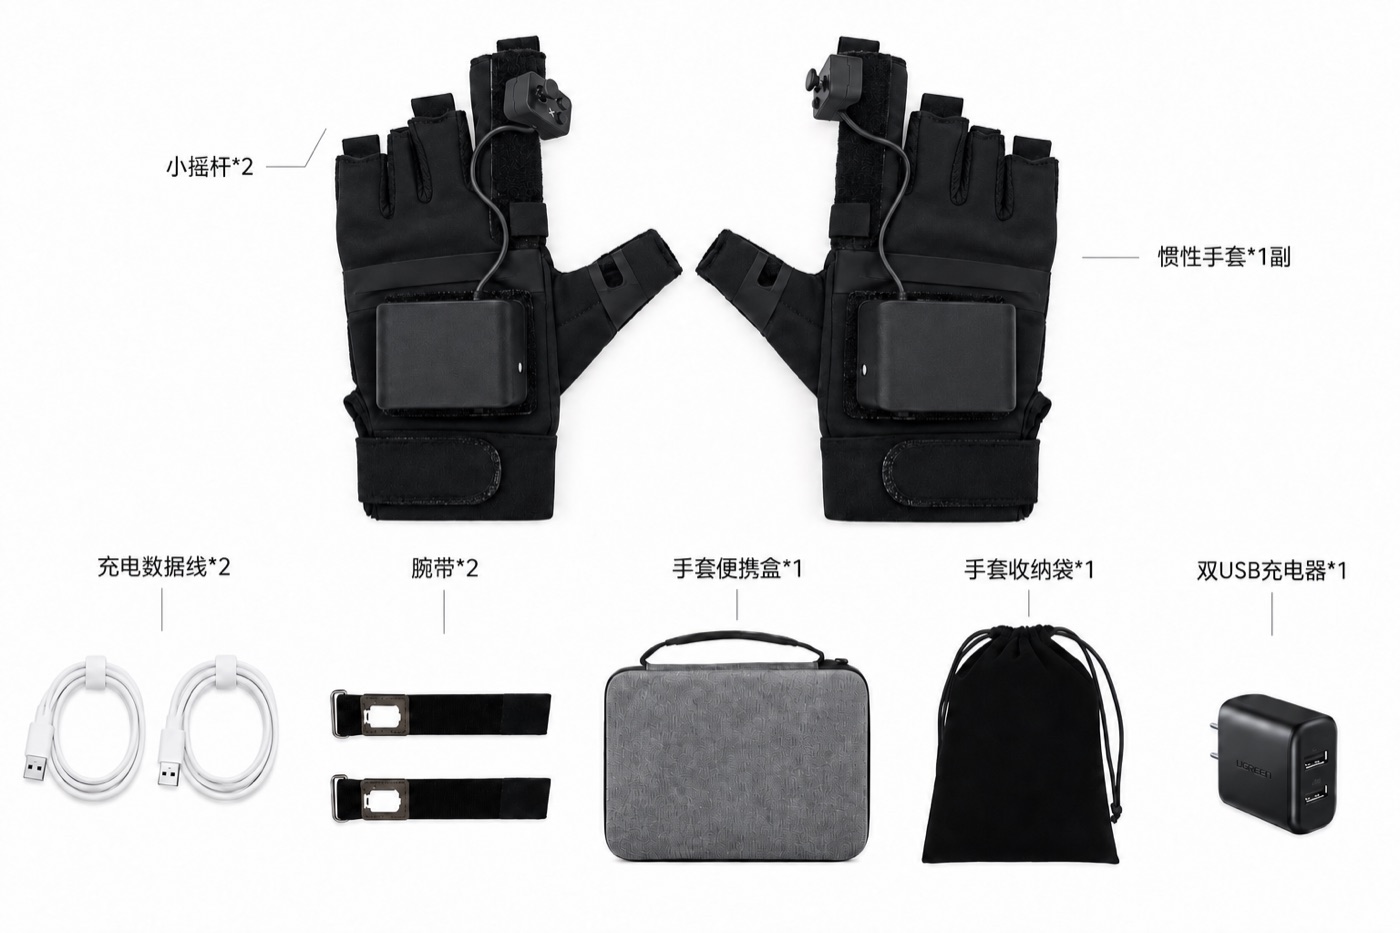
In the product illustration

  • Mini joysticks ×2
  • Inertial gloves ×1 pair
  • Charging/data cables ×2
  • Wrist straps ×2
  • Glove carrying case ×1
  • Glove storage bag ×1
  • Dual-USB charger ×1

Illustration only. Final delivery is subject to the written specification.

Forsense production · TOBI integration. Wireless long-session gesture capture: 1+8+wrist IMU, ≤20 ms, 50 Hz, BT 5.1, 7 h (datasheet). Need millimeter-level fingertip position tracking? See G7.

1+8+wristIMU layout
≤20 mssignal latency
50 Hzoutput rate
7 h / 90 g±5 gbattery / weight
Hand mocapPeripheral sync
View details →
Development stage / supply to confirmRing Locator Module

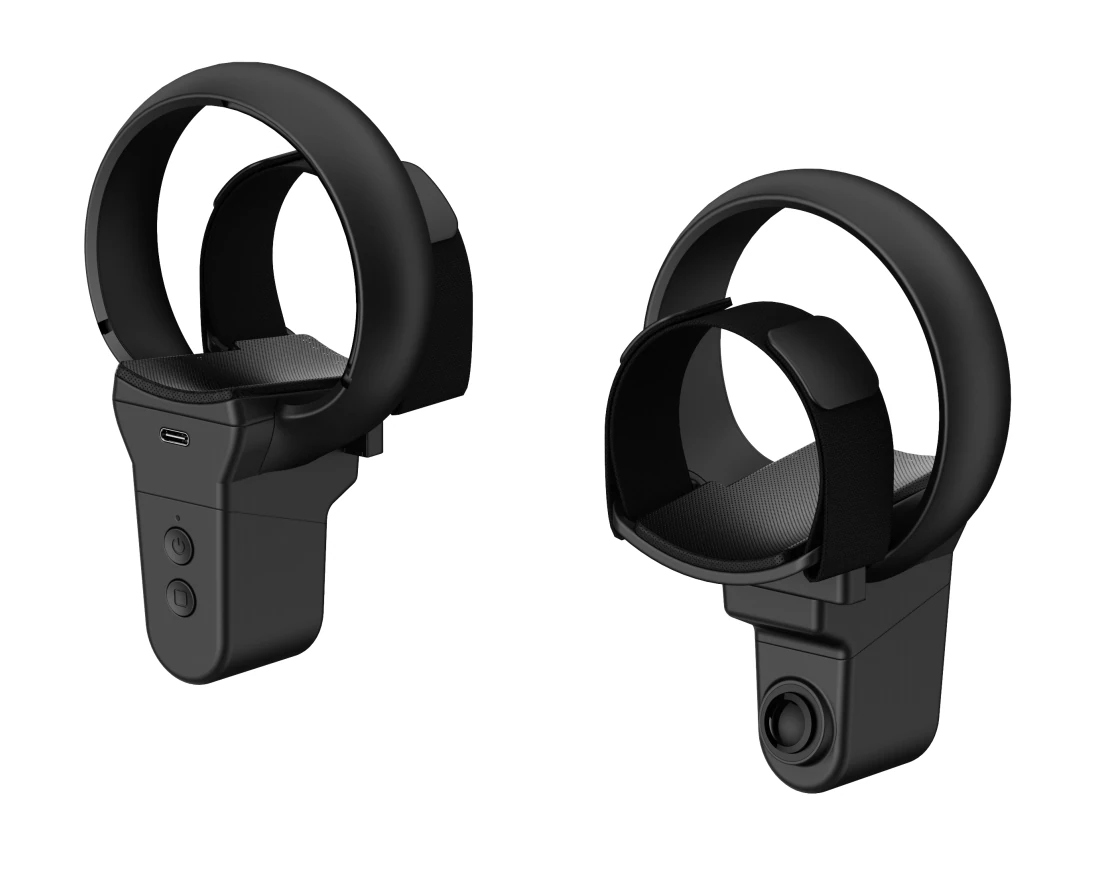
Ring Locator Module

For locating grippers and external sensors; joint positioning and synchronization with E6/E8 are confirmed per project.

80glocator
Type-Cinterface
PPS + UARTsync interface
To be confirmedsupply to confirm
Peripheral sync
View details →
Technical comparison
Select 1–3 devices to generate a comparison matrix
Not sure which combination to choose? Let our engineers recommend a complete setup for your capture task.

Haven’t chosen a model yet? Share your task requirements, and an advisor will recommend a combination of devices, peripherals and datasets, with a quote. For ready-made datasets, you can order directly from the Data Market.

Book a Complete-Solution Evaluation Delivery formats Browse Ready-Made Datasets →