Chief Scientist Perspective | 2026-09-13 Industry Review
We first put the core claims of the public paper EgoDex (2025) under the microscope: 829 hours of egocentric dexterous manipulation data, emphasizing hand tracking and on-device SLAM trajectories. This does not mean that TOBI owns or operates this public dataset; what this article discusses is how to translate specifications of this kind into purchasable, auditable data-capture hardware and delivery language.
EgoDex pushes dexterous manipulation hours to a new order of magnitude. Starting from task density, hand visibility, and hard synchronization, this article explains how the production E6 turns paper specifications into a purchasable capture order. Aimed at teams planning Ego datasets, VLA training, and robot transfer around 2026, it emphasizes auditable delivery, versioned calibration, and hard-sync quality checks, and warns against misreading public benchmarks as any single vendor's exclusive capability.
What the Paper Timeline Tells Us
Around 2025, EgoDex pushed community discussion toward a clear question: 829 hours of egocentric dexterous manipulation data, emphasizing hand tracking and on-device SLAM trajectories. The timeline tells us that the value of a public benchmark lies in defining "what counts as a qualified first-person/embodied sample," rather than implying that any hardware vendor automatically possesses data assets of equivalent scale. TOBI cites this paper solely for specification comparison and procurement language translation.
If EgoDex is included in the 2026-09-13 procurement review, three layers should be distinguished: the timing of the paper's release and open-source link, the timing of community reproduction and secondary annotation, and the timing when enterprise-built/purchased data actually enters the repository. Between these three layers, there are often method iterations from 2025 to 2026; what hardware teams should track is field/schema changes, not chasing paper titles.
For scene-type tasks (this article's slug: news-seo72-01-egodex-kitchen-dex), the paper timeline also indicates when "failure samples and long-tail scenarios" were incorporated into the benchmark protocol. Constraints that appear later often affect VLA training more than early-scale numbers; device selection should reserve the ability to retain time windows before and after contact.
Dataset Boundary Statement
EgoDex and its link https://arxiv.org/abs/2505.11709 in this article are within a public research context; TOBI does not claim ownership, hosting, or exclusive distribution of this dataset.
Acceptable requirements for capture hardware
To translate EgoDex's one-line claim into procurement language, the first step is to define "acceptable fields," rather than repeating "829 hours of egocentric dexterous manipulation data, emphasizing hand tracking and on-device SLAM trajectories." Hardware acceptance should be independently reproducible by third parties: given fixed firmware, a fixed calibration package, and a fixed recording script, anyone should be able to export the same timeline semantics.
- Hard synchronization: whether each camera/IMU/gesture stream shares an acceptable clock domain (target jitter and measured distribution are recorded in the data card).
- Calibration: intrinsic and extrinsic parameters, along with model versions such as Kannala-Brandt, are frozen with the firmware; changing the camera, ring, or wrist unit requires regression testing.
- Container: frame timestamp units and dropped-frame markers in dual-stream HEVC/fMP4 or MCAP and similar formats must not be lost during transcoding.
- Sharding: shard duration for long-horizon dex/collaborative tasks, ~5 GB upload limits, and DatasetServer health checks.
- Failure samples: whether contact-invisible, occluded, and desynced segments are retained and labeled rather than silently deleted.
- Compliance: operator authorization, site permissions, and de-identification policies are included as delivery attachments; unrelated to the licensing of publicly released academic datasets.
The following order is suitable for scientist teams to write into an SOP (2026-09-13 version), and is bound to the E6 evaluation prototype:
- Freeze the E6 firmware and SDK versions; reproduce the minimal script set for the EgoDex comparison experiment.
- Bench sync testing: measure cross-path offset using LED / mechanical triggers to produce a baseline report.
- Worn-state spot check: Sample 50 segments of contact frames for multi-view consistency across scenarios tagged with E6,EgoDex,dexterous manipulation,scenario.
- Ingestion QC: outputs sync_health, drop_frame, and calib_version fields.
- Training feedback: compare contact success rates using the hard-sync subset versus the soft-alignment subset, and record the results in the procurement review.
Mapping to TOBI E6 Product Capabilities
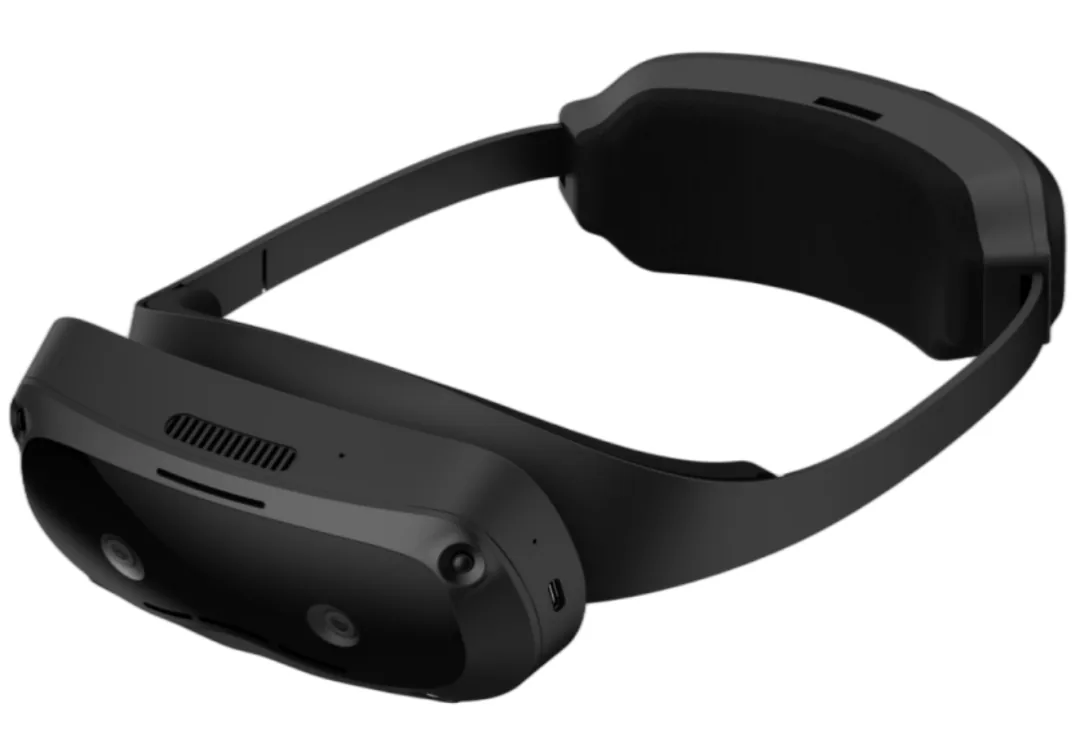
TOBI E6 is a six-channel camera production-grade capture platform with on-board SLAM and OpenXR gesture pipeline integration. Host-side CDC-ACM time synchronization, DatasetServer sharding, and health monitoring form a standard delivery loop; suitable for dexterity, collaborative Ego, and multimodal long-horizon tasks.
Compared with EgoDex: 829 hours of egocentric dexterous manipulation data, emphasizing hand tracking and on-device SLAM trajectories. On the device side, this should be translated into clickable product fields—for example frame rate/exposure/IMU frequency, whether on-device SLAM serves as a trajectory prior, and whether gestures/ring/wrist share the same time domain. Readers should go to /product-e6.html and /docs.html#device-sdk to verify the README and delivery package, rather than assuming the paper configuration equals the factory default.
When pillar=scene and the primary recommendation is E6, it is recommended to split "paper metrics" into Must (no purchase without them) and Stretch (R&D co-creation). Must typically covers hard synchronization, calibration version, and recording container time semantics; Stretch may cover motion capture bridging, ten-channel expansion, or cross-laboratory matrix networking.
- E2 positioning: binocular global shutter, offline-reconstruction-friendly, lightweight human-demonstration front-end (can still serve as a secondary network node when this article primarily recommends E6).
- E6 specification: six channels + on-board SLAM + gesture recognition; host time-stamping and sharded upload are the primary solutions for dex/collaborative Ego.
- E8 specification: ten-channel sensor density + TOF + motion capture (R&D-phase target, subject to written confirmation). An R&D target suitable for high-density sensing and VIO comparison experiments; commercial confirmation of mass-production boundaries is required.
- Wrist: PPS + UART, in the same domain as the head-mounted unit, serving contact blind spots for ActiveUMI-type use cases.
- Light ring / finger ring: supplementary tool-side geometry for HaMeR / MANO-friendly annotation.
Engineering deep dive: turning paper metrics into gates by scenario
(Deep dive · 01-1) For EgoDex and E6: laboratory matrix acquisition must define three-level primary keys operator_id, session_id, shard_id to avoid filename collisions. Under the scene pillar, this directly relates to the delivery risk of "EgoDex kitchen dexterous scenario: E6 six-camera like…".
(Deep dive · 01-2) Regarding EgoDex and E6: When comparing against public benchmarks, only borrow task definitions and metrics, not data licensing boundaries. Under the scene pillar, this directly relates to the delivery risk of "EgoDex kitchen dexterous scenarios: E6 six-camera like…".
(Deep dive · 01-3) Regarding EgoDex and E6: Ego-to-robot transfer should have a separate coordinate system appendix: the transformation chain of head, wrist, world, and robot_base. Under the scene pillar, this is directly related to the delivery risk of "EgoDex kitchen dexterous scenarios: E6 six-camera…".
(Deep dive · 01-4) Regarding EgoDex and E6: if HEVC transcoding re-stamps timestamps, the original_pts field must be preserved in metadata. Under the scene pillar, this directly relates to the delivery risk of "EgoDex kitchen dexterous scenarios: E6 six-camera...".
(Deep Dive · 01-5) Regarding EgoDex and E6: ring-based point supplementation is suitable for sparse geometric constraints and should not replace high-resolution hand pixel supervision. Under the scene pillar, this directly relates to the delivery risk of "EgoDex kitchen dexterous scenario: E6 six-camera like...".
(Deep Dive · 01-6) Regarding EgoDex and E6: Onboard SLAM trajectories can serve as priors, but the training side should be able to disable them to prevent SLAM failures from contaminating labels. Under the scene pillar, this directly relates to the delivery risk of "EgoDex kitchen dexterous scenes: E6 six-camera like …".
(Deep Dive · 01-7) For EgoDex and E6: collaborative ego-centric scenarios must declare the speech/instruction synchronization strategy to avoid causal misalignment between audio and visual streams. Under the scene pillar, this directly relates to the delivery risk of "EgoDex kitchen dexterity scenario: E6 six-lens ...".
(Deep Dive · 01-8) Regarding EgoDex and E6: QA spot checks should re-run the same script on a Linux host to ensure auditable delivery. Under the scene pillar, this directly relates to the delivery risk of "EgoDex kitchen dexterous scenario: E6 six-camera like...".
(Extension 01-B1) 2026-09-13 retrospective: There may be gaps between the E8 ten-channel and TOF channels in R&D integration and mass-production specifications; the contract should clearly state the delivery tier. If your team tags=E6,EgoDex,dexterous-manipulation,scenario, it is recommended to add this to the project risk register.
(Extension · 01-B2) 2026-09-13 retrospective: motion-capture bridging is a Stretch capability and requires a separate milestone and acceptance script. If your team's tags are E6, EgoDex, dexterous manipulation, scenes, this should be written into the project risk register.
(Extension · 01-B3) 2026-09-13 retrospective: Global shutter reduces geometric distortion compared to rolling shutter in fast lateral motion scenarios, benefiting stereo matching. If your team tags=E6, EgoDex, dexterous manipulation, scene, it is recommended to record this in the project risk register.
(Extension 01-B4) 2026-09-13 retrospective: the choice of a 65mm-class baseline affects depth accuracy and wearing volume, and should be consistent across the product page and data card. If your team tags=E6, EgoDex, dexterous manipulation, scenario, it is recommended to record this in the project risk register.
(Extension · 01-B5) 2026-09-13 retrospective: fMP4 segments are convenient for browser preview, but the training side requires a raw or lossless backup strategy. If your team's tags = E6, EgoDex, dexterous manipulation, scenario, we recommend adding this to the project risk register.
Frequently Asked Questions (FAQ)
Q: Does TOBI provide the EgoDex dataset? Not provided. EgoDex is a public research/community resource; TOBI only discusses specification comparisons and capture hardware capabilities.
Q: Can E6 alone reproduce all the results in the paper? No, it cannot be automatically guaranteed. The papers also involve task design, annotation toolchains, and training code; the hardware is responsible for making the timeline and sensor fields verifiable and acceptable.
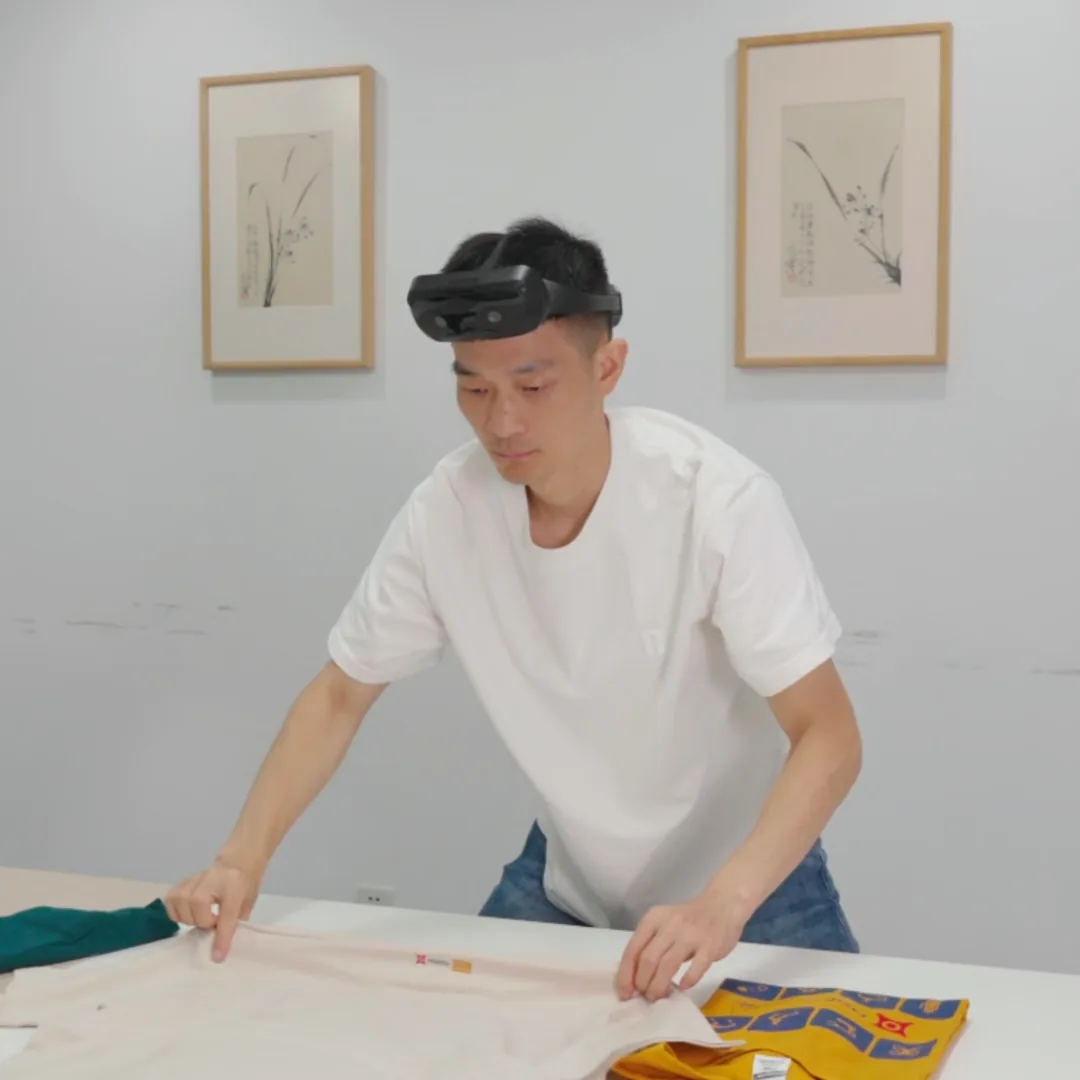
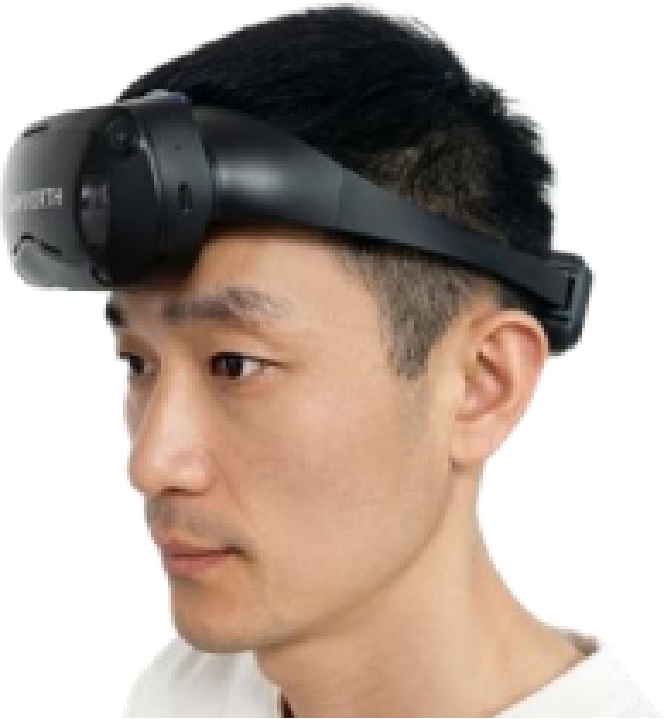
Q: What does the demo animation demo-e2.webp represent? Used to demonstrate E6 on-device recording and wear configuration; a TOBI on-device schematic animation, not official material from a public dataset.
Q: What attachments should I prepare when requesting a quote? It is recommended to attach https://arxiv.org/abs/2505.11709, a target hours/scenario table, a Must-field checklist, and whether wrist/ring/matrix networking is required.
Next step: specification comparison and evaluation prototype
If you are planning E6, EgoDex, dexterous manipulation, and scene scenarios against EgoDex, please contact TOBI with your Must-field checklist to request an E6 evaluation unit or a joint dataset delivery plan.
Read E6 Product Page, Developer Documentation · Device SDK, or Submit Quote Request and Technical Evaluation.
Compliance and Factual Boundaries
EgoDex and related public datasets are not TOBI assets; this article is used for research-frontier content marketing and hardware specification comparison. Product capabilities are subject to the official website and the version confirmed by business communication.
(Appendix · news-seo72-01-egodex-kitchen-dex · 1) If HEVC transcoding rewrites timestamps, the original_pts field must be preserved in the metadata. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 2) Ring-based point completion is suitable for sparse geometric constraints and should not replace high-resolution hand pixel supervision. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 3) On-board SLAM trajectories can serve as a prior, but the training side must be able to disable them to prevent SLAM failures from contaminating labels. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 4) Collaborative Ego scenarios must declare the speech/instruction synchronization strategy to avoid audio-visual causal misalignment. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 5) QA spot checks should re-run the same script on a Linux host to ensure the delivery is auditable. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 6) Illumination variation in kitchen and home long-tail scenarios requires exposure strategy to be written into the SOP: fixed, manual, and adaptive modes must be consistent. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 7) When 60fps stereo capture is combined with a 30fps auxiliary stream, clearly specify the downsampling and phase rules. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 8) When aligning 200Hz IMU with video frames, it must be declared whether interpolation or nearest-neighbor is used, along with boundary frame handling. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 9) ORB-SLAM3-class VIO baselines emphasize multi-sensor timestamps; Ego devices should align to equivalent semantics. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 10) Open X-Embodiment emphasizes cross-platform action distributions; the Ego field schema should reserve an embodiment_id field. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 11) DROID-class robot data lacks human priors; E2's lightweight Ego is suitable as a pre-stage for human demonstration. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 12) The HaMeR lineage is sensitive to occlusion; ring + multi-path redundancy reduces the proportion of invisible frames. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 13) ActiveUMI demonstrates active perception; dual-channel acceptance of wrist-mounted plus head-mounted streams is the procurement-grade answer. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 14) World model training relies more on long-duration consistent timelines; random cropping of short clips destroys state continuity. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 15) Diffusion policies are sensitive to contact phase; the data card should annotate the start and end frames of contact_phase. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 16) The Sim2Real pipeline should not use different timestamp units in sim and real. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 17) Enterprise content funnel: paper page → spec page → prototype → small-batch data → scaled procurement, with exit criteria at each step. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 18) This article focuses on engineering acceptance field descriptions, so that procurement and algorithm teams can copy them directly into RFQ attachments. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 19) When linking to SDK documentation, fix the anchor to #device-sdk to reduce reader disorientation. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 20) The video poster matches the hero image, reducing first-screen CLS and trust cost. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 21) The FAQ must reiterate dataset boundaries to prevent sales from over-promising. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 22) There may be a gap between the E8 ten-channel and TOF channels in R&D integration versus mass-production specifications; the contract should specify the delivery level clearly. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 23) Motion-capture bridging is a Stretch capability and requires a separate milestone and acceptance script. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 24) Global shutter reduces geometric distortion in fast lateral motion scenarios compared to rolling shutter, benefiting stereo matching. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 25) The choice of 65mm-level baseline affects depth accuracy and wearing volume, and should be consistent across the product page and data card. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 26) fMP4 segments facilitate browser preview, but the training side requires a raw or lossless backup strategy. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 27) MCAP is well-suited to the ROS2 ecosystem; field naming should follow the team's schema registry. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 28) Scripts like linux_run_time_sync.sh should be versioned and cross-referenced with the firmware README. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 29) The open-source e2-sdk/e6-sdk only helps you get started; mass-production procurement still follows the commercial delivery package. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 30) When multiple capture operators work in parallel, mixing NTP and hardware time sources will prevent shards from being merged; a unified time source must be used. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 31) Health monitoring should include camera dropout, IMU saturation, remaining storage, and thermal throttling. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 32) Privacy: faces, house numbers, and screens require a redaction pipeline, and redaction logs must be auditable. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 33) Version ledger: firmware, calibration, APP, host scripts, DatasetServer — five version number categories bound to the session. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 34) The annotation toolchain is decoupled from the hardware; but exports must reference calib_version and sync_report. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 35) A VLA recipe should declare the language instruction alignment method: manual trigger vs. ASR timestamps. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 36) Human-to-robot transfer requires declaring the action space: joint vs. end-effector vs. bimanual. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 37) It is recommended that procurement contract attachments include links to public papers for task reference only, without implying data transfer. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 38) The algorithm team should document the observation–action causal window in the data card, including whether frames from multiple streams are retained for 120ms before contact and 200ms after contact. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 39) During procurement review, require the supplier to provide P50/P95 curves of sync jitter, not single-point marketing figures. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 40) In long-duration dex capture, thermal drift and bandwidth contention amplify soft alignment errors; hardware triggering is superior to pure software timestamping. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 41) Failed samples must include a timeline health score; otherwise, VLA will treat interpolated frames after repair as real contact. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 42) Cross-day capture requires declaring the time source switching strategy: whether CDC-ACM, PPS, or GNSS are mixed. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 43) Inconsistent versions of the wrist-mounted and head-mounted extrinsic calibration cause a systematic shift in MANO supervision. Run regression tests when the wearer changes. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 44) Semantic gestures can serve as weak supervision, rather than independent labels, only when the OpenXR gesture stream and video frames share the same time base. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 45) DatasetServer shard limits and disk flush strategy affect whether the "last frame" is lost. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 46) Matrix-style data capture in the lab should define a three-level primary key of operator_id, session_id, and shard_id to avoid filename collisions. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 47) When comparing against public benchmarks, only borrow the task definitions and metrics, not the data licensing boundaries. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 48) Ego-to-robot transfer should include a separate coordinate frame attachment: the transformation chain for head, wrist, world, and robot_base. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 49) If HEVC transcoding rewrites timestamps, the original_pts field must be preserved in the metadata. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 50) Ring-based point completion is suitable for sparse geometric constraints and should not replace high-resolution hand pixel supervision. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 51) On-board SLAM trajectories can serve as a prior, but the training side must be able to disable them to prevent SLAM failures from contaminating labels. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 52) Collaborative Ego scenarios must declare the speech/instruction synchronization strategy to avoid audio-visual causal misalignment. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 53) QA spot checks should re-run the same script on a Linux host to ensure the delivery is auditable. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 54) Illumination variation in kitchen and home long-tail scenarios requires exposure strategy to be written into the SOP: fixed, manual, and adaptive modes must be consistent. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 55) When 60fps stereo capture is combined with a 30fps auxiliary stream, clearly specify the downsampling and phase rules. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 56) When aligning 200Hz IMU with video frames, it must be declared whether interpolation or nearest-neighbor is used, along with boundary frame handling. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 57) ORB-SLAM3-class VIO baselines emphasize multi-sensor timestamps; Ego devices should align to equivalent semantics. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 58) Open X-Embodiment emphasizes cross-platform action distributions; the Ego field schema should reserve an embodiment_id field. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.
(Appendix · news-seo72-01-egodex-kitchen-dex · 59) DROID-class robot data lacks human priors; E2's lightweight Ego is suitable as a pre-stage for human demonstration. When assessing E6 against EgoDex (2025), archive this together with the acceptance checklist dated 2026-09-13.