Lead-in | Product Content for Precise Customer Acquisition
From the intersection of top embodied-AI scientists and data experts, product-matrix selection is not just a model number in a catalog but a set of verifiable device requirements, hardware requirements, and output requirements. This article, combined with TOBI's current product matrix, explains product-matrix selection clearly and guides you to the corresponding product page and evaluation entry point—so that customers with real tasks can find us faster.
Industry insight: Why customers "search content, buy hardware, order data"
Embodied AI procurement in 2026 increasingly resembles industrial product decision-making: first use content to confirm the problem structure, then use specifications to confirm deliverability, and finally use evaluation to lock in the device and dataset combination. Long-form articles on product matrix selection that only discuss trends without model numbers cannot convert; those that only pile up parameters without discussing tasks cannot acquire customers. TOBI chooses to bind both: content answers "why it is needed," the product page answers "what we have," and consultation answers "how it is delivered."
On the search side, customers will use terms like "stereo Ego," "six-camera capture," "eight-camera motion capture," "global shutter head-mounted," and "on-device SLAM" to find suppliers. On the content side, these terms must be matched with real product capabilities, and the mass production / R&D boundary must be honestly labeled — trust is part of the conversion rate.
Scientist's Perspective: How Capture Problems Define Device and Hardware Requirements
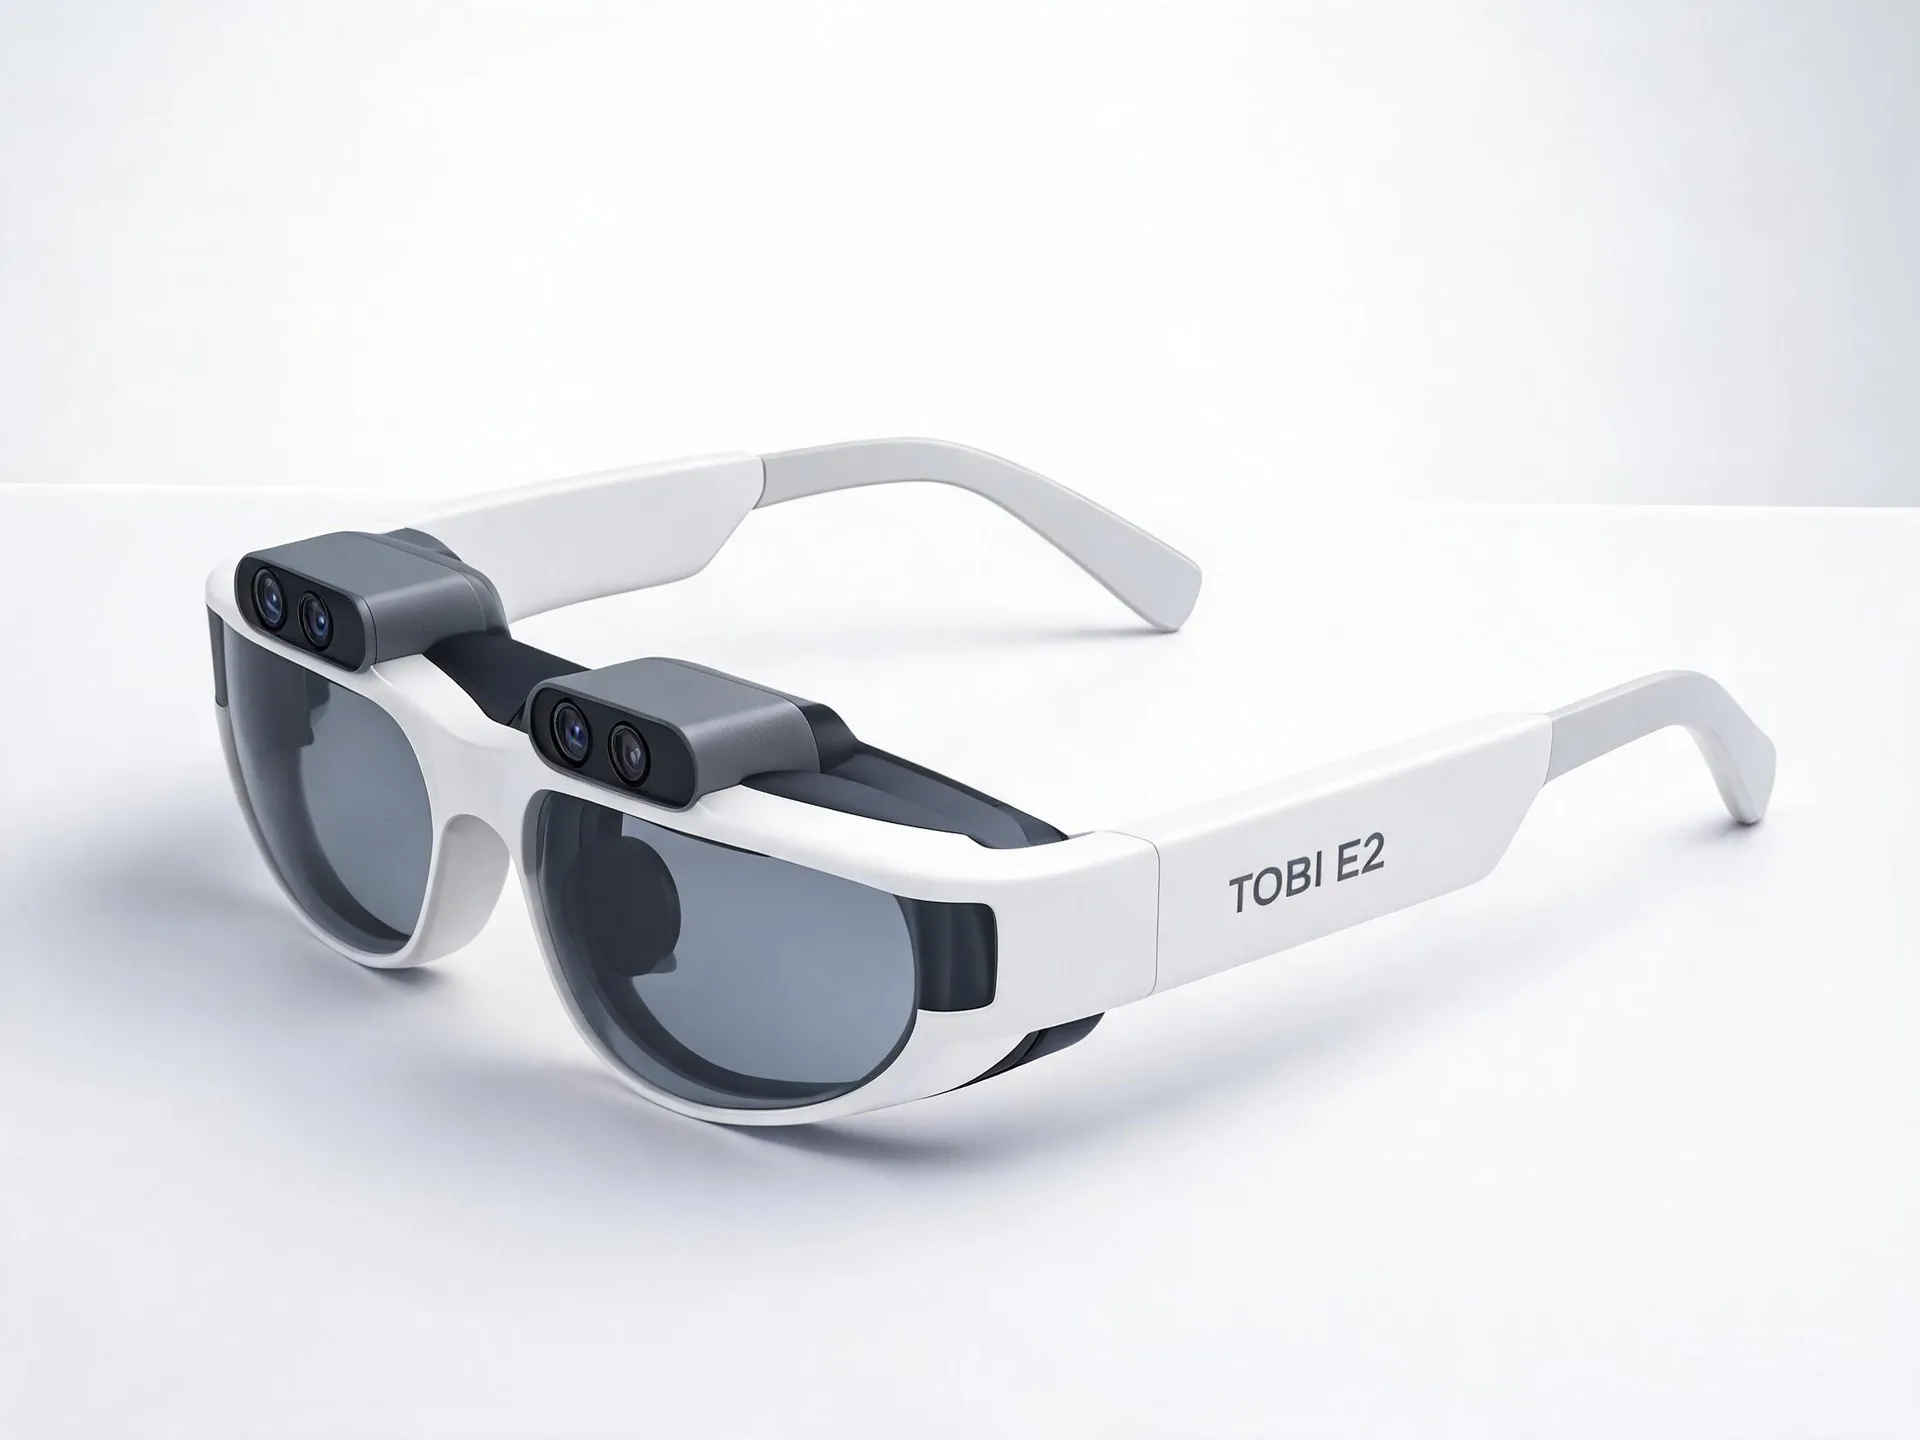
Embodied learning requires alignable observation–action distributions. For product-matrix selection, scientific questions come before procurement questions: Does the field of view cover the hands and tools? Does motion cause motion blur? Is timing co-registered? Are trajectories obtainable? Hardware is merely the engineering solution to these questions. E2 uses lightweight binocular global shutter to answer "wearable for long durations, clear capture, exportable data"; E6 uses six-channel synchronization plus on-device SLAM/gesture to answer "get a training package on site"; E8 uses eight-camera multimodal capture plus motion capture to answer "head-mounted plus full-body ground truth captured in one pass." Choose the wrong question, and you will choose the wrong hardware.
Output requirements are equally a scientific constraint: video without timestamps and intrinsic/extrinsic parameters is hard to use in serious training; without failure and near-failure samples, dexterous policies will be overly optimistic. TOBI therefore repeatedly emphasizes the "output checklist" in its content, so that customers can evaluate any vendor using the same language.
Data Expert's Perspective: How Hardware Output Becomes a Trainable, Purchasable Asset
When data experts evaluate a device, the essence is whether it can stably produce versionable data packages. Key fields typically include multi-channel timestamps, camera intrinsic and extrinsic parameters, video encoding, IMU, (optional) trajectory / gestures / motion capture, and scene and authorization metadata. E2 emphasizes open interfaces and post-processing freedom; E6 emphasizes on-device same-source preprocessing; E8 emphasizes multimodal structured export.
| Dimension | E2 Binocular | E6 Six-Camera | E8 Eight-Camera Multimodal |
|---|---|---|---|
| Core Hardware | 2× RGB global shutter, 65mm baseline | 4× grayscale GS + 2× RGB, microsecond-level synchronization | Head-mounted multi-camera vision + motion capture module |
| Weight / Battery Life | <150g, >5h | Approximately 370g, suitable for long shifts | Approximately 300–350g (including motion capture, subject to documentation) |
| Trajectory Path | No on-device SLAM; reconstruction on PC | On-device SLAM nominal 5mm | Motion capture provides full-body pose ground truth |
| Typical Output | H.265 video + IMU + intrinsic and extrinsic parameters | Video + SLAM + Gestures + IMU | Vision + IMU + Motion Capture Timeline |
| Status | In production | In production | R&D / planned mass production, metrics subject to project confirmation |
Deep Dive: Product Matrix Selection
Around the question of whether trajectory data is required, a top embodied-data expert will ask in parallel: Is it measurable? Can it be written into a purchase order? Can it be validated on samples from the target scenario? TOBI insists on mapping the need for trajectory data to the specifications and boundary descriptions on the product page, rather than marketing adjectives. For product matrix selection, this means that after reading this article, the customer should be able to identify: which device to choose, which output fields to examine, and what evaluation to schedule next.
Furthermore, whether trajectory requirements exist changes the division of labor across roles: the algorithm team is responsible for defining labels and evaluation, operations for effective hours and wearing load, and procurement for acceptance and after-sales. Neglecting any one role means that no matter how well the hardware is selected for the product matrix, it becomes an idle asset by the second week. Therefore, this article frames the presence or absence of trajectory requirements as a shared cross-role language, so that customers can align internally and then precisely find TOBI.
Around the question of batch production versus prototyping, a top embodied-data expert will ask in parallel: Is it measurable? Can it be written into a purchase order? Can it be validated on samples from the target scenario? TOBI insists on mapping batch production versus prototyping to the specifications and boundary descriptions on the product page, rather than marketing adjectives. For product matrix selection, this means that after reading this article, the customer should be able to identify: which device to choose, which output fields to examine, and what evaluation to schedule next.
Furthermore, batch production versus prototyping changes the division of responsibilities across the organization: the algorithm team defines labels and evaluation metrics, the operations team is responsible for effective capture hours and wearing burden, and the procurement team handles acceptance and after-sales service. Neglecting any one role, and even the best hardware selected through product matrix selection becomes an idle asset by the second week. This article therefore frames batch production versus prototyping as a shared language across roles, making it easier for the customer to align internally and find TOBI with precision.
Around the question of motion capture versus multimodal capture, a top embodied-data expert will ask in parallel: Is it measurable? Can it be written into a purchase order? Can it be validated on samples from the target scenario? TOBI insists on mapping motion capture versus multimodal capture to the specifications and boundary descriptions on the product page, rather than marketing adjectives. For product matrix selection, this means that after reading this article, the customer should be able to identify: which device to choose, which output fields to examine, and what evaluation to schedule next.
Furthermore, motion capture and multimodal data will change organizational division of labor: the algorithm team is responsible for defining labels and evaluation, operations for effective hours and wearing load, and procurement for acceptance and after-sales. Neglecting any one role, no matter how well the hardware is selected for the product matrix, will become an idle asset by the second week. Therefore, this article frames motion capture and multimodal data as a cross-role common language, making it easier for customers to align internally and then precisely find TOBI.
Around "budget and headcount," a top embodied data expert will simultaneously ask: Is it measurable? Can it be written into the order? Can it be validated on target-scenario samples? TOBI insists on mapping budget and headcount to the specifications and boundary notes on the product page, rather than marketing adjectives. For product matrix selection, this means that after reading this article, the customer should be able to identify: which device to choose, which output fields to examine, and what evaluation to schedule next.
Furthermore, budget and headcount change the division of responsibilities across the organization: the algorithm team defines labels and evaluation metrics, the operations team is responsible for effective capture hours and wearing burden, and the procurement team handles acceptance and after-sales service. Neglecting any one role, and even the best hardware selected through product matrix selection becomes an idle asset by the second week. This article therefore frames budget and headcount as a shared language across roles, making it easier for the customer to align internally and find TOBI with precision.
Regarding the "combined peripheral path", a top-tier embodied data expert will also ask: is it measurable? Can it be written into an order? Can it be validated on target-scenario samples? TOBI insists on mapping the combined peripheral path to the specifications and boundary descriptions on the product page, not to marketing adjectives. For product matrix selection, this means that after reading this article, the customer should be able to point out: which device to choose, which output fields to examine, and what evaluation to schedule next.
Furthermore, the combined-peripheral integration path changes the division of responsibilities across the organization: the algorithm team defines labels and evaluation metrics, the operations team is responsible for effective capture hours and wearing burden, and the procurement team handles acceptance and after-sales service. Neglecting any one role, and even the best hardware selected through product matrix selection becomes an idle asset by the second week. This article therefore frames the combined-peripheral integration path as a shared language across roles, making it easier for the customer to align internally and find TOBI with precision.
How to Find TOBI Precisely Using This Article
- •If your keywords are stereo / lightweight / batch → prioritize opening the E2 product page to verify output boundaries.
- •If you need on-site trajectory and gestures from the same source → prioritize opening E6, and confirm the RGB rolling shutter / global shutter version.
- •If you need full-body motion capture or multimodal prototyping → schedule an E8 evaluation and request the current written specifications.
- •If contact is not visible → add a wrist camera; if tool-end positioning is needed → evaluate the light ring module.
- •If you need in-stock / custom datasets at the same time → submit the task scenario and scale together in your inquiry.
Next Step: Turn Selection into a Quotable List
Writing devices, peripherals, and datasets into the same evaluation table shortens the decision cycle more than requesting quotes individually.
- •Open the corresponding product detail page, to verify specifications and boundary descriptions.
- •Back to Product Matrix Filter and compare E2 / E6 / E8 and peripherals by capability.
- •View Solutions, aligning scenarios and delivery boundaries.
- •Book a Technical Assessment / Request a Quote for Equipment and Datasets(Target: return the framework within ≤1 business day).
- •Read Developer Documentation, so that the algorithm team can first align on export and integration.
TOBI's Perspective
Top-tier embodied data experts don't buy "headsets that look flashy"; they buy acceptable capture protocols and trainable output packages. TOBI writes E2 / E6 / E8 as verifiable specifications and datasets as tradable SKUs, guiding customers from a piece of content to an evaluation.
Addendum: In real deliveries, the success of product matrix selection depends on sample validation — first capture a small batch in the target scenario, verify synchronization, wearability, storage, and training gains, then scale up the order. TOBI's evaluation process encourages this "small loop," reducing risk for both parties and helping content readers become qualified opportunities faster.
Specifications and Boundary Notes (subject to the official product page)
- •E2: 2-channel RGB global shutter 1600×1200@30fps, single-camera HFOV 139°, VFOV 111°, 65mm baseline, IMU 800Hz, no on-device SLAM.
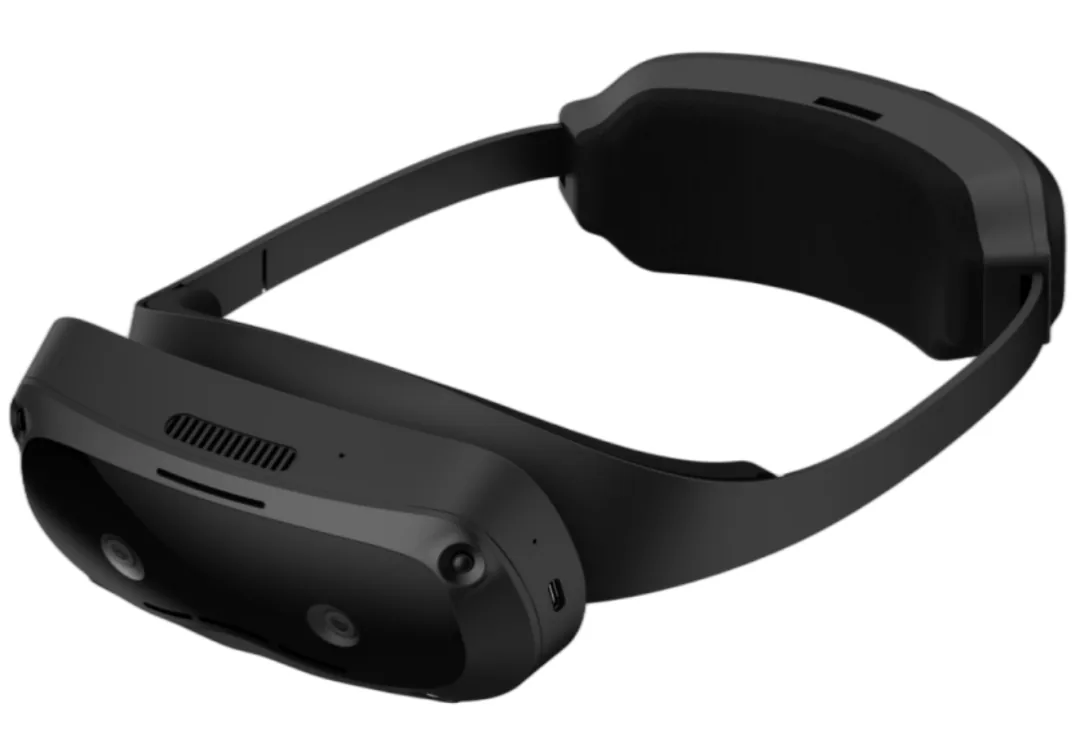
- •E6: 4-channel grayscale global shutter (including infrared recognition) + 2-channel RGB, microsecond-level synchronization, on-device SLAM / gestures, Qualcomm XR2 Gen1; RGB is available in rolling shutter / global shutter versions.
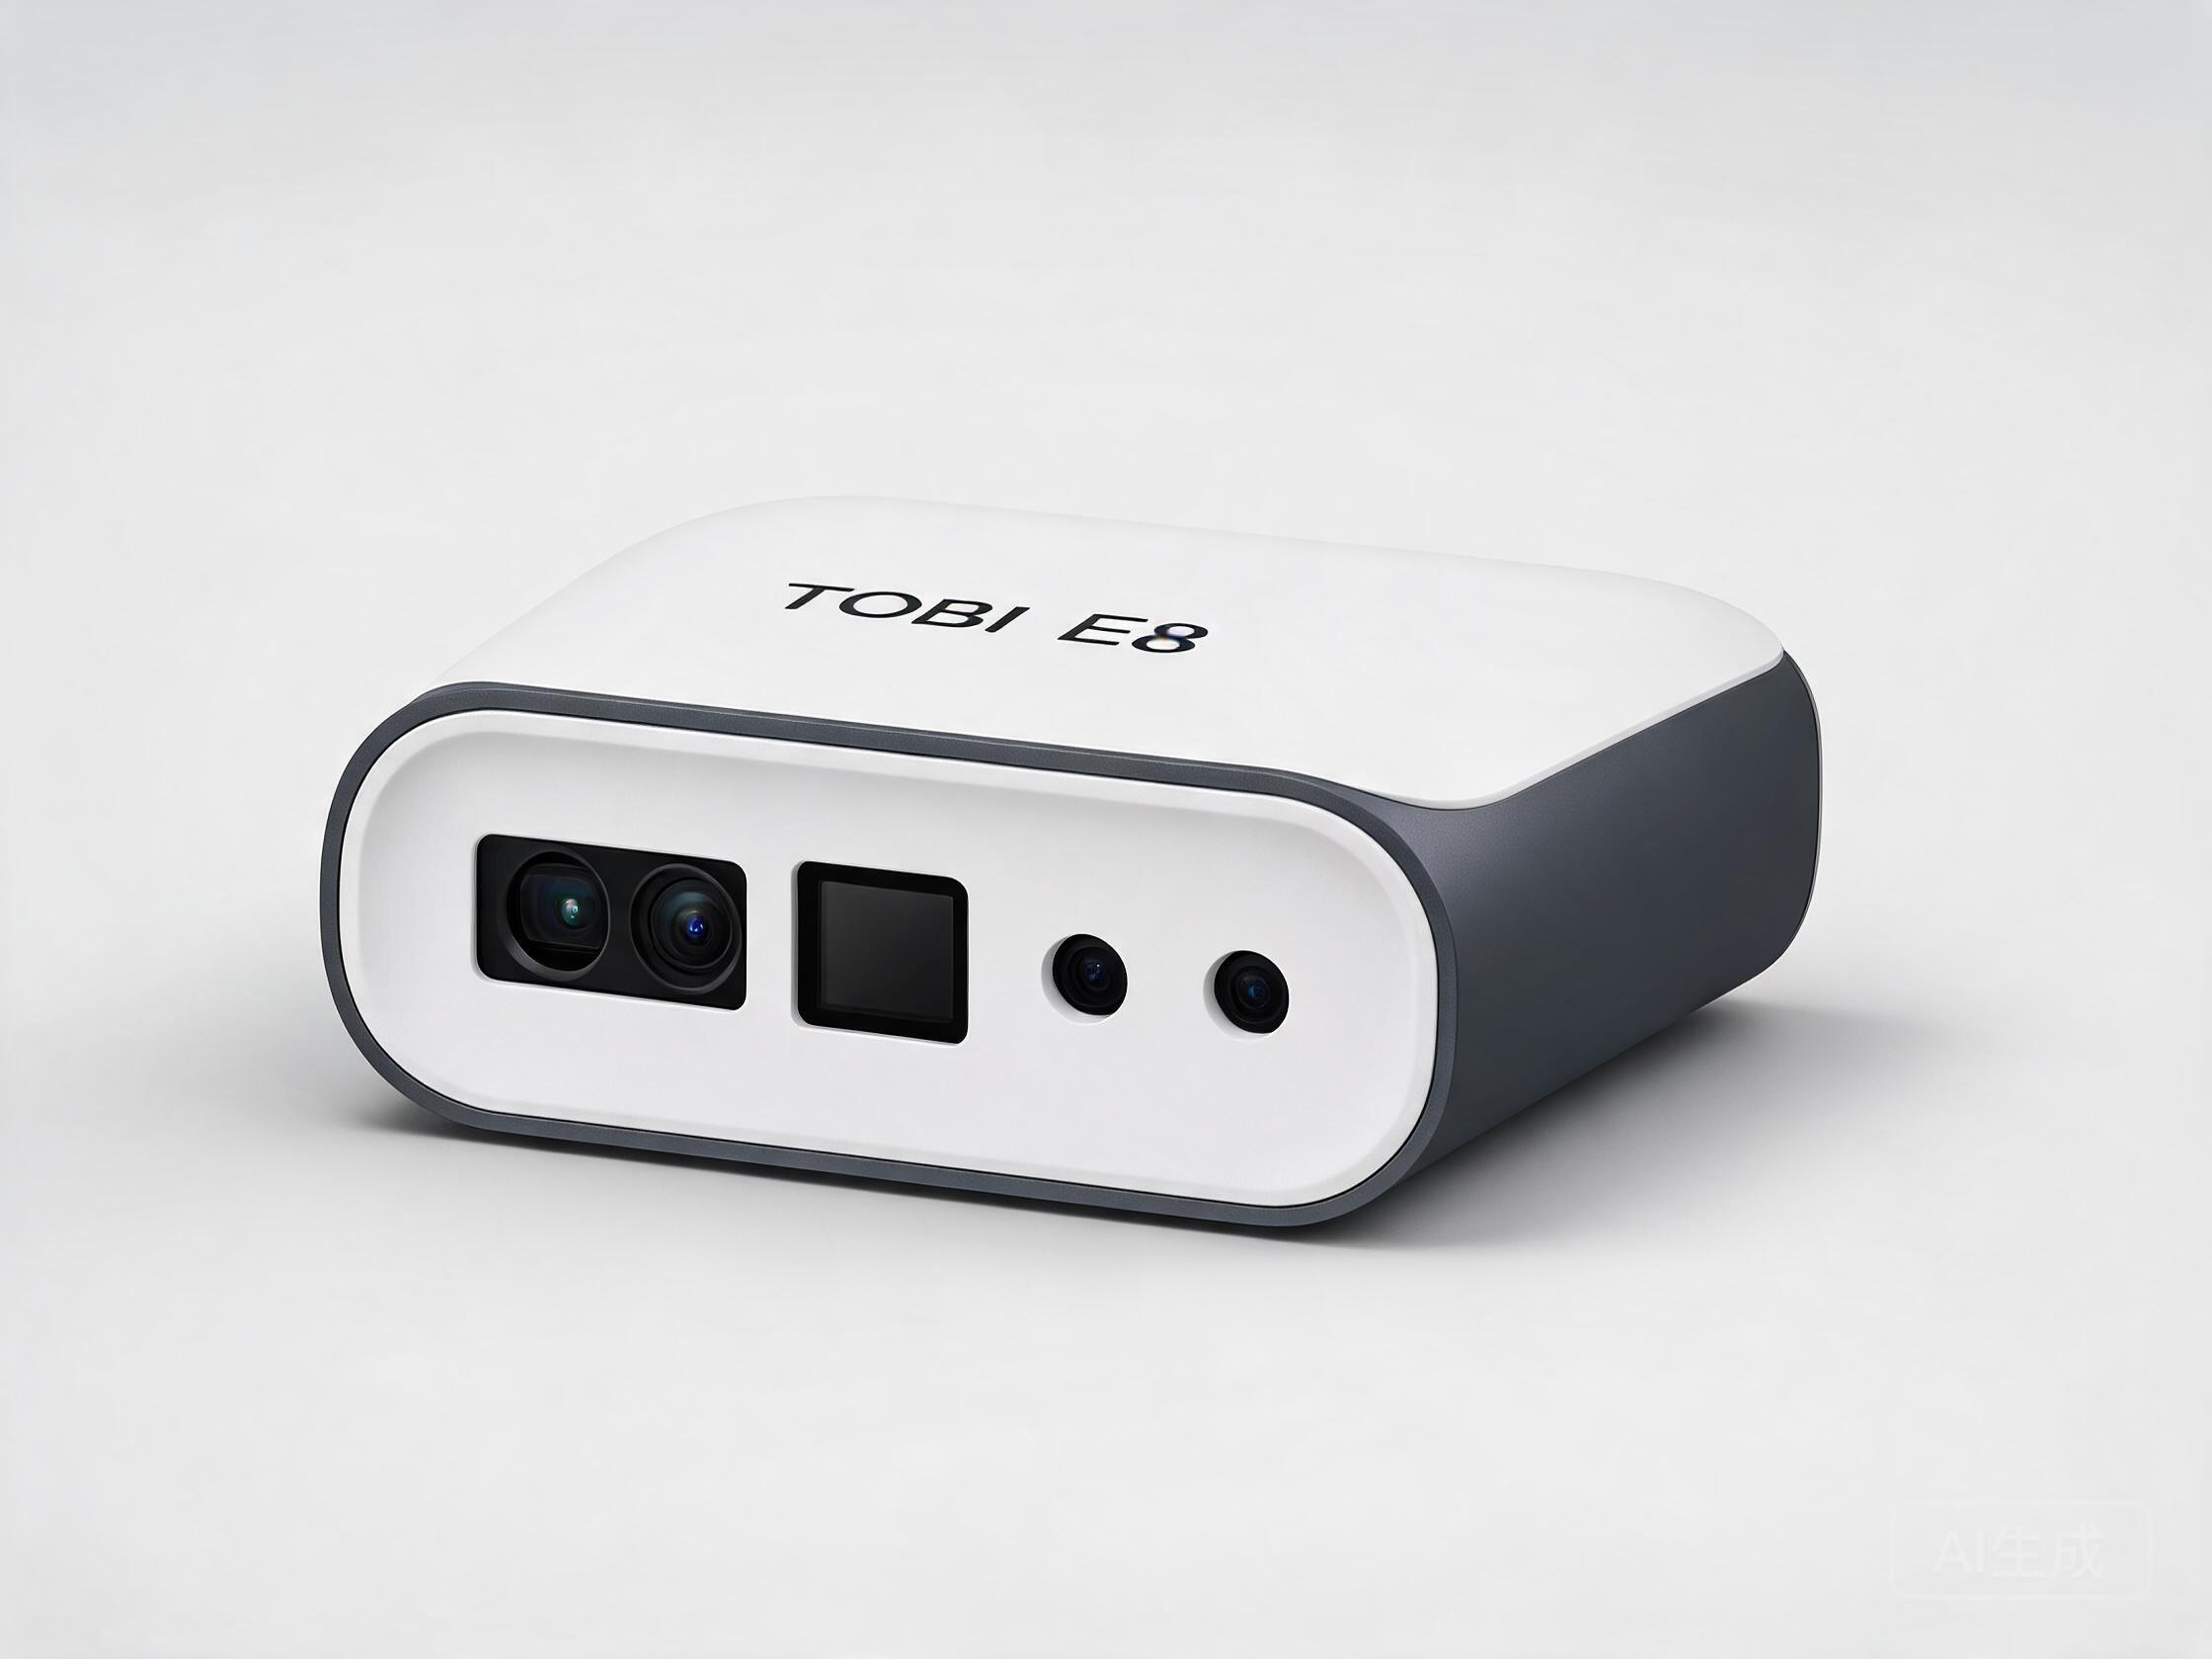
- •E8: positioned for eight-camera multi-modal capture, can be paired with full-body motion-capture modules; synchronization and positioning metrics are subject to written documentation and project confirmation, and information at the R&D stage does not constitute a supply commitment.
- •Wrist camera / light ring positioning: as a peripheral extension, the synchronization method with the host is confirmed per project.
- •Product configurations, test results, and delivery scope are subject to the current written specifications.