Marketing for multimodal embodied data easily becomes "full-chain coverage." The engineering reality is colder: the more channels there are, the faster the complexity of temporal misalignment, calibration drift, and fault isolation rises. TOBI emphasizes: multimodal synchronization is not a feature toggle, but a through-line engineering discipline spanning device selection, capture protocols, QC, and dataset transactions. Marketing must translate "full modality" into verifiable synchronization claims; science must treat synchronization error as a source of bias; engineering must write clock domains into reproducible experiments.
Visual anchors, wrist, inertial measurement, and motion capture
The Ego camera is often chosen as the temporal anchor, so anchor stability determines global consistency. The wrist is closer to contact events and is better suited as a high-precision event channel rather than the sole anchor. Inertial measurement and motion capture provide high-frequency kinematics, but raw and filtered streams must both be retained; packet-loss intervals must be explicitly marked invalid, and silent interpolation must never be passed off as observation. E8 targets higher-integration wearables; E2 and E6 make the anchor strategy reproducible across multiple sites.
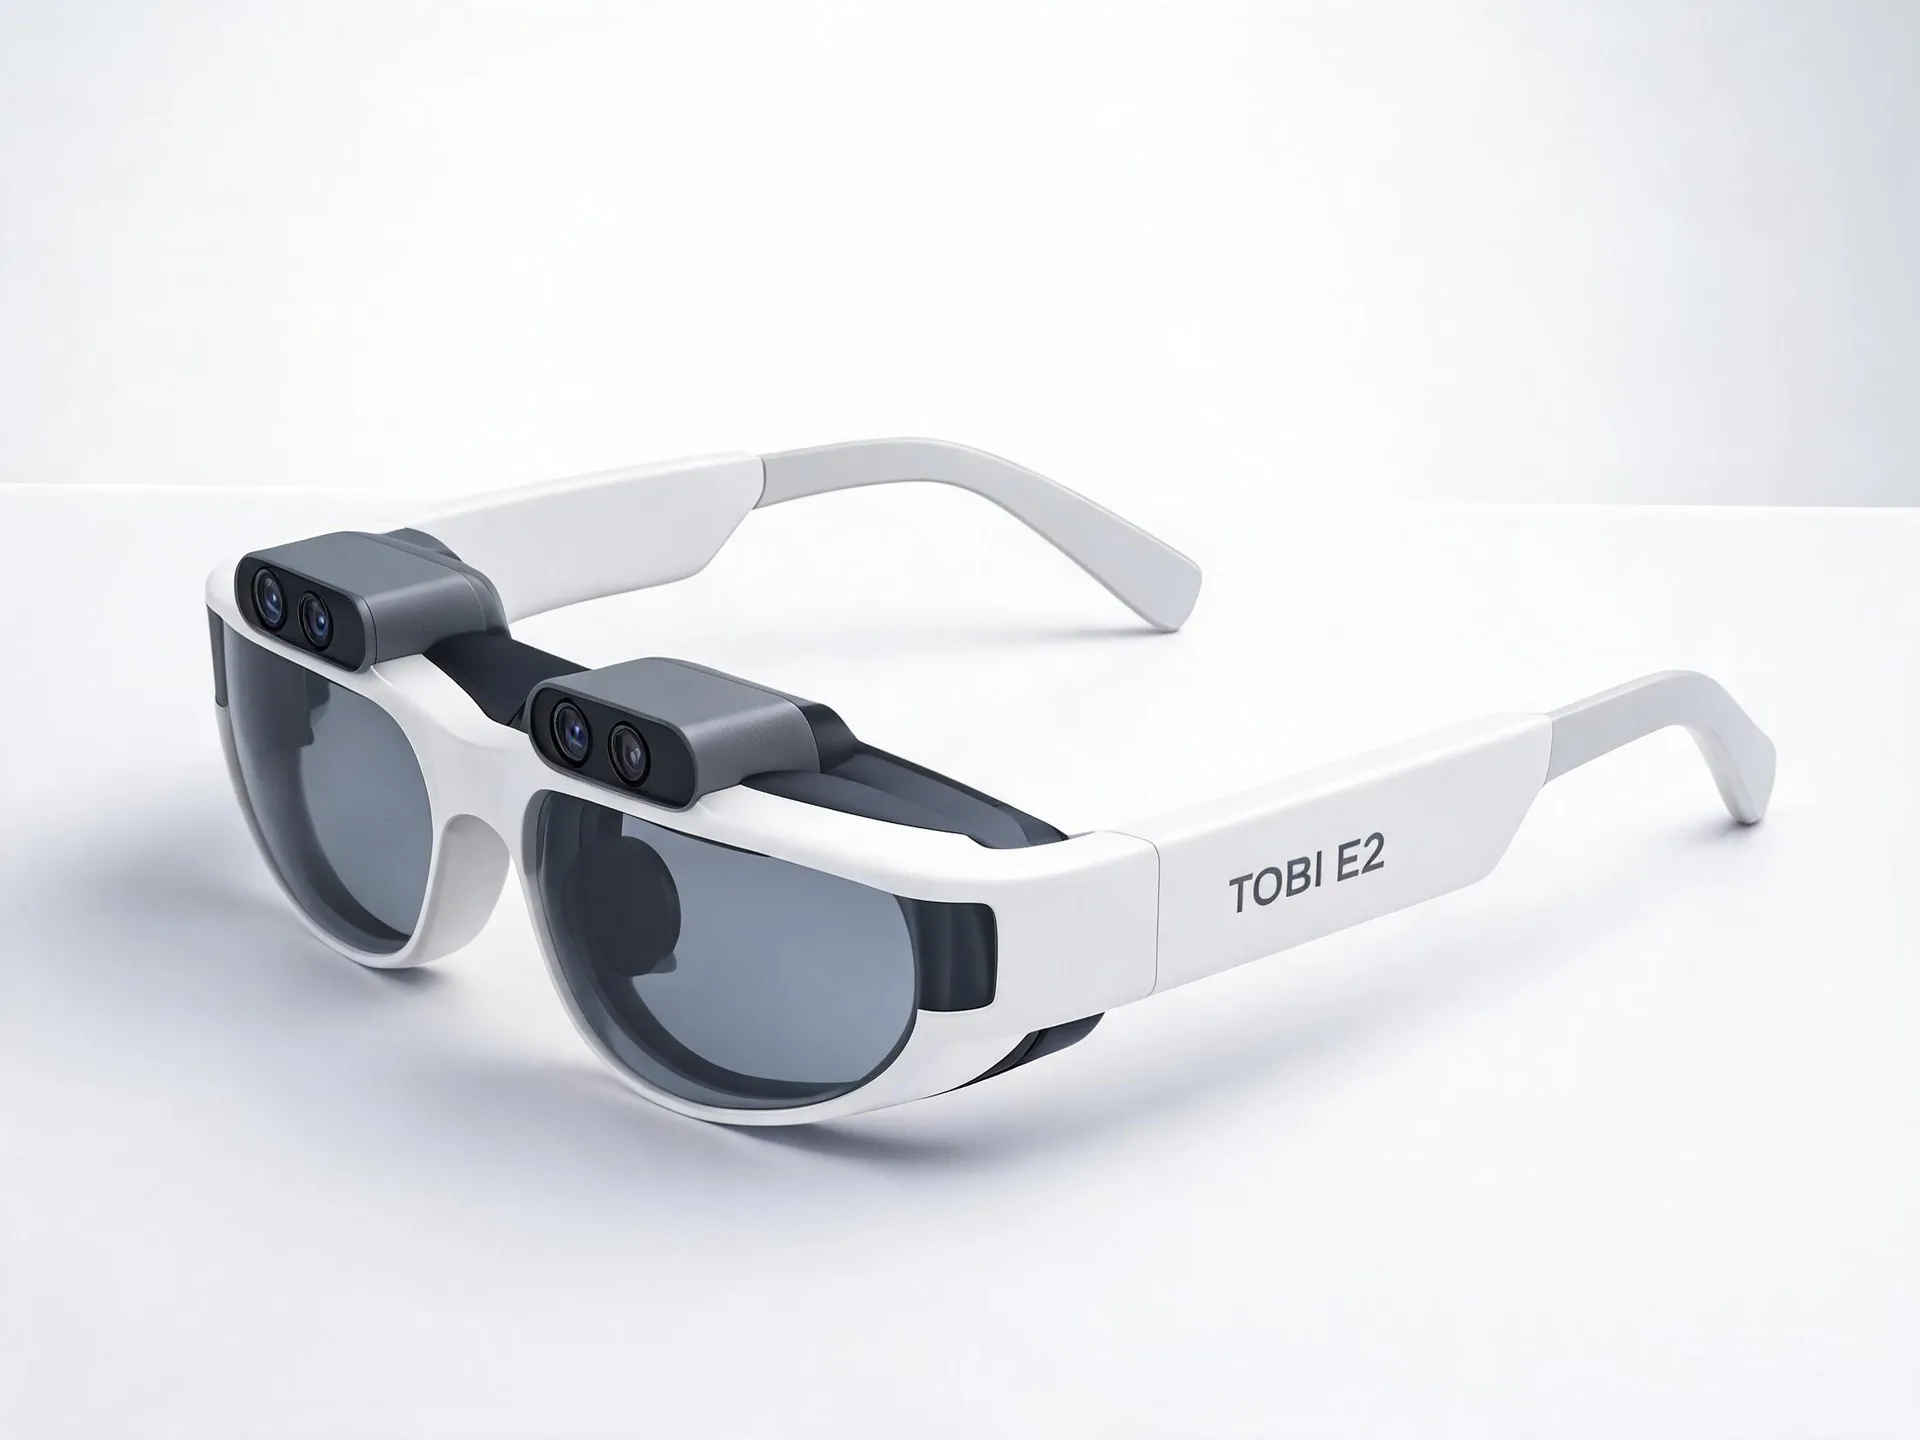
The goal of synchronization is not to make curves look good, but to make errors visible. Invisible interpolation is the most expensive hidden debt in a multimodal dataset. — Notes from an algorithm engineer
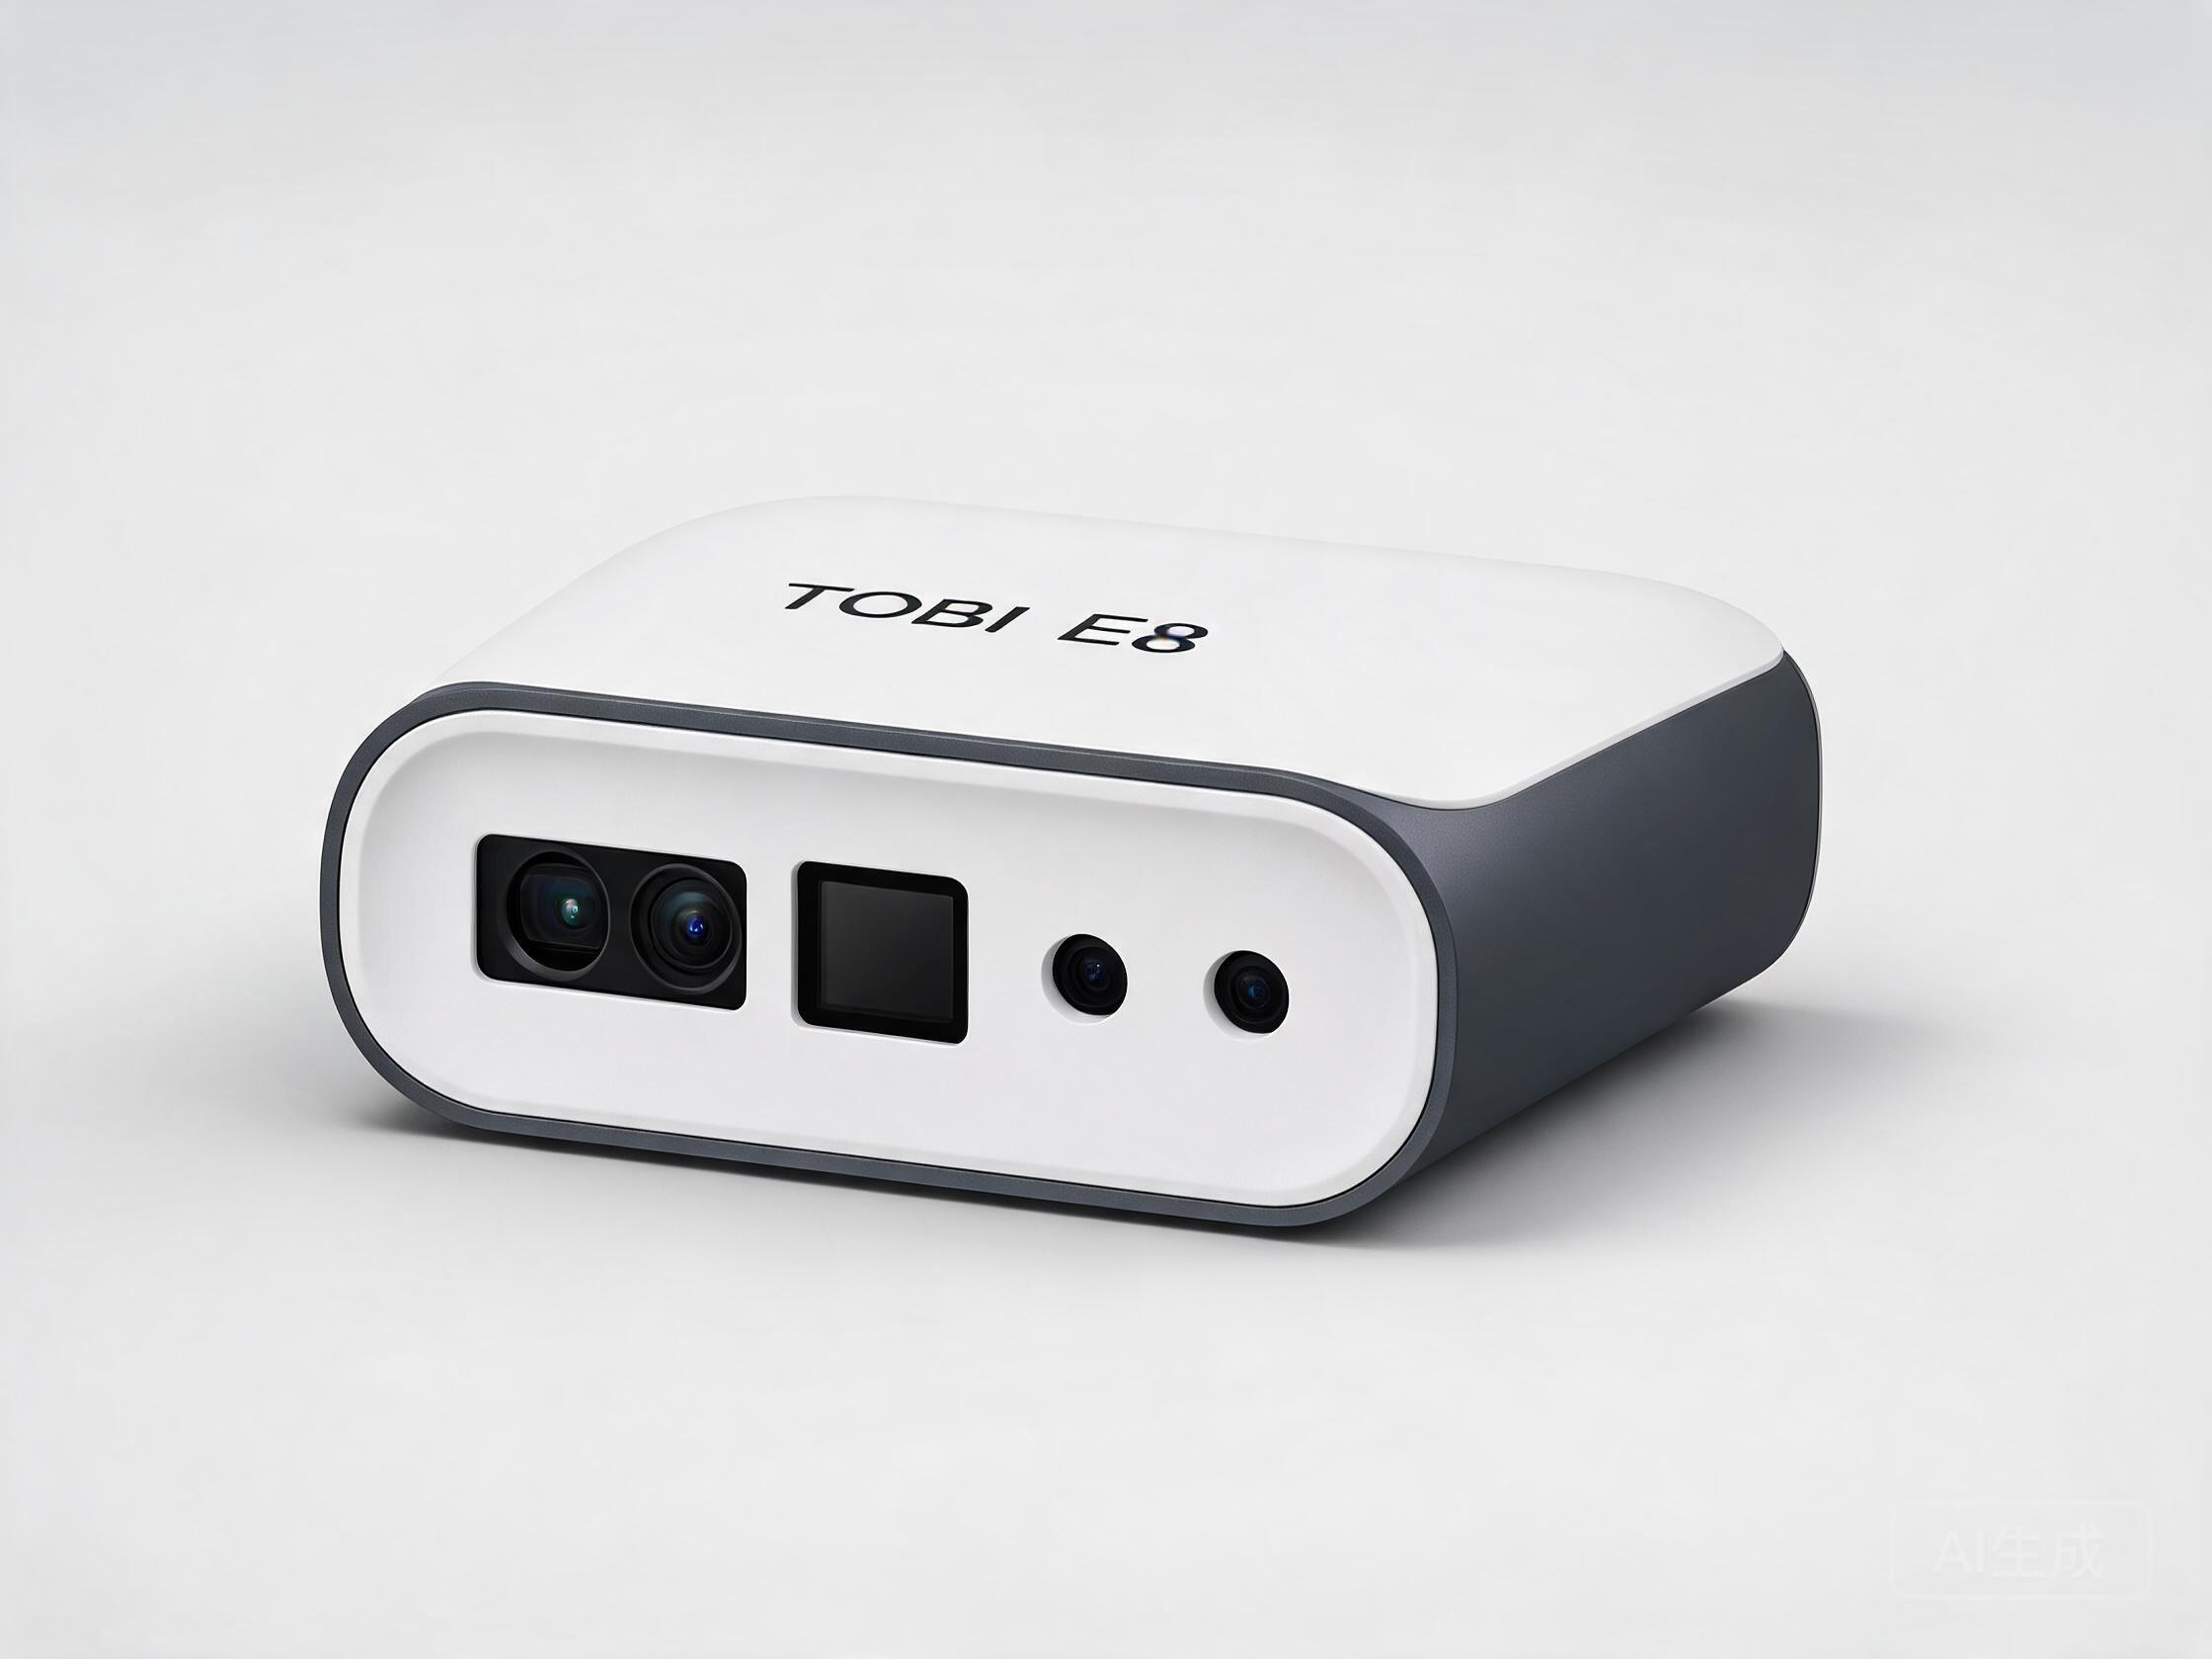
Fault tree, calibration drift, time model and delivery
On-site fault trees should be investigated layer by layer: anchor frame drops, wrist black frames, inertial saturation, motion-capture rigid-body loss, and disk-write blocking, while allowing degraded samples with invalid flags to enter the database. Spatial calibration drift and temporal misalignment are equally fatal; extrinsic verification should be performed before and after critical tasks. The time model—whether resampled, aligned at native frequency, or event-aligned—must declare whether interpolation is treated as an observation. The delivery checklist must include clock domains, synchronization methods, error reports, calibration versions, and fault intervals. TOBI productizes synchronization engineering into something that can be captured, quantified, replayed, and traded.
In 2026 project governance, data owners need to manage capture protocol versions the same way software versions are managed. Protocol changes must record the reason, affected channels, whether comparability with historical batches is broken, and whether the golden set needs to be re-captured. If the algorithm side detects a metric jump, it should first check the protocol version before suspecting the model architecture. TOBI Technology recommends writing the protocol version into the metadata of every sample, so that purchased packages and self-captured packages can coexist under the same governance framework. On the procurement side, the protocol version can be used as an acceptance field, rejecting deliveries with missing or conflicting versions. Device firmware and wrist-module firmware should also be included in the same version view to avoid implicit incompatibility.
Operator training is an often-underestimated quality lever. The same set of E2 or E6 devices, after standardized donning, task-card reading, failure retention, and post-shift spot-check training, often achieves a significantly higher usable-hour rate than untrained teams. Training content should include: how to identify wrist focus loss, how to handle segment marking after an emergency stop, and when to abort rather than force through. In customer on-site support, TOBI tends to deliver the training checklist first and pursue scale afterward, because scale amplifies habits, whether good or bad. For the E8's complex donning, cable management and inspection actions must be drilled to muscle memory, otherwise no amount of beautiful synchronization claims will hold up against production-line takt time.
For vision-language-action models, the alignment quality between the language channel and the action channel determines whether instruction following is transferable. During capture, it should be specified whether language is pre-scripted, real-time spoken commands, or post-hoc annotation — the three make different assumptions about noise and latency. Post-hoc annotation must not be passed off as synchronized commands. Purchasable datasets must disclose the language source. The chief scientist should use ablation studies to verify the true contribution of language supervision, avoiding mistaking visual shortcuts for language understanding. If marketing materials emphasize multimodality, they should also present the quality-control methods for language alignment, otherwise it is merely stacking adjectives.
Lighting management in factories and laboratories should be part of the recipe. Auto-exposure can produce unpredictable brightness jumps when moving quickly in and out of shadowed areas; fixed exposure may fail under extreme reflections. A practical approach is to lock the exposure curve per task segment and record it in the metadata. Wrist close-ups are more sensitive to local highlights, so quality inspection thresholds should be set separately. TOBI does not promote any single exposure strategy as a universal solution, but emphasizes that strategies must be bound to tasks, reproducible, and auditable. Both predictable video and motion priors benefit from this honest optical management.
Data security is not an appendix but part of the capture architecture. Local cache encryption, transmission permissions, de-identification workflows, and retention periods should all be determined at project kickoff. Ego footage may naturally capture employee badges and visitor faces, which must be handled per agreement. TOBI provides processing instruction templates in the trade appendix, but this does not replace the customer's compliance assessment, nor does TOBI fabricate external certifications. Honest disclosure of residual risk better meets 2026 buyer expectations than verbal guarantees of absolute security. Procurement legal and algorithm teams should jointly review the security appendix at the sample package stage.
For cross-team collaboration, we recommend establishing a weekly data meeting that reviews only three tables: available hours, failure type distribution, and synchronization and bad-clip trends. The meeting does not discuss model architecture unless the data tables show anomalies. This cadence prevents algorithm meetings from overtaking data governance. Complex wearable projects such as E8 especially need this, because there are more failure modes. Scalable procurement decisions should also be made at this meeting using the same tables, rather than through private orders that cause lineage confusion. The TOBI customer success path encourages archiving meeting minutes alongside data versions.
When a model fails on real hardware, the standard procedure is to replay and diagnose, not to immediately add data. Replay diagnosis can distinguish: unseen layouts, synchronization errors, labeling errors, insufficient motion priors, or control-layer issues. Only the first two and the fourth should trigger new capture or external purchase orders. TOBI views replay capability as a tool to reduce ineffective procurement, which does not conflict with lead conversion—effective orders are more sustainable than blind orders. Algorithm engineers should document replay conclusions as searchable work orders that procurement and capture scheduling can consume directly.
For multi-site deployment, calibration stations, charging and storage, and spare-unit rotation should be planned like production-line consumables. Device idling and ad-hoc borrowing cause firmware and calibration inconsistencies. At E2 scale, the asset management system should record each device's most recent calibration and QC status. Data packages should reject critical-task samples from devices with expired calibration, or down-weight them. These details determine whether Ego data can support world-model-level training, and whether auditable acceptance can be replicated across multiple factories.
Version management of annotation guidelines is as important as the capture protocol. After a guideline upgrade, whether historical labels need re-annotation and how compatibility is maintained must be clearly specified. A rising disagreement rate is often a signal of guideline ambiguity. Platform-based annotation can accumulate examples and arbitration records, making guideline iteration auditable. TOBI believes annotation is not a cheap downstream process but a key manufacturing step that turns raw capture into trainable supervision, and its budget should be visible separately. Purchasable data packages should include a guideline summary and disagreement rate so buyers can judge whether the annotation depth matches their model stage.
Teams should adopt written stop conditions: which evaluation thresholds allow pausing expanded capture, and which risks require halting capture for remediation. Capture without stop conditions becomes an infinite budget sink. Procurement contracts can also include phased stop and restart clauses. This makes TOBI's collaboration with clients more like jointly operating a supply system rather than a one-time material purchase. Thought leadership must ultimately land in these executable governance actions, and lead conversion is cleaner as a result—what is discussed is the system, not anxiety.
If your team is advancing multimodal synchronized capture of vision, inertial measurement, motion capture, and wrist channels, or related dataset procurement, or if you wish to integrate egocentric capture, wrist cameras, and purchasable datasets into a single delivery loop, you are welcome to visit Products Learn about E2, E6, E8 capture devices and wrist camera configurations — see Solutions data acquisition, quality control, and delivery paths, or go directly to Inquire about robot dataset transactions, to discuss sample packs, licensing terms, acceptance metrics, and delivery service levels with TOBI.